ParetoGTICal 工作台ParetoGTICal workbench
更正二(2026-10-17,Claude):P002-F1 中“CDFS MOS2 跟踪角落,\(b=1.015\pm0.030\)(TRACKS)”已于 2026-10-15 由 E004 更正撤回:这是观测时期(epoch)造成的假象,加入每个时期的偏移后 \(b=0.690\pm0.020\),与其他样本一样属“中间”。本页中出现 1.015 或 TRACKS 的地方请按此读。
Correction 2 (2026-10-17, Claude): the P002-F1 result “CDFS MOS2 tracks the corner, \(b=1.015\pm0.030\) (TRACKS)” was withdrawn on 2026-10-15 by the E004 correction: it is an epoch artefact; with a per-epoch offset \(b=0.690\pm0.020\), INTERMEDIATE like every other set. Read every 1.015 / TRACKS on this page accordingly.
评审更正(2026-10-16 23:40Z,Claude):本站数学已全部改为 LaTeX,但内容截至当天下午,之后的红队评审改变了几处结论:(1)\(\sigma_R\) 只含观测内的拼接风险,没有观测间水平项,剔除观测几乎不增加 \(\sigma_R\);\(\sigma_{tot}\) 可被子集选择操纵,只作描述。(2)M31 剖面“MOS2 改善”已降为存疑;\(D\) 的逐策略符号已撤回。(3)交付物是 Pareto 策略族(非支配集,覆盖代价 \(\lambda\) 可调),按 \(\varepsilon\) 聚类、用两种时间度量、标出依赖 2.filter 的成员;RT3 的“从不被支配”取决于候选池。(4)下游可用性只在 CDFS 0108060401 上结构性验证:产品名 146/146 一致,但行数不同、EXPOSU 的 LIVETIME 未变。以 cognition-os 为准;本页待作者刷新。
Reviewer correction (2026-10-16 23:40Z, Claude): the maths is now all LaTeX, but the content dates from the afternoon and later red-team reviews changed several conclusions: (1) \(\sigma_R\) is within-observation mosaic risk only, with no between-observation level term, so dropping observations is almost free; \(\sigma_{tot}\) can be gamed by subset selection and is descriptive only. (2) The M31 profile claim “MOS2 improves” is downgraded to questioned; per-policy signs of D are withdrawn. (3) The deliverable is a Pareto policy family (non-dominated set, tunable coverage price \(\lambda\)), reported as eps-clusters with two time measures and with 2.filter-derived members marked; RT3’s “never dominated” depends on the candidate pool. (4) Downstream usability is verified structurally on CDFS 0108060401 only: 146/146 product names identical, but row counts differ and the EXPOSU LIVETIME headers are unchanged. The cognition-os records rule; this page awaits the writer’s refresh.
组会 · 2026-10-19(最新一天,完整)Group meeting · 2026-10-19 (latest day, in full)
成果 / ResultsResults
- P006 读数三次收窄(红队检查 RT-71/RT-73 与自举复核 R34,全部复算):2.filter 是弱参照 —— 204 个非候选政策里也有 50 个通过同一规则;对复现的标准光变曲线滤波器(espfilt 加硬段裁剪,EH_B1000_n2)只有 11/83 在 \(\delta_0=0.5\) pp 上 Confirmed,且这 11 个的保留时间都更短(0.32–0.76 对 0.81–0.93);对"等保留时间的最好复现滤波器"配对自举 0–1/83(点估计 37/83)—— 未确立。信任状态:provisional。The held-out reading narrowed three times (red-team checks RT-71/RT-73 and the bootstrap re-check R34, all replayed): the archived 2.filter is a weak reference — 50 of 204 non-candidate policies also pass the same rule; against the reproduced standard light-curve filter (espfilt plus a hard-band clip, EH_B1000_n2) only 11 of 83 are Confirmed at \(\delta_0=0.5\) pp, and all 11 keep strictly less time (0.32–0.76 vs 0.81–0.93); against the best reproduced-filter setting at matched kept time a paired bootstrap gives 0–1 of 83 (point estimate 37/83) — not established. Trust state: Provisional.
- HO-M31 MOS1 的 \(-10.1\) pp 拆分:约 4.6 pp 来自一个损坏的归档 2.filter GTI(0202230301),约 5.5 pp 是候选在更难环境下的自身性质(去一观测法 \(-3.2\) 到 \(-6.1\) pp)。The HO-M31 MOS1 \(-10.1\) pp is split: about 4.6 pp from one broken archived 2.filter GTI (0202230301) and about 5.5 pp a candidate property in a harder regime (leave-one-out \(-3.2\) to \(-6.1\) pp).
- 下一个测试(P007)的规则草稿 1:主估计量 = 六个"天空集 \(\times\) 相机"格的等权平均 \(\bar D\) 对 EH_B1000_n2(\(\delta_0=0.5\) pp,带伤害守卫与"六格全有效");主列表 = 发展数据上 \(\bar D\) 最低的 5 个候选(暂定,待 R41 排全部 83 个)。判决代码
p007_verdict.py已写好并在发展数据上自检通过。真零假设下的规模 \(\leq 3\%\)(集 A)/ 1.4%(集 C);发展集功效只报区间(0.013–0.164,最强候选 0.21–0.68),不给单一数字。Rule draft 1 for the next test (P007): the primary estimand is the equal-weight mean \(\bar D\) over the six sky-set \(\times\) camera cells vs EH_B1000_n2 (\(\delta_0=0.5\) pp, with a harm guard and all-cells-valid); the primary list is the 5 candidates with the lowest development \(\bar D\) (provisional until R41 ranks all 83). The verdict codep007_verdict.pyis written and passes its self-checks on development data. Size under true nulls \(\leq 3\%\) (set A) / 1.4% (set C); development power is quoted only as a range (0.013–0.164, the strongest candidate 0.21–0.68), never a single figure. - 新参照 QFG(只用光变曲线、无 2.filter、无角落)通过发展筛选 8/8;在已用过的保留集数据上对 2.filter Confirmed 6/6,但对 EH_B1000_n2 Not confirmed(\(\bar D=-0.70\) pp,Ambiguous)—— 一个比 EH 弱的"地板"参照。The new reference QFG (light curves only, no 2.filter, no corner) passes the development screen 8/8; on the spent held-out data it is Confirmed 6/6 vs 2.filter but Not confirmed vs EH_B1000_n2 (\(\bar D=-0.70\) pp, Ambiguous) — a "floor" reference weaker than EH.
工作 / WorkWork
- 研究步骤 R29–R39 全部完成(免费执行者 codexnim / Hermes 与 Claude 自算);红队检查 RT-72 至 RT-81 共 10 个,全部三审并复算。Research steps R29–R39 all finished (free executors codexnim / Hermes plus Claude's own runs); 10 red-team checks RT-72 to RT-81, all triaged and replayed.
- 本手册刷新(H008)派发:新增组会页、论文草稿页与报告页。This handbook refresh (H008) dispatched: new group-meeting, paper-draft and seminar pages.
问题 / ProblemsProblems
- 红队 RT-72 的方法错误(伤害按 p84 计而非冻结规则的 p16)由 Claude 在三审中重算修正(实为 0/8)。等保留时间读数对种子脆弱(0–1 摆动),降为描述性。R36 的 0.42 功效数字被撤回(样本内值),主估计量按 D077 重写。Red-team RT-72's method error (harm counted at p84 instead of the frozen p16) was recomputed and corrected by Claude in triage (it is 0/8). The matched-kept-time reading is seed-fragile (swinging 0–1) and demoted to descriptive. R36's 0.42 power figure was withdrawn (in-sample) and the primary estimand rewritten per D077.
待 PI 决定 / For the PIFor the PI
- P007 数据集:最小成本集 A(32 观测,默认)还是更大更有功效的集 C(54 观测)。NGC 5907 场是否接受为"同天扩展"(默认"接受")。保留时间是否留在判决之外(默认"是")。P007 data: the minimal-cost set A (32 observations, default) or the larger, more powerful set C (54). Whether the NGC 5907 field is accepted as same-sky extension (default "accept"). Whether kept time stays outside the verdict (default "yes").
来源:cognition-os/04_DECISION_LOG.md D070–D079;experiments/E024_p006_heldout_verdict.md 及其修订;prereg/P007_rule_draft.md;更早的组会块见组会页。Source: cognition-os/04_DECISION_LOG.md D070–D079; experiments/E024_p006_heldout_verdict.md and its amendments; prereg/P007_rule_draft.md; earlier days on the meetings page.
更早的组会日(2026-10-18:P006 冻结与判决;2026-10-17:家族成员频率与保留集普查)—— 组会页。
Earlier meeting days (2026-10-18: the P006 freeze and verdict; 2026-10-17: family membership and the held-out census) — meetings page.
这是什么项目? XMM-Newton 望远镜每次观测都会被软质子 (soft proton) 耀斑污染,必须用"好时间段 (good time interval, GTI)"把耀斑时间删掉。删多删少是一对矛盾:多删 → 剩下的数据更干净但更少;少删 → 数据多但更脏。ParetoGTICal 把这个取舍当作一个帕累托问题 (Pareto problem):在单次观测内部,用保留活时间 \(f_T\) 与连续谱约减因子 \(R\) 两个坐标给每个候选 GTI 打分,并用 Al-K、Si-K 荧光线的不变性做门 (gate),防止"挑噪声"伪装成"删耀斑"。
\[ f_T=\frac{T_K}{T_{\mathrm{all}}},\qquad R=\frac{C_{\mathrm{all}}}{C_K} \]
其中 \(T_K\) 是候选 GTI 保留的活时间,\(T_{\mathrm{all}}\) 是全部活时间;\(C_{\mathrm{all}}\) 是全时段连续谱计数率,\(C_K\) 是保留时间 \(K\) 上的同一量。\(R>1\) 说明删掉的时间确实更亮。它属于父项目 DiffuseXrayCalibration (校准 XMM EPIC 弥散发射分析),但有自己的问题、自己的认知操作系统 (cognition OS) 和自己的预注册 (pre-registration) 纪律。
What is this project? Every XMM-Newton observation is polluted by soft-proton flares, and "bad" time must be removed by keeping only good time intervals (GTIs). How much to cut is a genuine conflict: cut more and the retained data are cleaner but fewer; cut less and there are more data but dirtier ones. ParetoGTICal treats this trade-off as a Pareto problem: within one observation, every candidate GTI is scored by two coordinates — the retained live time \(f_T\) and the continuum reduction factor \(R\) — with an Al-K / Si-K fluorescence-line stability gate that stops "selecting noise" from masquerading as "cutting flares".
\[ f_T=\frac{T_K}{T_{\mathrm{all}}},\qquad R=\frac{C_{\mathrm{all}}}{C_K} \]
where \(T_K\) is the live time the candidate GTI keeps and \(T_{\mathrm{all}}\) the total live time; \(C_{\mathrm{all}}\) is the all-time continuum rate and \(C_K\) the same quantity over the retained time \(K\). \(R>1\) means the discarded time really was brighter. It is a sub-project of DiffuseXrayCalibration (calibrating the XMM EPIC diffuse-emission analysis), with its own question, its own cognition OS and its own pre-registration discipline.
2026-10-19 新页:组会档案(每日一块,成果 / 工作 / 问题 / 待 PI 决定)、论文草稿(ApJ 结构)与 报告幻灯片加完整讲稿。现在读哪里:想知道今天发生了什么 → 本页顶部的组会块;想知道项目整体在哪 → 现状页;想接手做下去 → 如何接手;十个政策的光变曲线、帕累托前沿与 M31 竖直剖面 → 前沿策略对比(2026-10-16)与 MS 策略专页。New 2026-10-19: the group-meeting archive (one block per day: Results / Work / Problems / For the PI), the paper draft (ApJ structure) and the seminar slides with the full talk script. Where to read: what happened today → the meeting block at the top of this page; where the project stands → the state page; how to continue → By hand; the ten policies' light curves, Pareto fronts and M31 vertical profile → Frontier policies (2026-10-16) and the MS policy page.
四个问题,一屏作答Four questions, answered on one screen
- 现在在哪?
- Where does it stand?
- P001 已关闭(D006),答案否定:等保留率下率排名在任何主集上都不优于 2.filter。此后项目转向误差预算判据(C001):多观测时一致性比信噪比重要。交付物是一个帕累托政策族(非支配集,覆盖代价 \(\lambda\) 可调)。2026-10-18 跑完了第一次保留集判决:在 119 个从未参与开发的观测上,83 个冻结候选中 79 个相对归档 2.filter 是 Confirmed(23 个家族)—— 但 2.filter 是弱参照,对复现的标准光变曲线滤波器只剩 11/83,且都靠更短的保留时间。下一个测试(P007)已写成规则草稿:主估计量是六个格的等权平均 \(\bar D\) 对复现滤波器,代码已就绪。
- P001 is closed (D006), negative: at equal retention rate-rank does not beat 2.filter on any primary set. The project then turned to the error-budget criterion (C001): over several observations, consistency matters more than S/N. The deliverable is a Pareto policy family (a non-dominated set with a tunable coverage price \(\lambda\)). On 2026-10-18 the first held-out verdict ran: on 119 observations that took no part in development, 79 of 83 frozen candidates are Confirmed relative to the archived 2.filter (23 families) — but 2.filter is a weak reference, so against the reproduced standard light-curve filter only 11 of 83 survive, and all of them by keeping less time. The next test (P007) is written as a rule draft: the primary estimand is the equal-weight mean \(\bar D\) over six cells versus the reproduced filter, and the verdict code is ready.
- 还有什么没解决?
- What is unsolved?
- ① 候选是否真的优于一个复现的标准光变曲线滤波器?对单个参照(EH_B1000_n2)只剩 11/83,且保留时间更短;对"等保留时间的最好复现滤波器"配对自举是 0–1/83 —— 未确立,这正是 P007 要预先注册回答的问题。② Al-K 线门几乎从未触发(每格 0–3 个观测),所以保留集判决没有检验它。③ 谱验证(C2)还没做 —— 快速判据最终要用光谱一致性检验。④ 为什么三个复制集给出 \(b\approx0.6\text{–}0.7\)(P002 F1 复制失败,原因未测)。
- ① Do the candidates really beat a reproduced standard light-curve filter? Against the single reference (EH_B1000_n2) only 11 of 83 survive, and they keep less time; against the best reproduced-filter setting at matched kept time a paired bootstrap gives 0–1 of 83 — not established, which is exactly the question P007 pre-registers. ② The Al-K line gate almost never fires (0–3 observations per cell), so the held-out verdict does not test it. ③ Spectral validation (C2) is still to come — the quick criterion must finally be checked against spectral consistency. ④ Why do the three replication sets give \(b\approx0.6\text{–}0.7\) (the P002 F1 replication fails; causes untested).
- 接下来做什么?
- What do I do next?
- 按记录:(a) P007 冻结与运行 —— 规则草稿 1 已写(主估计量、伤害守卫、状态、参照、运行常数),判决代码
p007_verdict.py已就绪;待 PI 定数据集(集 A 32 观测默认,或集 C 54 观测)与 NGC 5907 场的处置,然后冻结、还原、打分、判决、红队。(b) 谱验证 C2 与 P002 F2 等 PI 派发。(c) 发展集功效只报区间,不给单一数字(D079)。步骤格式见"如何接手"页 §5。 - Per the records: (a) freeze and run P007 — rule draft 1 is written (primary estimand, harm guard, states, references, run constants) and the verdict code
p007_verdict.pyis ready; the PI settles the data set (set A, 32 observations, by default, or set C, 54) and the NGC 5907 field, then freeze, reduce, score, verdict, red-team. (b) Spectral validation C2 and P002 F2 await the PI's dispatch. (c) Development power is quoted only as a range, never a single figure (D079). Step formats on the "By hand" page §5.
目标表(PI 工作单,D002,2026-10-13)Objectives (the PI's work order, D002, 2026-10-13)
| # | 目标Objective | 状态Status | 最好的当前数字(来源)Best current number (source) | 趋势Trend |
|---|---|---|---|---|
| 1 | 事实纠错认知 OSFact-correct the cognition OS | DONE | D002 + I002:训练/保留集(19 训练、11 保留)2026-09-14 已冻结且已消费;两个度量族 R 与 G_Al;数据是 M31 MOS2 不是 CDFS。D002 + I002: the train/holdout split (19 training, 11 holdout) was frozen and scored on 2026-09-14; two metric families R and G_Al exist; the data are M31 MOS2, not CDFS.
来源:Source: ParetoGTICal/cognition-os/04_DECISION_LOG.md (D002); insights/I002_historical_evidence_reconciliation.md |
→ |
| 2 | 扩展到 MOS1 + 空白场对照Extend to MOS1 + blank-field control | DONE | M31 MOS1 盲测(E002)与 CDFS 空白场盲测(E003,34/34 ObsID \(\times\) 2 相机)均完成。E3 在所有主集上失败;CDFS 的增益方向一致但只有约 0.3%(描述性)。角落:CDFS 可用,M31 MOS1 太吵。Both halves done: the blind M31 MOS1 run (E002) and the CDFS blank-field blind run (E003, 34/34 ObsIDs \(\times\) 2 cameras). E3 fails on every primary set; the CDFS gain is consistent in sign but only about 0.3% (descriptive). Corner: usable on CDFS, too noisy on M31 MOS1. | → |
| 3 | 定义下游成功判据Define the downstream success criterion | 已定义(C001);保留集判决规则已跑一次(P006),下一个测试 P007 已写规则草稿DEFINED (C001); the held-out verdict rule has run once (P006); the next test P007 has a rule draft | 判据 = 误差预算(D007/D008):单观测 \(\sigma_{\mathrm{tot}}=\sigma_{\mathrm{stat}}\oplus\varepsilon\cdot C_K\);多观测先看一致性(拼接光变曲线的 \(s_{\mathrm{sys}}\),不随观测数下降)。实测(2.filter,0.5–2 keV):\(s_{\mathrm{sys}}=17\text{–}25\%\)(观测内 11–13%、观测间 12–22%),而 \(s_{\mathrm{stat}}\) 只有 0.04–0.2% —— 系统误差约是统计误差的 \(100\) 倍。打分 cell 尺寸 1000 s(D012)。注意(D019):\(\sigma_R\) 只是观测内的拼接风险,没有观测间水平项,剔除观测几乎不增加它;\(\sigma_{\mathrm{tot}}\) 可被子集选择操纵,只作描述。P006 判决(E024,D068):83 个候选中 79 个相对归档 2.filter Confirmed,中位 \(\delta\) 为 HO-M31 MOS1 \(-10.1\) pp、MOS2 \(-3.7\);HO-blank MOS1 \(-3.2\);HO-mixed \(-2.9\) / \(-3.5\) pp。P007 规则草稿(D075/D077):主估计量 = 六格等权平均 \(\bar D\) 对复现滤波器 EH_B1000_n2,\(\delta_0=0.5\) pp,带伤害守卫;规模 \(\leq 3\%\),功效只报区间。The criterion is the error budget (D007/D008): for a single observation \(\sigma_{\mathrm{tot}}=\sigma_{\mathrm{stat}}\oplus\varepsilon\cdot C_K\); over a set, consistency comes first (the concatenated-light-curve \(s_{\mathrm{sys}}\), which does not fall with the number of observations). Measured (2.filter, 0.5–2 keV): \(s_{\mathrm{sys}}=17\text{–}25\%\) (within 11–13%, between 12–22%) against \(s_{\mathrm{stat}}\) of only 0.04–0.2% — the systematic is about \(100\times\) the statistical. Scoring cell size 1000 s (D012). Note (D019): \(\sigma_R\) is the within-observation mosaic risk only, with no between-observation level term, so dropping observations is almost free; \(\sigma_{\mathrm{tot}}\) can be gamed by subset selection and is descriptive only. P006 verdict (E024, D068): 79 of 83 candidates Confirmed vs the archived 2.filter, median \(\delta\) HO-M31 MOS1 \(-10.1\) pp, MOS2 \(-3.7\); HO-blank MOS1 \(-3.2\); HO-mixed \(-2.9\) / \(-3.5\) pp. P007 rule draft (D075/D077): primary estimand = the equal-weight mean \(\bar D\) over six cells vs the reproduced filter EH_B1000_n2, \(\delta_0=0.5\) pp, with a harm guard; size \(\leq 3\%\), power quoted only as a range. | ↗ |
| 5 | Al 线是否跟随角落粒子水平?(P002)Does the Al line track the corner particle level? (P002) | F1 已跑;TRACKS 读数已撤回,未在一般意义上确立F1 run; the TRACKS reading is withdrawn; not established in general | F1 斜率 \(b\)(\(\ln L_{\mathrm{Al}}\) 对 \(\ln Q\),观测之间)。原读数"CDFS MOS2 \(b=1.015\pm0.030\) → TRACKS"已于 2026-10-15 撤回(红队检查 RT-02,E004 更正):这是观测时期(epoch)造成的假象;冻结代码加每时期偏移后 \(b=0.690\pm0.020\),与其他三集(CDFS MOS1 \(0.588\pm0.020\)、M31 MOS2 \(0.602\pm0.070\)、M31 MOS1 \(0.694\pm0.050\))一样属"中间",即约 \(0.6\text{–}0.7\)。按 §6,"Al 线是粒子监测器"未在一般意义上确立;F2(观测之内)等 Lockman Hole。F3:线在观测之间部分跟随 \(Q\)、观测之内不跟随 —— 指向线测量里的 K/B 系统误差(T005 处置)。The F1 slope \(b\) (\(\ln L_{\mathrm{Al}}\) on \(\ln Q\), between observations). The original reading "CDFS MOS2 \(b=1.015\pm0.030\) → TRACKS" was withdrawn on 2026-10-15 (red-team check RT-02, E004 correction): it is an epoch artefact; the frozen code with per-epoch offsets gives \(b=0.690\pm0.020\), INTERMEDIATE like the other three sets (CDFS MOS1 \(0.588\pm0.020\), M31 MOS2 \(0.602\pm0.070\), M31 MOS1 \(0.694\pm0.050\)), i.e. about \(0.6\text{–}0.7\). Per §6, "the Al line is a particle monitor" is not established in general; F2 (within observations) waits for the Lockman Hole. F3: the line partly follows \(Q\) between observations but not within them — pointing to a K/B systematic in the line measurement (the T005 disposition). | → |
| 4 | 开放问题:未曝光角落有没有用?Open question: is the unexposed corner useful? | 已按数据集回答(D006)ANSWERED per set (D006) | 精度(叠加 \(\sigma\)):CDFS MOS1 = 0.0044、MOS2 = 0.0038 → USABLE;M31 MOS2 参考 = 0.0098 → 勉强可用;M31 MOS1 = 0.0133 → TOO_NOISY。它还在 CDFS 上看到了真实的 K/B 粒子级差:被删时间的角落 2.5–8 keV 率高 1.9%(MOS1,\(-4.3\sigma\))与 3.9%(MOS2,\(-10\sigma\))。新的开放子问题(未经预注册):角落的粒子水平变化不带入门内 Al 线比。Precision (stacked \(\sigma\)): CDFS MOS1 = 0.0044, MOS2 = 0.0038 → USABLE; M31 MOS2 reference = 0.0098 → usable by a hair; M31 MOS1 = 0.0133 → TOO_NOISY. It also sees a real K/B particle-level difference on CDFS: rejected time has a 1.9% (MOS1, \(-4.3\sigma\)) and 3.9% (MOS2, \(-10\sigma\)) higher corner 2.5–8 keV rate. New open sub-question (not pre-registered): the corner's particle-level change does not carry into the as-gated Al-line ratio. | → |
开放问题表Open problems
| 问题Problem | 为什么重要Why it matters | 当前最好的假设Best current hypothesis | 下一个检验Next test | 所有者 / 状态Owner / status |
|---|---|---|---|---|
| 候选政策真的优于一个复现的标准光变曲线滤波器吗?(保留集判决的三次收窄)Do the candidates really beat a reproduced standard light-curve filter? (the held-out verdict narrowed three times) | 这是"我们的方法是否真的更好"的最终判据:对归档 2.filter 的 79/83 不能当成对一个标准滤波器的胜利,因为 2.filter 是弱参照。This is the final test of "is our method really better": 79/83 against the archived 2.filter cannot be read as a win over a standard filter, because 2.filter is a weak reference. | 对单个复现滤波器 EH_B1000_n2 只有 11/83(6 个家族),且全部保留更少时间(0.32–0.76 对 0.81–0.93);对"等保留时间的最好复现滤波器"配对自举 0–1/83(点估计 37/83,对种子脆弱)。结论:未确立—— 候选可能真有优势,但现有数据不足以在等保留时间下确立它。Against the single reproduced filter EH_B1000_n2 only 11 of 83 (6 families), all keeping less time (0.32–0.76 vs 0.81–0.93); against the best reproduced-filter setting at matched kept time a paired bootstrap gives 0–1 of 83 (point estimate 37/83, seed-fragile). Conclusion: not established — the candidates may well be better, but the data so far do not establish it at matched kept time. | P007(规则草稿 1 已写,判决代码已就绪):预先注册"六格等权平均 \(\bar D\) 对 EH_B1000_n2,\(\delta_0=0.5\) pp,伤害守卫,六格全有效";待 PI 定数据集后冻结并运行。P007 (rule draft 1 written, verdict code ready): pre-register "the equal-weight six-cell mean \(\bar D\) vs EH_B1000_n2, \(\delta_0=0.5\) pp, harm guard, all cells valid"; freeze and run once the PI settles the data set. | T046 / provisional(未确立,三次收窄后)Provisional (not established, after three narrowings)T046 / Provisional (not established, after three narrowings) |
| Al-K 线门在保留集上几乎不触发 —— 它到底有没有用?The Al-K line gate almost never fires on held-out data — does it work at all? | 线门是防止"挑噪声伪装成删耀斑"的核心保险;如果它在真实数据上从不触发,就既不能证明有用,也不能证明无用。The line gate is the core insurance against "selecting noise masquerading as cutting flares"; if it never fires on real data it can be shown neither useful nor useless. | 保留集判决里它每个"格"只在 0–3 个观测上触发;两个线门候选(LG.FLRr、XJLG.FLRr)的确认实际检验的是它们的基底政策,不是门本身。In the held-out verdict it fires on 0–3 observations per cell; the two line-gate candidates (LG.FLRr, XJLG.FLRr) are confirmed on their base policies, not on the gate. | P007 规则里写明:只有当可门控观测数达到预设值才给线门判决,否则报告"检验的是基底政策";并打印每格的可门控数(集 A 预期 10.1 / 7.3 / 8.4)。The P007 rule states: a line-gate verdict only when the gateable count reaches the pre-set value, otherwise "tests its base policy"; the gateable counts are printed per cell (set A expected 10.1 / 7.3 / 8.4). | E024 / 未检验UNTESTEDE024 / UNTESTED |
| R 筛选在等保留率下是否优于归档 2.filter?Does the R screen beat the archived 2.filter at equal retention? | 这是 P001 的主要终点;若不优于,方法的全部价值就只剩"选保留率"这一层。This was P001's primary endpoint; if not, the method's whole value reduces to "choosing a retention". | 不优于(已关闭):四个主集的 E3 全部失败 —— M31 MOS1 13/25(Z = 0.02)、M31 MOS2 21/29(Z = 1.64)、CDFS MOS1 24/29(Z = 1.55)、CDFS MOS2 27/29(Z = 1.73)。CDFS 上符号一致但增益约 0.3%,远低于 Z > 3;按 D7 记"持平"。Not better (closed): E3 fails on all four primary sets — M31 MOS1 13/25 (Z = 0.02), M31 MOS2 21/29 (Z = 1.64), CDFS MOS1 24/29 (Z = 1.55), CDFS MOS2 27/29 (Z = 1.73). On CDFS the sign is consistent but the gain is about 0.3%, far below Z > 3; "no significant difference" under D7. | 已由 CDFS 盲测完成(E003):证据收据 p001_endpoints_all.json。问题关闭。Done by the CDFS blind run (E003); receipt p001_endpoints_all.json. The question is closed. |
T019 / 在 M31 与 CDFS 上被驳倒REFUTED on M31 and CDFST019 / REFUTED on M31 and CDFS |
| Al 线是否跟随角落粒子水平?(P002 F1/F2)Does the Al line track the corner particle level? (P002 F1/F2) | 若跟随,P001 线门(L_K = L_B)就要允许 L_K/L_B = Q_K/Q_B;若不跟随,线门成立。这决定线门作为粒子锚是否可信(T005/T016)。If it tracks, the P001 line gate (L_K = L_B) must allow L_K/L_B = Q_K/Q_B; if not, the gate stands. This decides whether the line gate is a trustworthy particle anchor (T005/T016). | F1 已答,但 TRACKS 读数已撤回(E004 2026-10-15 更正,D026):原读数"CDFS MOS2 \(b=1.015\pm0.030\) → TRACKS"是观测时期(epoch)造成的假象;冻结代码加每时期偏移后 CDFS MOS2 \(b=0.690\pm0.020\),与其余三集 \(b=0.588\pm0.020\)、\(0.602\pm0.070\)、\(0.694\pm0.050\) → INTERMEDIATE。按 §6 未在一般意义上确立。F3:CDFS MOS2 观测之间跟随、观测之内不跟随 → 线测量里的 K/B 系统误差(T005)。F1 is answered but the TRACKS reading is withdrawn (E004 correction 2026-10-15, D026): the original "CDFS MOS2 \(b=1.015\pm0.030\) → TRACKS" was an epoch artefact; the frozen code with per-epoch offsets gives CDFS MOS2 \(b=0.690\pm0.020\), and the other three sets give \(0.588\pm0.020\), \(0.602\pm0.070\), \(0.694\pm0.050\) → INTERMEDIATE. Per §6, not established in general. F3: on CDFS MOS2 the line follows Q between observations but not within them → a K/B systematic in the line measurement (T005). | F2(观测之内)等一次新的 Lockman Hole 还原(派发由 PI 决定);\(b\approx0.6\text{–}0.7\) 的成因需要自己的预注册(未测:MOS1 几何与 CCD 损失、M31 天空 1.49 keV 贡献、短杠杆臂、不激发 Al 的 Q 分量)。F2 (within observations) waits for one fresh Lockman Hole reduction (dispatched by the PI); the causes of \(b\approx0.6\text{–}0.7\) need their own pre-registration (untested: MOS1 geometry and CCD losses, an M31 sky contribution at 1.49 keV, the short lever arm, and a Q component that does not excite Al). | T022 / 主集支持,复制未确认Supported for primary only; not replicatedT022 / Supported for primary only; not replicated |
| C1b 滤波器在新场上成立吗?Does the C1b filter hold on a fresh field? | C1b 是把 GTI 从"删耀斑"升级为"压观测内系统误差"的第一个具体候选;若在 Lockman Hole 上复现,C001 的 ~2% 目标(\(\ge1000\) s)就有一个可冻结的滤波器。C1b is the first concrete candidate that upgrades the GTI from "cutting flares" to "suppressing the within-observation systematic"; if it replicates on the Lockman Hole, C001's ~2% target (\(\ge1000\) s) gets a freezable filter. | 在已消费的 CDFS 与 M31 上成立(T023,探索性):观测内 11.6–12.7% → 4.7–6.0%(100 s),观测间不升高(CDFS 2.1–2.8%),代价 20–26% 活时间;H(2.5–8 keV)与 S(减半薄化)一致。未在新场或谱上验证。It holds on consumed CDFS and M31 (T023, exploratory): within 11.6–12.7% → 4.7–6.0% (100 s), the between term does not rise (CDFS 2.1–2.8%), at a 20–26% live-time cost; H (2.5–8 keV) and S (thinned halves) agree. Not validated on a fresh field or on spectra. | 已冻结(D012):H,B = 300 s,n = 1,在 2.filter 之内(commit abc5e602;打分 cell 1000 s)。下一步:一次 Lockman Hole 还原同时检验它与 P002 F2;谱上由 C2 检验。Frozen (D012): H, B = 300 s, n = 1, inside 2.filter (commit abc5e602; scoring at 1000 s cells). Next: one Lockman Hole reduction tests it together with P002 F2; C2 tests it on spectra. | T023 / 已消费数据上支持,未验证Supported on consumed data; not validatedT023 / Supported on consumed data; not validated |
| 100 s cell 上约 5% 的快速"白"残差从哪来?Where does the ~5% fast "white" residual at 100 s cells come from? | 它决定 C001 打分 cell 尺寸的选择:100 s 上它把观测内项顶在 ~5%,\(\ge1000\) s 时只剩 0–2.6%;它不跟随角落,且会从任何谱中平均掉。已定(D012):主打分用 1000 s cell,100 s 与 3000 s 作诊断。It decides the choice of C001 scoring cell size: at 100 s it floors the within term at ~5%, at \(\ge1000\) s only 0–2.6% remains; it does not follow the corner and averages out of any spectrum. Decided (D012): the primary score uses 1000 s cells, with 100 s and 3000 s as diagnostics. | 两个未测的解释(E005/E006):仪器事件聚簇(超泊松计数,100 s 处 Fano 因子 1.11–1.19,2.5 s 处 \(\approx1.03\) —— 相关时间几十秒以上;非闪烁像素),或裁剪阈值以下的快速软质子闪烁。检验方法:对只有粒子能到达的未曝光角落 0.5–2 keV 事件算同一统计量。Two untested explanations (E005/E006): instrumental event clustering (super-Poisson counting, Fano factor 1.11–1.19 at 100 s, \(\approx1.03\) at 2.5 s — a correlation time of tens of seconds; not flickering pixels), or fast soft-proton flicker below the clip threshold. A test: the same statistic on unexposed-corner 0.5–2 keV events, which only particles reach. | 建议(未经评审):角落 0.5–2 keV 残差统计;结果并入 cell 尺寸或残差起源的后续决定(cell 尺寸本身已由 D012 定为 1000 s)。Suggestion (not reviewed): the corner 0.5–2 keV residual statistic; feed the result into the later decisions on the residual's origin (the cell size itself is already set to 1000 s by D012). | T023 / 未测UNTESTEDT023 / UNTESTED |
| 反事实 Al 亏损(\(-0.028\pm0.013\), MOS2)是真信号吗?Is the counterfactual Al deficit (\(-0.028\pm0.013\), MOS2) real? | 若真,则 L_K = L_B 这个设计级约束本身有偏差;若假,则是未建模系统误差。它决定线门是否可信。If real, the design-level constraint L_K = L_B is itself biased; if not, it is an unmodelled systematic. It decides whether the line gate is trustworthy. | P002 F3 已处置(E004):在 CDFS MOS2 上,线在观测之间跟随 \(Q\)(\(b=1.015\pm0.030\))而观测之内的 K/B 线比不跟随角落 —— 指向线测量里的 K/B 系统误差。这成为 T005 在 MOS2 上的主要处置;P001 线门(\(L_K=L_B\))作为粒子锚仍未被验证。Disposed by P002 F3 (E004): on CDFS MOS2 the line follows \(Q\) between observations (\(b=1.015\pm0.030\)) while the within-observation K/B line ratio does not follow the corner — pointing to a K/B systematic in the line measurement. This is the leading T005 disposition for MOS2; the P001 line gate (\(L_K=L_B\)) stays unvalidated as a particle anchor. | P002 F2(Lockman Hole)与"K/B 线系统误差"的专门预注册;在此之前不关闭。P002 F2 (the Lockman Hole) and a dedicated pre-registration on the K/B line systematic; not closed before that. | T005, T016 / QUESTIONEDT005, T016 / QUESTIONED |
| 角落能否预测 K/B 粒子级变化?Can the corner predict the K/B particle-level change? | 角落在 FOV 外、不经望远镜聚焦,是最干净的粒子监测器;若够准,就能直接检验"Al 亏损 = 粒子变化"。The corner is outside the FOV and receives no focused soft protons — the cleanest particle monitor; if precise enough it can test "Al deficit = particle change" directly. | 已回答(按数据集,D006):CDFS 上够准(\(\sigma=0.0044\) / \(0.0038\))且看到了真实的 K/B 粒子级差(被删时间高 1.9% / 3.9%);M31 MOS1 上太吵(\(\sigma=0.0133\))。所以 2.filter 也删掉了粒子背景升高的时段,不只是软质子时段。Answered (per set, D006): precise enough on CDFS (\(\sigma=0.0044\) / \(0.0038\)) and it sees a real K/B particle-level difference (rejected time 1.9% / 3.9% higher); too noisy on M31 MOS1 (\(\sigma=0.0133\)). So 2.filter also cuts periods of elevated particle background, not only soft-proton time. | 已由 CDFS E5 完成。遗留的子问题(未预注册):Al 线不跟随角落 —— 见上面新行。Done by the CDFS E5. Remaining sub-question (not pre-registered): the Al line does not follow the corner — see the new row above. | T017 / 已按数据集回答ANSWERED per setT017 / ANSWERED per set |
| 被移除的成分是软质子还是可变天体源?Is the removed component soft protons or variable celestial sources? | 这是"删掉的东西到底是什么"的身份问题;M31 盘里有很多可变 X 射线双星,是天体源解释的真实竞争者。This is the identity question — what was actually removed; the M31 disk holds many variable X-ray binaries, a genuine celestial competitor. | A1:移除的超额 ~79% 无线 (Al \(-5.96\sigma\));B1:空间延展、非紧凑,更像软质子花样;但仍不能排除多个微弱可变源。A1: the removed excess is ~79% line-free (Al \(-5.96\sigma\)); B1: extended, not compact — closer to the soft-proton pattern; many faint variable sources are not excluded. | CDFS E6(描述性):CDFS 的中位增益(+0.0035 / +0.0029)比 M31(+0.0005 / +0.0011)大 \(3\text{–}10\) 倍,但同样远低于阈值 —— 与"移除成分主要是软质子、M31 的可变源压低了增益"相容,不构成证明。The CDFS E6 (descriptive): the median CDFS gain (+0.0035 / +0.0029) is \(3\text{–}10\times\) M31's (+0.0005 / +0.0011) but still far below threshold — compatible with "the removed component is mostly soft protons, with M31's variable sources diluting the gain", not proof of it. | T009, T018 / NOT ESTABLISHEDT009, T018 / NOT ESTABLISHED |
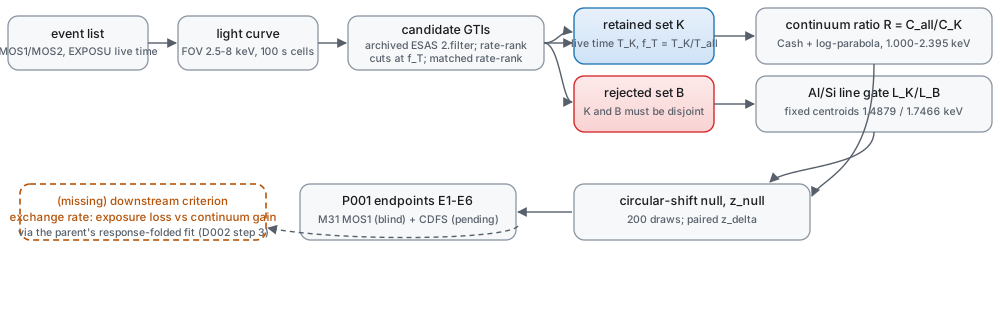
未来 1–4 周计划(按记录 D061–D079;每步给目标、输入、方法、成败检验、时间估计与先读文件)Plan for the next 1–4 weeks (per the records D061–D079; each step with goal, inputs, method, success/failure test, time estimate and the file to read first)
- 已完成:P001 关闭(D006,否定);C001 判据与 C1/C1b 定义并冻结(D007–D012);P006 预注册、83 个候选冻结(D061)、保留集判决跑完(E024,D068)并三次收窄(D070–D074);P007 规则草稿 1 与判决代码
p007_verdict.py写好并在发展数据上自检(D075–D079)。Done: P001 closed (D006, negative); the C001 criterion and C1/C1b defined and frozen (D007–D012); the P006 pre-registration, 83 candidates frozen (D061), the held-out verdict run (E024, D068) and narrowed three times (D070–D074); the P007 rule draft 1 and the verdict codep007_verdict.pywritten and self-checked on development data (D075–D079). - (a) P007 冻结与运行(下一步,主线)。目标:在全新的天空上检验"只用光变曲线、独立于 2.filter、无角落的政策,能否在等保留时间意义下降低观测间散布 \(\sigma_R\)"。输入:规则草稿
prereg/P007_rule_draft.md(主估计量 \(\bar D\)、伤害守卫、状态、参照 (a)–(c)、运行常数)、R31 观测清单(集 A 32 个,默认)、判决代码p007_verdict.py。方法:PI 定数据集与 NGC 5907 场 \(\to\) 冻结规则文本(哈希)\(\to\) 下载/还原(免费执行者)\(\to\) 建缓存 \(\to\) 一次打分 \(\to\) 判决 \(\to\) 红队。成败检验:主列表 5 个候选逐个给出 Confirmed / No gain \(\geq 0.5\) shown / Ambiguous / Invalid;真零假设下规模 \(\leq 3\%\)。时间估计:冻结半天,还原约 1–2 天(免费执行者),打分与判决数小时。先读:prereg/P007_rule_draft.md§1–§10。(a) Freeze and run P007 (next, the main line). Goal: on fresh sky, test whether light-curve-only, 2.filter-independent, corner-free policies lower the between-observation scatter \(\sigma_R\) at matched kept time. Inputs: the rule draftprereg/P007_rule_draft.md(primary estimand \(\bar D\), harm guard, states, references (a)–(c), run constants), the R31 census list (set A, 32 observations, default), the verdict codep007_verdict.py. Method: the PI settles the data set and the NGC 5907 field \(\to\) freeze the rule text (hashed) \(\to\) download/reduce (free executors) \(\to\) build caches \(\to\) one scoring run \(\to\) verdict \(\to\) red team. Success/failure: the 5 primary-list candidates each get Confirmed / No gain \(\geq 0.5\) shown / Ambiguous / Invalid; size under true nulls \(\leq 3\%\). Time: freeze half a day, reduction 1–2 days (free executors), scoring and verdict hours. Read first:prereg/P007_rule_draft.md§1–§10. - (b) R41:给全部 83 个候选排序,定死主列表。目标:把 P007 主列表从"暂定 5 个"变成"按发展数据 \(\bar D\) 排序的全部 83 个中的前 5 个"。输入:R38 功效表、83 个候选的发展集分数。方法:补齐 27 个缺发展集分数的候选(可从 gen3 per_obs 打分),排序,取前 5。成败检验:主列表的期望假 Confirmed \(\leq 0.1\)(全局零假设下)。时间估计:数小时。先读:
04_DECISION_LOG.mdD079。(b) R41: rank all 83 candidates and fix the primary list. Goal: turn the P007 primary list from "5 provisional" into "the top 5 of all 83 ranked by development \(\bar D\)". Inputs: the R38 power table, the 83 candidates' development scores. Method: score the 27 candidates missing development scores (from gen3 per_obs), rank, take the top 5. Success/failure: expected false Confirmed of the primary list \(\leq 0.1\) under a global null. Time: hours. Read first:04_DECISION_LOG.mdD079. - (c) R42:候选的增益有多少来自"删掉灾难观测"而非"删掉更脏的时间"?目标:回答 P007 检验的到底是什么。输入:P006 保留集分数、每观测的 \(\tau^2\) 表。方法:对每个候选分解"增益份额 = 来自被整段删掉的观测 vs 来自同观测内更干净的时间"。成败检验:每个候选打印该份额;若主候选的份额以删观测为主,P007 的解读要写明这一点。时间估计:数小时。先读:
04_DECISION_LOG.mdD079(5)。(c) R42: how much of a candidate's gain comes from "dropping catastrophic observations" rather than "cleaner time"? Goal: say what P007 actually tests. Inputs: the P006 held-out scores, the per-observation \(\tau^2\) tables. Method: for each candidate, decompose the gain share into "from wholly dropped observations" vs "from cleaner time within the kept ones". Success/failure: the share is printed per candidate; if the main candidates' share is drop-dominated, the P007 reading states it. Time: hours. Read first:04_DECISION_LOG.mdD079 (5). - (d) 谱验证 C2 与 P002 F2(等 PI 派发)。目标:把快速判据最终落到光谱一致性上。输入:C1 里最好的 2–3 个政策与 2.filter。方法:用到 MosaicSelfCal CDFS 金/银 cell 上,按 LHB 与 halo 归一化的一致性 \(\tau\) 打分,再上 M31CGM;P002 F2 用一次新的 Lockman Hole 还原同时检验。成功标准:快速判据的排名与谱 \(\tau\) 的排名一致。时间估计:由 PI 决定派发时间。先读:
prereg/C001_error_budget_criterion.md§4。(d) Spectral validation C2 and P002 F2 (await the PI's dispatch). Goal: land the quick criterion on spectral consistency at last. Inputs: the 2–3 best C1 policies and 2.filter. Method: apply them to the MosaicSelfCal CDFS golden/silver cells, score the consistency \(\tau\) of the LHB and halo normalisations, then M31CGM; P002 F2 is tested together with one fresh Lockman Hole reduction. Success: the quick-metric ranking matches the spectral-\(\tau\) ranking. Time: the PI decides the dispatch. Read first:prereg/C001_error_budget_criterion.md§4.
cognition-os/RESEARCH_PLAN.md(R37–R42 行);04_DECISION_LOG.md D061–D079;prereg/P007_rule_draft.md §9–§10;00_AI_BRIEFING.md 状态行。Source: cognition-os/RESEARCH_PLAN.md (rows R37–R42); 04_DECISION_LOG.md D061–D079; prereg/P007_rule_draft.md §9–§10; the 00_AI_BRIEFING.md status line.一分钟看懂核心矛盾(动画)The core conflict in one minute (animation)
光变曲线 + 阈值滑块 → GTI、f_T、保留计数实时更新Light curve + threshold slider → GTI, f_T and retained counts update live
拖动阈值:蓝色是保留的时间 K,红色是被删的 B。f_T 是保留活时间比例;R 用玩具模型模拟"删高率时间为什么会让 R>1"。
Drag the threshold: blue is kept time K, red is rejected B. f_T is the retained live-time fraction; R uses a toy model to show why cutting high-rate time gives R > 1.
本次更新What's new
2026-10-19(第五次更新,组会页与论文/报告两页新增;折入 D058–D079):
2026-10-19 (fifth edition; new group-meeting, paper-draft and seminar pages; D058–D079 folded in):
- 新页面:组会档案(meetings.html)—— 每个 UTC 日一块,四部分固定为成果 / 工作 / 问题 / 待 PI 决定,只用有日期的记录写;首页顶部是最新一天的完整块,更早的是一行链接。New page: the group-meeting archive (meetings.html) — one block per UTC day with the four fixed parts Results / Work / Problems / For the PI, written only from dated records; the home page carries the latest day in full and earlier days as one-line links.
- 新页面:论文草稿(paper.html)与报告幻灯片加完整讲稿(seminar.html)—— 面向不认识本项目的graduate student与教授,按普通期刊与组会实践写;只收已确立的结果,每个数字带来源标记。New pages: the paper draft (paper.html) and the seminar slides with the full talk script (seminar.html) — written for graduate students and professors who do not know the project, following ordinary journal and seminar practice; only established results, every number with a source marker.
- 保留集判决跑完(P006,2026-10-18):在 119 个从未参与开发的观测上,83 个冻结候选中 79 个相对归档 2.filter 是 Confirmed(23 个家族),中位 \(\delta\) 为 HO-M31 MOS1 \(-10.1\) pp、MOS2 \(-3.7\) pp;HO-blank \(-3.2\) / \(-2.9\);HO-mixed \(-2.9\) / \(-3.5\) pp。判决由冻结代码链产生,Claude 逐字节重放,红队执行 QA 0 条实质问题。The held-out verdict ran (P006, 2026-10-18): on 119 observations that took no part in development, 79 of 83 frozen candidates are Confirmed against the archived 2.filter (23 families), median \(\delta\) HO-M31 MOS1 \(-10.1\) pp, MOS2 \(-3.7\) pp; HO-blank \(-3.2\) / \(-2.9\); HO-mixed \(-2.9\) / \(-3.5\) pp. The verdict came from the frozen code chain, was replayed byte-identically by Claude, and the red-team execution QA found 0 material.
- 同日三次收窄(诚实限定,全部复算):① 2.filter 是弱参照 —— 204 个非候选政策里也有 50 个通过同一规则;② 对复现的标准光变曲线滤波器(espfilt 加硬段裁剪,EH_B1000_n2)只剩 11/83,且全部保留更少时间(0.32–0.76 对 0.81–0.93);③ 对"等保留时间的最好复现滤波器"配对自举 0–1/83(点估计 37/83,对种子脆弱)—— 未确立。Three narrowings the same days (honest limits, all replayed): ① 2.filter is a weak reference — 50 of 204 non-candidate policies also pass the same rule; ② against the reproduced standard light-curve filter (espfilt plus a hard-band clip, EH_B1000_n2) only 11 of 83 survive, all keeping less time (0.32–0.76 vs 0.81–0.93); ③ against the best reproduced-filter setting at matched kept time a paired bootstrap gives 0–1 of 83 (point estimate 37/83, seed-fragile) — not established.
- HO-M31 MOS1 的 \(-10.1\) pp 拆分(R29):约 4.6 pp 来自一个损坏的归档 2.filter GTI(0202230301),约 5.5 pp 是候选在更难环境下的自身性质(去一观测法 \(-3.2\) 到 \(-6.1\) pp)。Al-K 线门每格只在 0–3 个观测上触发,所以判决没有检验它。The HO-M31 MOS1 \(-10.1\) pp is split (R29): about 4.6 pp from one broken archived 2.filter GTI (0202230301) and about 5.5 pp a candidate property in a harder regime (leave-one-out \(-3.2\) to \(-6.1\) pp). The Al-K line gate fires on 0–3 observations per cell, so the verdict does not test it.
- P007 规则草稿 1 与判决代码就绪(D075–D079):主估计量 = 六格等权平均 \(\bar D\) 对 EH_B1000_n2(\(\delta_0=0.5\) pp,伤害守卫,六格全有效);状态 Confirmed / No gain \(\geq 0.5\) shown / Ambiguous / Invalid;规模 \(\leq 3\%\)(集 A)/ 1.4%(集 C);发展集功效只报区间(0.013–0.164)。R36 的 0.42 功效数字被撤回(样本内值)。The P007 rule draft 1 and the verdict code are ready (D075–D079): primary estimand = the equal-weight six-cell mean \(\bar D\) vs EH_B1000_n2 (\(\delta_0=0.5\) pp, harm guard, all cells valid); states Confirmed / No gain \(\geq 0.5\) shown / Ambiguous / Invalid; size \(\leq 3\%\) (set A) / 1.4% (set C); development power quoted only as a range (0.013–0.164). R36's 0.42 power figure was withdrawn (in-sample).
- 新参照 QFG(只用光变曲线、无 2.filter、无角落)通过发展筛选 8/8;在已用过的保留集数据上对 2.filter Confirmed 6/6,但对 EH_B1000_n2 Not confirmed(\(\bar D=-0.70\) pp,Ambiguous)。The new reference QFG (light curves only, no 2.filter, no corner) passes the development screen 8/8; on the spent held-out data it is Confirmed 6/6 vs 2.filter but Not confirmed vs EH_B1000_n2 (\(\bar D=-0.70\) pp, Ambiguous).
- P002 F1 的"CDFS MOS2 TRACKS"读数已于 2026-10-15 撤回(红队检查 RT-02,E004 更正):那是观测时期造成的假象,加每时期偏移后 \(b=0.690\pm0.020\),四集都是"中间"。The P002 F1 "CDFS MOS2 TRACKS" reading was withdrawn on 2026-10-15 (red-team check RT-02, E004 correction): it was an epoch artefact; with per-epoch offsets \(b=0.690\pm0.020\) and all four sets are INTERMEDIATE.
2026-10-16(第四次更新,新增前沿策略对比页;当日二次折入 D2 记录):
2026-10-16 (fourth edition, a new frontier-policies page, with the D2 records folded in the same day):
- 新页面"前沿策略对比"(frontier.html):十个 GTI 政策(2.filter、6 个搜索政策、MS_z3.5_core、EH_B1000_n2、Q_d0.05_n2、none)的光变曲线、单观测与全观测叠加的帕累托前沿、31 观测配对一致性、M31 竖直剖面,以及"某政策在前沿哪里"的下拉选择(选一个政策,两张前沿图换成它的高亮版)。每张图背后的"未检出"与"待 PI 决定"都写明。New page "Frontier policies" (frontier.html): light curves, the single-observation and stacked Pareto fronts, the 31-observation paired consistency, and the M31 vertical profile for ten GTI policies (2.filter, 6 search policies, MS_z3.5_core, EH_B1000_n2, Q_d0.05_n2, none), plus a "where does policy X sit" dropdown that switches both front figures to the chosen policy's highlighted version. The "not detected" and the "pending with the PI" are stated alongside every figure.
- 头条数字:在 25 个没人设计过的测试观测上,
gen2:hermes.FLR_z3把叠加 \(\sigma_R\) 从 5.15% 降到 3.81%(MOS1,配对差 −1.34 pp,自举展宽 [−1.98, −0.65])、从 5.84% 降到 3.93%(MOS2,−1.92 [−2.58, −1.18]),保留 0.85–0.87 的活时间;FLR_z3、MS_z3.5_core、RT3_h2.5_l1 这 3 个政策在 4 个集 \(\times\) 2 台相机共 8 种组合上都优于 2.filter(R9)。Headline: on the 25 test observations no designer saw,gen2:hermes.FLR_z3takes the stacked \(\sigma_R\) from 5.15% to 3.81% (MOS1, paired difference −1.34 pp, bootstrap spread [−1.98, −0.65]) and from 5.84% to 3.93% (MOS2, −1.92 [−2.58, −1.18]) while keeping 0.85–0.87 of live time; these 3 policies (FLR_z3, MS_z3.5_core, RT3_h2.5_l1) beat 2.filter in all 8 \(\text{set}\times\text{camera}\) cases (4 sets \(\times\) 2 cameras; R9). - 同日折入的诚实限定:① RT-16 F-01 —— 优势主要是修好 2.filter 失效的观测(M31 MOS1 去掉 2 个最差观测后 FLR_z3 只剩 −0.79 pp,MS_z3.5_core 变成 +0.33 pp 持平);② RT-18 —— \(\sigma_{RC}\) 降级,只用 \(\sigma_R\) 排名并另报每个政策丢掉的观测数;③ E022 —— FLR_z3 的优势来自绝对硬度门 \(r_0=1.8\),同一个门在 Virgo-server 集上丢掉 51/142(MOS1,34% 时间)与 54/142(MOS2,38%)个观测,主候选正在被重新询问;④ RT-15 —— 竖直剖面读法取决于曝光模型(平坦曝光下 2.filter 在 2 台相机都排最后);⑤ E021 —— R2 跨观测静息参考跑完,没有产生新领先者,但场参照门能拒绝 LH 0101;⑥ RT-17/R10 —— "复现 2.filter" 改为文件级。Honest limits folded in the same day: ① RT-16 F-01 — the advantage is mostly the repair of 2.filter's failed observations (on M31 MOS1, removing the 2 worst observations leaves FLR_z3 at only −0.79 pp and turns MS_z3.5_core into +0.33 pp, no significant difference); ② RT-18 — \(\sigma_{RC}\) is demoted, so ranking uses \(\sigma_R\) only with the dropped-observation count reported separately; ③ E022 — FLR_z3's edge comes from its absolute hardness gate \(r_0=1.8\), and the same gate drops 51/142 observations (MOS1, 34% of the time) and 54/142 (MOS2, 38%) on the Virgo-server set, so the main candidate is being re-asked; ④ RT-15 — the vertical-profile reading depends on the exposure model (under a flat exposure 2.filter is last on 2 cameras); ⑤ E021 — R2's cross-observation quiescent reference finished with no new leader, but a field-referenced gate does reject LH 0101; ⑥ RT-17/R10 — "reproducing 2.filter" is now file-level.
- 同时如实记录:竖直剖面的中位 \(\tau_b\) 改善"未检出"(检验功效 \(1\text{–}2\sigma\),RT-12 F-01);池化的每观测水平偏移上 FLR_z3 在 MOS2 上 −2.0 pp(95% [−3.3, −0.7])、Q_d0.05_n2 在 2 台相机都降,但该统计量是事后选择的,待 R7 预注册;Lockman Hole 的观测间项 14.6% / 23.3% 几乎全由 0022740101 一个观测贡献(RT-06,espfilt 锁到耀斑上)。Recorded honestly alongside: the median-\(\tau_b\) profile improvement is "not detected" (the test has \(1\text{–}2\sigma\) power, RT-12 F-01); on the pooled per-observation offset statistic FLR_z3 lowers MOS2 by −2.0 pp (95% [−3.3, −0.7]) and Q_d0.05_n2 lowers 2 cameras, but that statistic was chosen after the fact and awaits R7's pre-registration; the Lockman Hole between term, 14.6% / 23.3%, is carried almost entirely by the single observation 0022740101 (RT-06, espfilt locking onto a flare).
2026-10-14(第三次更新,D007–D012 刷新):
2026-10-14 (third edition, the D007-D012 refresh):
- PI 把下游成功判据定义为误差预算(C001,D007/D008):单观测看 \(\sigma_{\mathrm{tot}}\),多观测先看一致性;0.5–2 keV 拼接光变曲线的 \(s_{\mathrm{sys}}=17\text{–}25\%\)(2.filter),对 \(s_{\mathrm{stat}}\) 0.04–0.2% —— 系统误差约大 \(100\) 倍。The PI defined the downstream success criterion as the error budget (C001, D007/D008): \(\sigma_{\mathrm{tot}}\) for a single observation, consistency first over a set; the 0.5–2 keV concatenated-light-curve \(s_{\mathrm{sys}}\) is 17–25% (2.filter) against \(s_{\mathrm{stat}}\) 0.04–0.2% — the systematic is about \(100\times\) larger.
- 历史的 M31 2.1.filter 在多个观测上灾难性失败(3 个 MOS2、5 个 MOS1 完全不切;另一些只留 0.1–2.9 ks),且其"1.6%"被撤回:它在 0.2–10 keV 上选择,包含 0.5–2 keV 打分带 —— 选择与打分同一批事件给出 0.0%。The historical M31 2.1.filter fails catastrophically on several observations (no cut at all on 3 MOS2 and 5 MOS1; 0.1–2.9 ks left on others), and its "1.6%" is withdrawn: it selects on 0.2–10 keV, which contains the 0.5–2 keV score band — selecting and scoring on the same events gives 0.0%.
- C1(D010):每个观测一个角落项把观测间部分从 ~12% 降到 3–4%(CDFS);剩下的主导项是 2.filter 留下的 ~12% 观测内变化。C1 (D010): a per-observation corner term takes the between part from ~12% to 3–4% (CDFS); the dominant remainder is the ~12% within-observation variability left by 2.filter.
- C1b(D011):2.filter 内的不相交能段(FOV 2.5–8 keV)裁剪(B = 300 s,n = 1)把观测内项从 11.6–12.7% 减到 4.7–6.0%(100 s),代价 20–26% 活时间;\(\ge1000\) s 时 0–2.6%,达到 ~2% 目标。CDFS 角落修正后 \(s_{\mathrm{sys}}\):12.5% → 6.1%(MOS2)、12.0% → 5.2%(MOS1)。C1b (D011): a disjoint-band (FOV 2.5–8 keV) clip inside 2.filter (B = 300 s, n = 1) cuts the within term from 11.6–12.7% to 4.7–6.0% (100 s) for 20–26% of live time; at \(\ge1000\) s it is 0–2.6%, meeting the ~2% target. CDFS corner-corrected \(s_{\mathrm{sys}}\): 12.5% → 6.1% (MOS2), 12.0% → 5.2% (MOS1).
- P002 批准、冻结(1eb687b)并跑完 F1(D009):CDFS MOS2 \(b=1.015\pm0.030\) → TRACKS;其余三集 \(b\approx0.6\text{–}0.7\) → INTERMEDIATE。"Al 线是粒子监测器"未在一般意义上确立。F3 指向线测量里的 K/B 系统误差(T005)。P002 was approved, frozen (1eb687b) and F1 run (D009): CDFS MOS2 \(b=1.015\pm0.030\) → TRACKS; the other three sets give \(b\approx0.6\text{–}0.7\) → INTERMEDIATE. "The Al line is a particle monitor" is not established in general. F3 points to a K/B systematic in the line measurement (T005).
- 100 s cell 上约 5% 的快速"白"残差是新的未解问题:裁剪后仍在、不跟随角落(观测内角落回归只移走 \(\le0.7\) 点)、会从谱中平均掉;其来源未测(事件聚簇 Fano \(\approx1.17\),或阈值下的快速软质子闪烁)。The ~5% fast "white" residual at 100 s cells is a new open question: it survives the clip, does not follow the corner (a within-observation corner regression removes \(\le0.7\) points), and averages out of spectra; its origin is untested (event clustering, Fano \(\approx1.17\), or fast soft-proton flicker below the clip).
- 下一步(PI,D011/D012):冻结已完成(H,B = 300 s,n = 1;cell 尺寸 1000 s;commit abc5e602),下一次是一次 Lockman Hole 还原,同时检验 P002 F2 与冻结滤波器;C2 在 P002 之后。Lockman Hole"后面再派",不预设日期。Next (PI, D011/D012): the freeze is done (H, B = 300 s, n = 1; cell size 1000 s; commit abc5e602); the next step is one Lockman Hole reduction testing both P002 F2 and the frozen filter; C2 after P002. The Lockman Hole is dispatched later; no date invented.
- 新页面:"误差预算与 Al 线"(budget.html),从零讲 C001 与 P002,含撤回的 1.6% 一节;两张新图:P002 F1 四集散点、C1b cell 尺寸依赖。New page: "Error budget and the Al line" (budget.html), teaching C001 and P002 from zero, including the withdrawn 1.6% claim; two new figures: the P002 F1 four-set scatter and the C1b cell-size dependence.
2026-10-13(第二次更新,D006 刷新):P001 关闭,主问题否定;CDFS 盲测完成(E003);角落按数据集回答;探索性角落–Al 张力(后由 P002 接手)。
2026-10-13 (second edition, the D006 refresh): P001 closed negative; the CDFS blind run complete (E003); the corner answered per set; the exploratory corner-vs-Al tension (later taken over by P002).
2026-10-13(第一版):本手册随 ParetoGTICal 迁移入 DXC 后建立,覆盖 D001–D005。
2026-10-13 (first edition): this handbook was built after ParetoGTICal migrated into DXC, covering D001–D005.
数据截至Data as of
2026-10-19T10:38Z(所读最新来源:cognition-os/04_DECISION_LOG.md D079(2026-10-19T10:38Z);cognition-os/00_AI_BRIEFING.md 状态行(2026-10-19T07:39Z);cognition-os/RESEARCH_PLAN.md(R37–R42 行);experiments/E024_p006_heldout_verdict.md 及其修订(R031–R038);prereg/P007_rule_draft.md(草稿 1);cognition-os/REDTEAM_QUEUE.md 与 06_AGENT_LOG.md 至 2026-10-19T07:39Z)。
2026-10-19T10:38Z (newest sources read: cognition-os/04_DECISION_LOG.md D079 (2026-10-19T10:38Z); the cognition-os/00_AI_BRIEFING.md status line (2026-10-19T07:39Z); cognition-os/RESEARCH_PLAN.md (rows R37–R42); experiments/E024_p006_heldout_verdict.md and its amendments (R031–R038); prereg/P007_rule_draft.md (draft 1); cognition-os/REDTEAM_QUEUE.md and 06_AGENT_LOG.md to 2026-10-19T07:39Z).