前沿策略对比(GTI 政策的图文展示)Frontier policies (the GTI policies, shown)
评审更正(2026-10-16,Claude):(1)本页尚未写入 R13 的结果:给 MS_z3.5_core 加上同视场剔除门后的 XJ.MS,M31 两台相机相对 2.filter 均显著改善(MOS1 −1.53 [−2.31, −0.73],MOS2 −3.84),在 Virgo-server 上只丢 8 个观测(FLR_z3 丢 51–54 个),见 MS_z3.5_core 页 与 E022。(2)第 6 节哑铃图中 MOS2 一栏的点相对观测标签错位一行,读数请以表格为准。(3)第 7 节剖面图的折线跨过了被遮挡的盘区(z 约 −30′ 到 +20′),那一段没有数据。三处均待作者修正。
Reviewer correction (2026-10-16, Claude): (1) the R13 result is not on this page yet: XJ.MS (MS_z3.5_core with the field rejection gate) beats 2.filter on M31 in both cameras (MOS1 −1.53 [−2.31, −0.73], MOS2 −3.84) and drops only 8 Virgo-server observations (FLR_z3 drops 51–54); see the MS_z3.5_core page and E022. (2) In the section-6 dumbbell figure the MOS2 points are offset by one row from the observation labels; use the table. (3) The section-7 profile lines bridge the masked disk gap (z ≈ −30′ to +20′), where there are no data. All three await the writer.
PI 2026-10-16 的要求:"我要看到各种 light curve,我要看到观测一致性的改进,vertical profile 的改进……convince 我现在的策略确实是做出了改进。然后某个策略在 pareto 前沿中位于什么位置。要画出来某个观测的以及假设了 stack 了全部观测的 pareto 前沿。" 本页按这个要求展示十个政策:光变曲线与保留时间条、单观测与叠加观测的帕累托前沿、观测间一致性的配对比较、M31 竖直剖面的诚实读法,以及"某政策在前沿哪里"的下拉表(选一个政策,两张前沿图换成它的高亮版)。每个数字都给来源;没有确立的结果按原文标注。2026-10-16 更新:折入 RT-16(优势是修好 2.filter 失效的观测)、RT-18(σ_RC 降级,只用 σ_R 排名)、RT-15(剖面读法取决于曝光模型)、E022(FLR_z3 的绝对硬度门,主候选被重新询问)、E021(R2 跨观测参考跑完,无新领先者)、RT-17/R10(复现改为文件级),并新增 merged:sol.MS_z3.5_core 一行。
The PI's request of 2026-10-16: "show me the light curves, the improvement in consistency between observations, the vertical-profile improvement… convince me the current policies really improve. Then where each policy sits in the Pareto front. Draw the front for one observation and for all observations stacked." This page shows ten policies that way: light curves with kept-time strips, per-observation and stacked Pareto fronts, paired consistency comparisons, the honest reading of the M31 vertical profile, and a dropdown for "where does policy X sit" (pick one policy and both front figures switch to its highlighted version). Every number carries its source; what is not established is labelled as such. Updated 2026-10-16: folded in RT-16 (the advantage is the repair of 2.filter's failed observations), RT-18 (σ_RC demoted; rank on σ_R only), RT-15 (the profile reading depends on the exposure model), E022 (FLR_z3's absolute hardness gate; the main candidate is being re-asked), E021 (R2's cross-observation reference finished, no new leader) and RT-17/R10 (reproduction is now file-level), and added the merged:sol.MS_z3.5_core row.
- 一段话回答The one-paragraph answer
- 展示的政策The policies on show
- 光变曲线与保留时间Light curves and kept time
- 单观测帕累托前沿Pareto front for one observation
- 叠加观测帕累托前沿(马赛克)Pareto front for all observations stacked (the mosaic)
- 观测间一致性Consistency between observations
- 竖直剖面(M31 短轴)The vertical profile (M31 minor axis)
- 还没有展示的What is not yet shown
1. 一段话回答1. The one-paragraph answer
答:在 31 个 M31 halo 观测、2 台 MOS 相机上,与归档 2.filter 相比,前沿政策确实降低了"每观测总不确定度 σ_o":以 gen2:hermes.FLR_z3 为例,25 个测试观测(没有任何设计者看过)的叠加 mosaic 期望风险 σ_R 从 5.15% 降到 3.81%(MOS1,配对差 −1.34 pp,自举离散 [−1.98, −0.65])与从 5.84% 降到 3.93%(MOS2,−1.92 [−2.58, −1.18]);代价是保留 0.85–0.87 的活时间。3 个政策(FLR_z3、MS_z3.5_core、RT3_h2.5_l1)在 4 个集 × 2 台相机共 8 种组合上都优于 2.filter(R9,离散均不含 0)。但这个改进主要是修好 2.filter 失效的观测(RT-16 F-01):在 M31 MOS1 上,去掉 2 个最差的 2.filter 观测后 FLR_z3 的增益从 −1.77 降到 −0.79 pp,MS_z3.5_core 变成 +0.33 pp(持平)。观测间剖面水平偏移(RT-12 F-02 的池化统计)在 MOS2 上 FLR_z3 降低 −2.0 pp(95% [−3.3, −0.7]),Q_d0.05_n2 在两台相机都降(MOS1 −3.7 [−5.9, −0.1],MOS2 −2.3 [−3.3, −0.9])——但该统计量是事后选择的,待预注册(R7)。竖直剖面的中位 τ_b 没有显著改善:观测到的 −0.5 到 −0.8 pp 落在 0 与预测(−0.8…−1.9 pp)的 1σ 之内,检验功效只有 1–2σ(RT-12 F-01)。而"覆盖代价"这一分数本身已经不可靠:RT-18 发现 σ_RC 给每个被丢指向收同一个中位 V_miss,而实际被丢指向的插值残差大一个量级,且 V_miss 混入了 2.filter 自己的失效;结论(GATE 掉到 2.filter 之后)随 V_miss 估计量而翻转。因此现在只用 σ_R 排名,同时显式报告每个政策丢掉了哪些观测和什么类型的目标(E022/R13),直到有一个干净参考的覆盖价格。主候选正在被重新询问:FLR_z3 的 M31/LH 优势来自它的绝对硬度门(r0 = 1.8),而同一个门在 Virgo-server 集上丢掉 51/142(MOS1,2.filter 时间的 34%)与 54/142(MOS2,38%)个观测——亮源或硬目标场的天空比 1.8 更硬(E022)。
Answer: over the 31 M31-halo observations and 2 MOS cameras the frontier policies do lower the per-observation total uncertainty σ_o relative to the archived 2.filter: taking gen2:hermes.FLR_z3, on the 25 test observations (no designer looked at them) the stacked mosaic expected risk σ_R falls from 5.15% to 3.81% (MOS1; paired difference −1.34 pp, bootstrap spread [−1.98, −0.65]) and from 5.84% to 3.93% (MOS2; −1.92 [−2.58, −1.18]), for 0.85–0.87 of the live time. 3 policies (FLR_z3, MS_z3.5_core, RT3_h2.5_l1) beat 2.filter in all 8 set × camera cases (4 sets × 2 cameras; R9; every spread excludes 0). But the win is mostly the repair of 2.filter's failed observations (RT-16 F-01): on M31 MOS1, removing the 2 worst 2.filter observations takes FLR_z3's gain from −1.77 to −0.79 pp and turns MS_z3.5_core into +0.33 pp (no significant difference). On the pooled profile-level offset statistic (RT-12 F-02), FLR_z3 lowers MOS2 by −2.0 pp (95% [−3.3, −0.7]) and Q_d0.05_n2 lowers both cameras (MOS1 −3.7 [−5.9, −0.1], MOS2 −2.3 [−3.3, −0.9]) — but that statistic was chosen after the fact and awaits pre-registration (R7). The profile median τ_b shows no significant improvement: the observed −0.5 to −0.8 pp lies within 1σ of both 0 and the prediction (−0.8…−1.9 pp); the test has only 1–2σ power (RT-12 F-01). And the coverage-cost score itself is not reliable: RT-18 found that σ_RC charges every dropped pointing the same median V_miss, while the interpolation residuals of the pointings actually dropped are an order of magnitude larger, and V_miss mixes in 2.filter's own failures; the conclusion (GATE falling below 2.filter) flips with the V_miss estimator. So the ranking now uses σ_R only, with an explicit report of which observations and which target types each policy drops (E022/R13), until a clean-reference coverage price exists. The main candidate is being re-asked: FLR_z3's M31/LH edge comes from its absolute hardness gate (r0 = 1.8), and the same gate drops 51/142 observations (MOS1, 34% of 2.filter's time) and 54/142 (MOS2, 38%) on the Virgo-server set — the sky of bright or hard targets is harder than 1.8 (E022).
results/c001_risk_v31/risk.json (σ_R / σ_R_net / σ_RC 与配对差)(σ_R / σ_R_net / σ_RC and paired differences); results/redteam/rt12-profile/hermes/check7c_pooled_fixed.out, check1b_power.out (剖面统计)(the profile statistics); cognition-os/experiments/E019_criterion_v3_random_effects.md (v3.1 定义、R9、RT-16、RT-18)(the v3.1 definitions, R9, RT-16, RT-18); E022_flr_hardness_gate.md (FLR_z3 的硬度门)(FLR_z3's hardness gate); RESEARCH_PLAN.md (R13 与待 PI 决定表)(R13 and the pending-PI-decisions table).2. 展示的政策(十个)2. The policies on show (ten)
本页每张图都用同一套颜色:2.filter 永远黑色;用角落的政策(Q_d0.05_n2)画空心点。T/2.filter 是全部 31 个 M31 halo 观测叠加后的保留活时间比(MOS1 / MOS2)。所有政策只用光变曲线(PI 规则 D013),不依赖 2.filter 构建。2026-10-16 新增 merged:sol.MS_z3.5_core:R9 判定它是 3 个跨集稳健政策里的最佳折衷(在每个集都排前 7–17,保留 0.74–0.88 的时间),且 E022 发现它每个集最多只丢 1 个观测——这正是 σ_RC 不可靠后(RT-18)必须显式报告的那个量。它的详细说明在 policy_ms.html。
Every figure on this page uses one colour set: 2.filter is always black; the corner-using policy (Q_d0.05_n2) is drawn hollow. T/2.filter is the stacked kept-live-time ratio over all 31 M31-halo observations (MOS1 / MOS2). All policies use light curves only (the PI's rule, D013) and are built independently of 2.filter. New on 2026-10-16: merged:sol.MS_z3.5_core — R9 judged it the best compromise among the 3 cross-set robust policies (top 7–17 everywhere, keeping 0.74–0.88 of the time), and E022 found it drops at most 1 observation per set, which is exactly the quantity that must now be reported explicitly once σ_RC is unreliable (RT-18). Its full walk-through is on policy_ms.html.
| 政策Policy | 一句话思路The idea in one line | 角落Corner | T/2.filter (M1 / M2) | 来源Source |
|---|---|---|---|---|
2.filter |
归档的 espfilt 筛选(及格线),不是我们的政策。The archived espfilt screening (the passing line), not one of ours. | 否no | 1.00 / 1.00 | 归档 GTIarchived GTI |
gen2:hermes.FLR_z3 |
以本观测"最低四分位块"为静息基线的率偏移检验(200 s 块,z > 3 截断),外加绝对硬度门(静息 h/u 与 r0 = 1.8 比较;E022)。A rate-excursion test against the observation's own lowest-quartile-block quiescent floor (200 s blocks, cut at z > 3), plus an absolute hardness gate (the quiescent h/u against r0 = 1.8; E022). | 否no | 0.86 / 0.85 | E015(gen2);E022(硬度门)E015 (gen2); E022 (the hardness gate) |
gen2:hermes.JFR_z3 |
同一规则但用 MOS1+MOS2 联合计数(两台相机看到同一个耀斑)。The same rule on joint MOS1+MOS2 counts (both cameras see the same flare). | 否no | 0.87 / 0.82 | E015(gen2)E015 (gen2) |
merged:hermes.RT3_h2.5_l1 |
200 s 块上的滞后游程检验:z>2.5 进入耀斑态、z<1 退出。A hysteresis run test on 200 s blocks: enter the flare state at z>2.5, leave at z<1. | 否no | 0.92 / 0.92 | E012(gen1)E012 (gen1) |
merged:sonnet.MG_CP_k0.5 |
变点分段找静息段,再在截断两侧加"与耀斑时长成比例"的防护边距。Change-point segmentation finds the quiet segment, then guard margins proportional to each flare's duration are added around the cuts. | 否no | 0.73 / 0.72 | E012(gen1)E012 (gen1) |
merged:sol.MS_z3.5_core |
迟滞区间(300 s 证据,z = 3.5)标出连续正偏段并整段删除,只保留"核心"静息区;每个集最多丢 1 个观测(E022)。Hysteretic intervals on 300 s evidence (z = 3.5) mark coherent positive runs and drop them whole, keeping only the "core" quiet stretches; at most 1 observation dropped per set (E022). | 否no | 0.88 / 0.88 | E012(gen1);R9;E022;policy_ms.htmlE012 (gen1); R9; E022; policy_ms.html |
gen2:luna.GATE_a0p001 |
观测级门:整观测的 h/u 硬度显著高于静息比值 1.8 时整个观测不保留。An observation-level gate: if the whole observation's h/u hardness is significantly above the quiescent ratio 1.8, keep nothing. | 否no | 0.43 / 0.47 | E015(gen2)E015 (gen2) |
EH_B1000_n2 |
先复现 2.filter(E_k2.5),再在其内做 1000 s 块裁剪(E007 的两阶段家族)。Reproduce 2.filter first (E_k2.5), then a 1000 s block clip inside it (the two-stage family of E007). | 否no | 0.97 / 0.93 | E007E007 |
Q_d0.05_n2 |
角落比值政策:以冻结的 κ·q 预测静息硬率,保留 1000 s 块中低于预测 +2σ 的(D014)。A corner-ratio policy: predict the quiescent hard rate from the frozen κ·q and keep 1000 s blocks below prediction +2σ (D014). | 是YES | 0.88 / 0.93 | D014;RT-14 后降为诊断D014; demoted to a diagnostic after RT-14 |
none |
不删任何时间(参照)。No cut at all (the reference). | 否no | 1.41 / 1.35 | — |
results/c001_risk_v31/risk.json (T_vs_2filter,all 31)(T_vs_2filter, all 31); 政策定义policy definitions: results/c001_policy_search_gen2/merged/policies_gen2.py 与各执行器模块and the executor modules; results/c001_policy_search/merged/policies_merged.py; cognition-os/experiments/E007_c001_frontier_scan.md, E012_policy_search_cases.md, E015_policy_search_gen2.md; 04_DECISION_LOG.md D013–D015 与 2026-10-16 D016(Q 降级)and the 2026-10-16 D016 (Q demoted).3. 光变曲线与保留时间3. Light curves and kept time
每个基本案例(D015 的角色划分)一张图:上排是 300 s bin 的 0.5–2 keV(30″ 源掩蔽,打分带)与 2.5–8 keV FOV(选择带)率,MOS1 与 MOS2;下排是各政策每个 300 s bin 的保留比例(色条与第 2 节同色)。要看的是:2.filter 留下了什么(红/蓝曲线在黑条之上仍升高的时段),以及领先政策是否把它删掉。每张图的说明里给出该观测、该相机的保留时间 K 与每观测总不确定度 σ_o(来源列)。
One figure per basic case (the roles fixed by D015): the top row is the 0.5–2 keV (30″ source-masked, the score band) and 2.5–8 keV FOV (the selection band) rates in 300 s bins, MOS1 and MOS2; the bottom row is each policy's kept fraction per 300 s bin (same colours as section 2). What to look for: what 2.filter leaves behind (time where the curves stay high above the black strip) and whether the leaders cut it. Each caption quotes the kept time K and the per-observation total uncertainty σ_o for that observation and camera (source column).
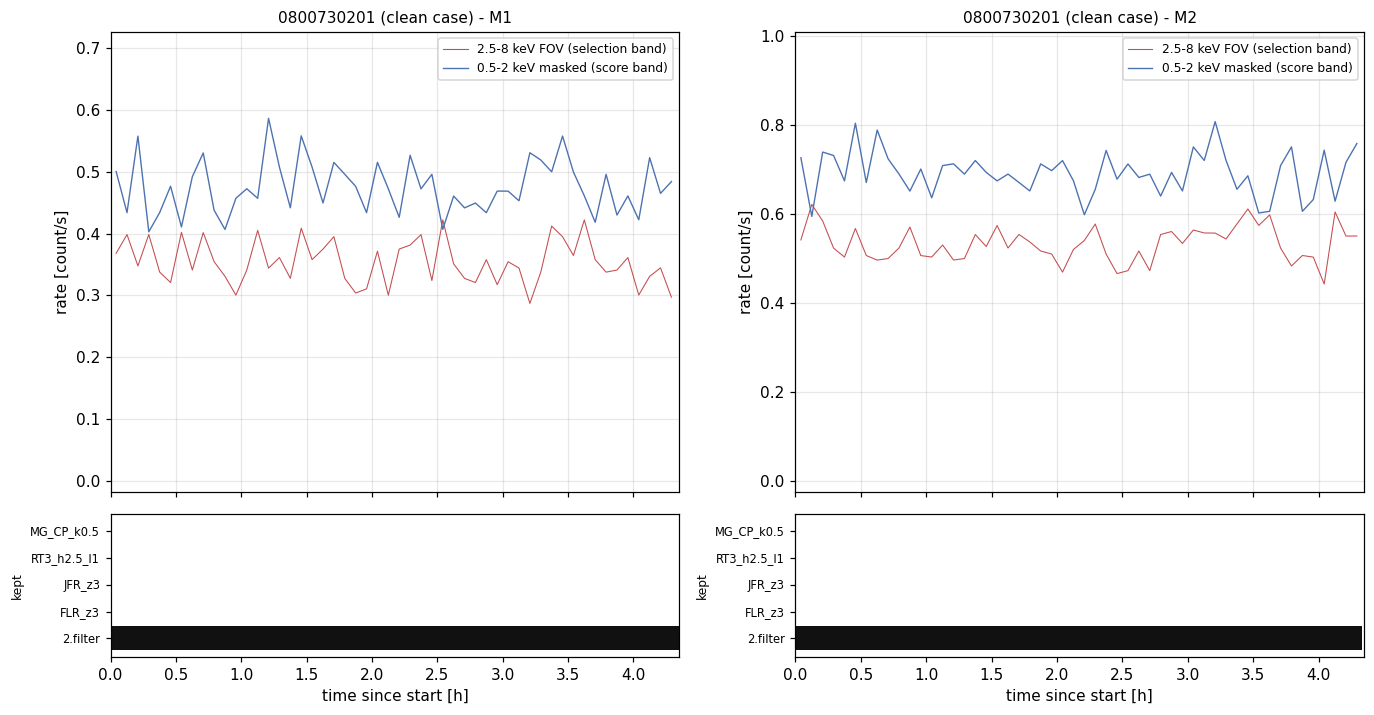
results/c001_frontier/cache/0800730201_{M1,M2}.npz (光变曲线,经 c001_frontier_scan._load)(light curves via c001_frontier_scan._load); results/c001_risk_v31/per_obs.json (K 与 σ_o)(K and σ_o).
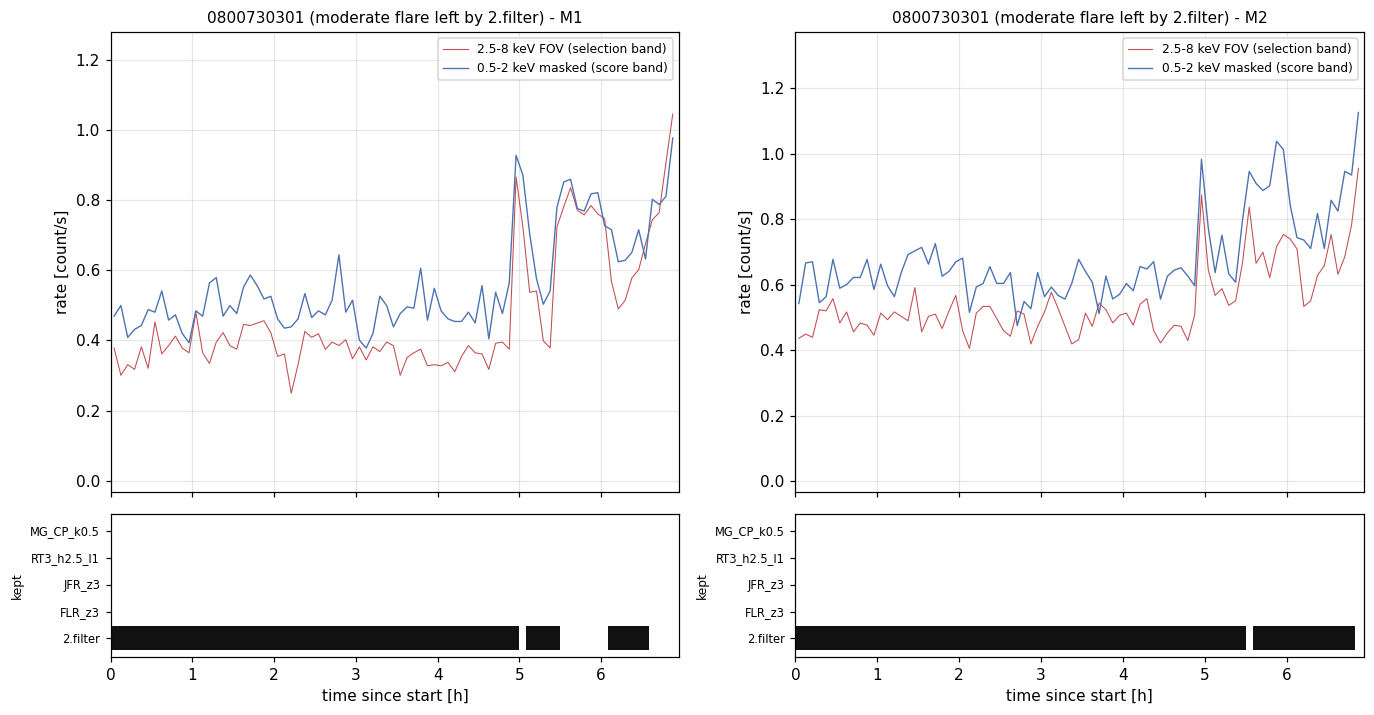
results/c001_frontier/cache/0800730301_{M1,M2}.npz; results/c001_risk_v31/per_obs.json; 隆起特征bump characterisation: cognition-os/experiments/E012_policy_search_cases.md (RT-03/RT-10 节)(the RT-03/RT-10 sections).
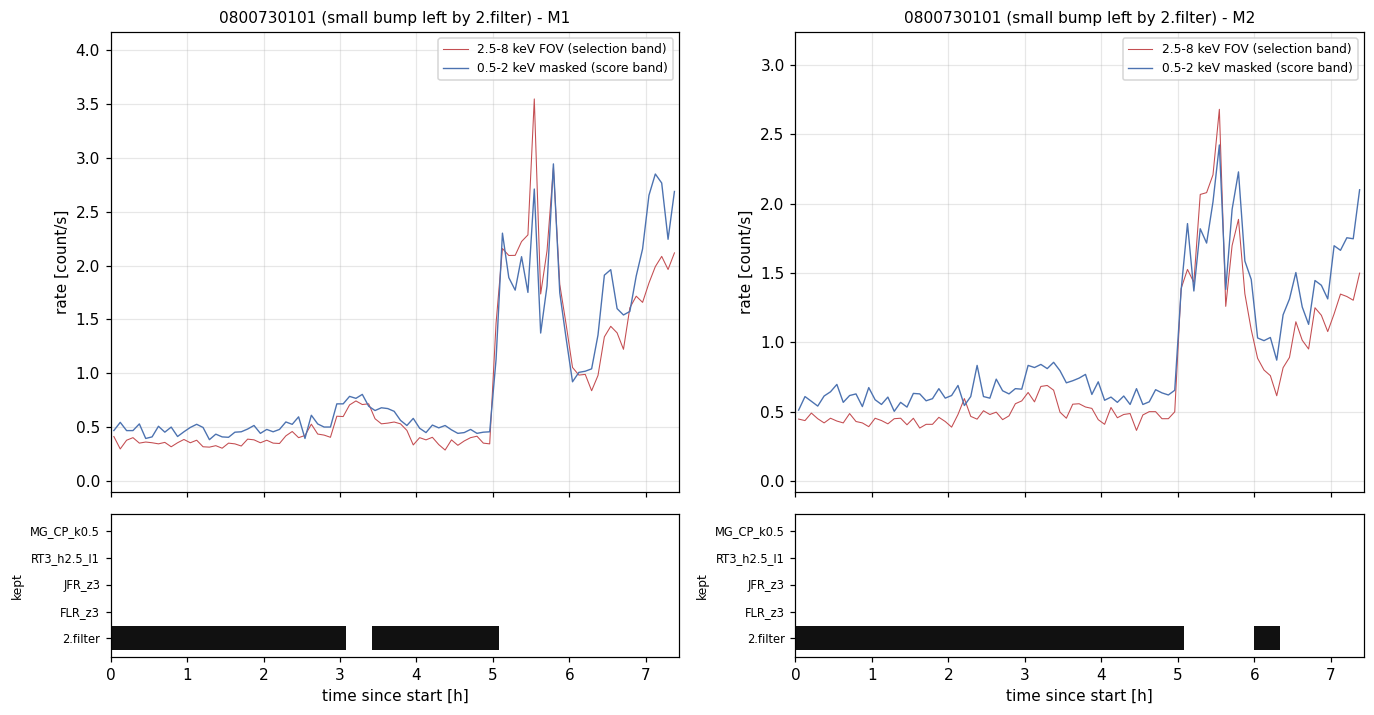
results/c001_frontier/cache/0800730101_{M1,M2}.npz; results/c001_risk_v31/per_obs.json; 04_DECISION_LOG.md D015 (案例角色)(the case roles).
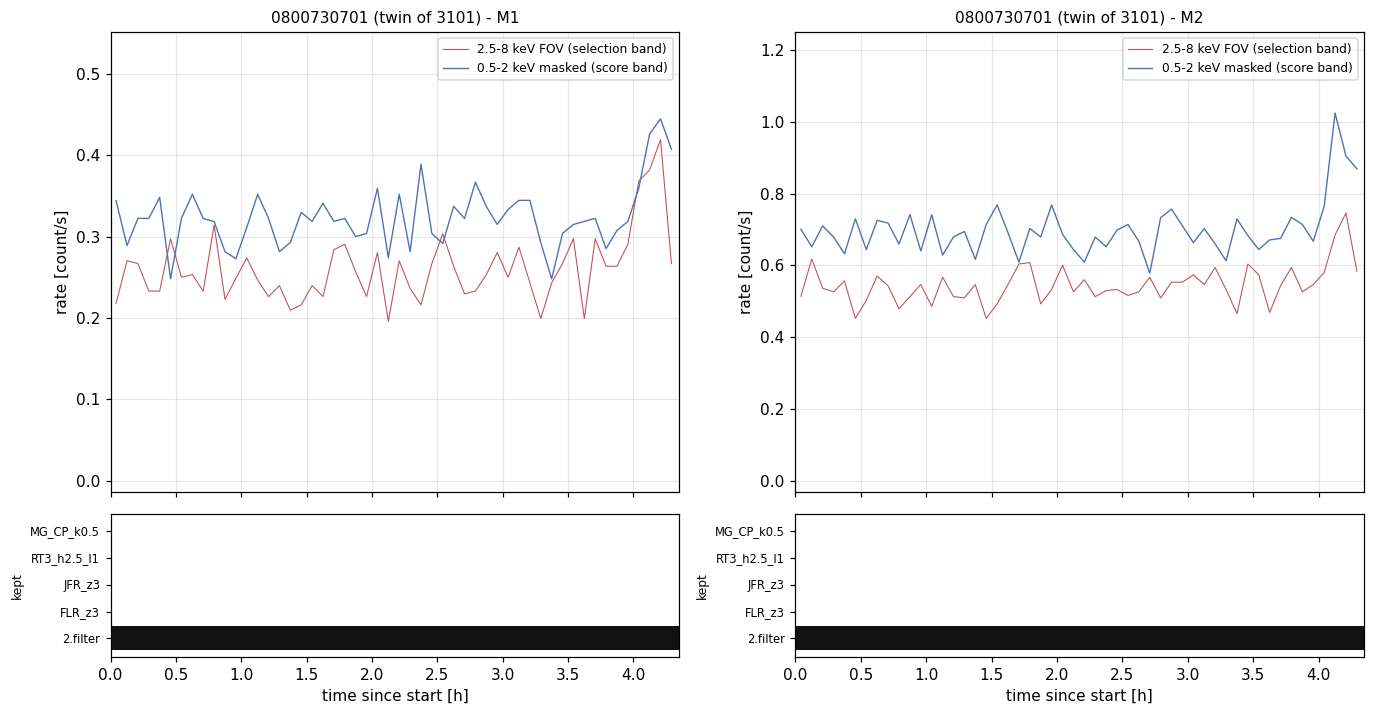
results/c001_frontier/cache/0800730701_{M1,M2}.npz; results/c001_risk_v31/per_obs.json.
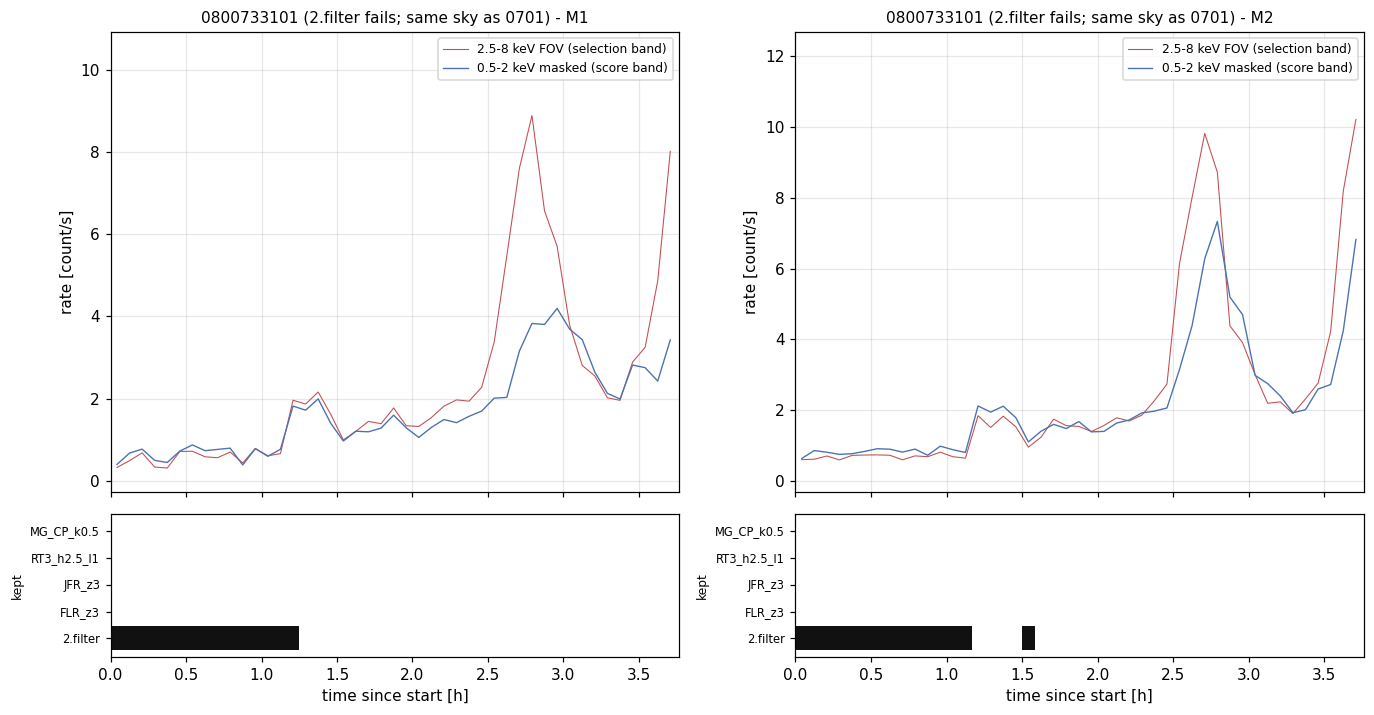
results/c001_frontier/cache/0800733101_{M1,M2}.npz; results/c001_risk_v31/per_obs.json; 级差level gap: cognition-os/experiments/E014_m31_mosaic_test.md (RT-09 修正)(the RT-09 correction); RESEARCH_PLAN.md R2.
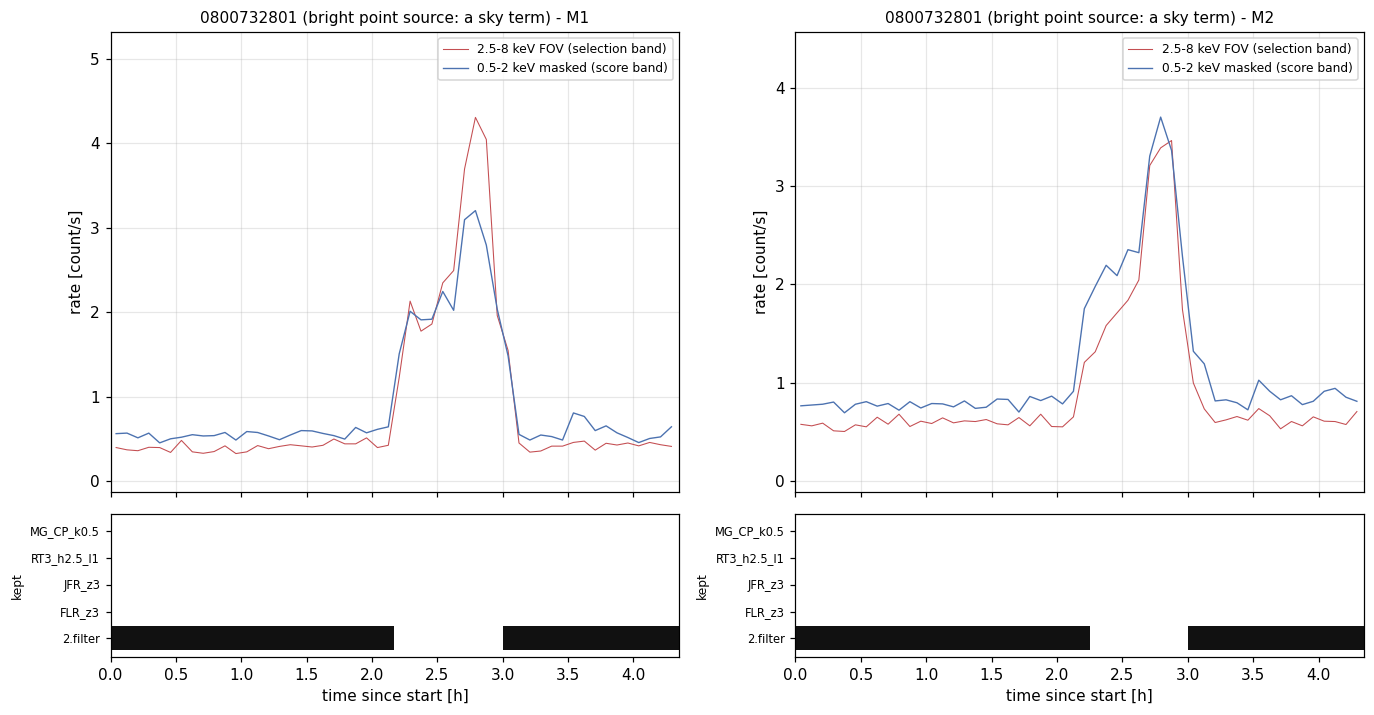
results/c001_frontier/cache/0800732801_{M1,M2}.npz; results/c001_risk_v31/per_obs.json; 04_DECISION_LOG.md D015; 掩蔽泄漏mask leakage: 03_TRUST_TABLE.md (RT-03 F4)(RT-03 F4).
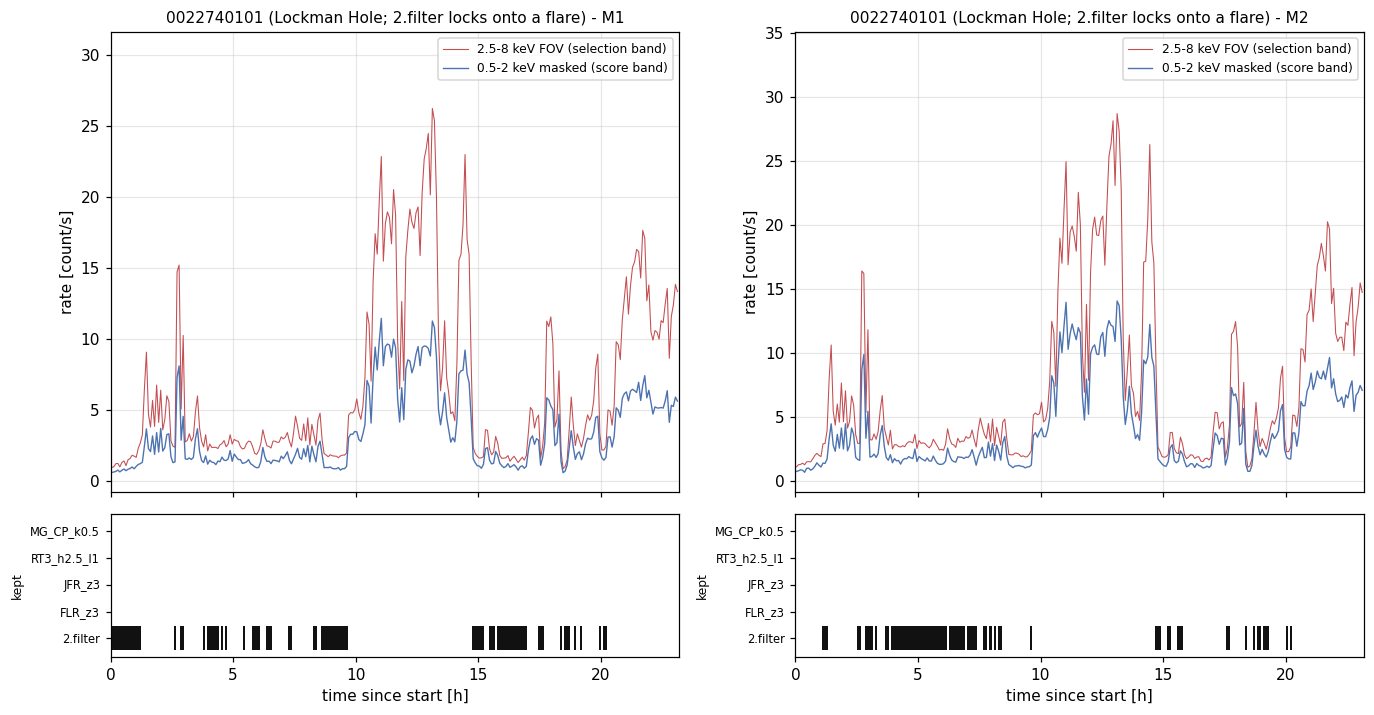
results/c001_frontier/cache/0022740101_{M1,M2}.npz (LH 缓存,R1 重建,与 RT-06 相同)(the LH caches, rebuilt in R1, identical to RT-06's); results/redteam/RT-06/hermes/step4_epoch_pointing.json, step11.log; results/c001_risk_v31/per_obs.json; cognition-os/experiments/E008_lockman_frozen_tests.md (RT-06 节)(the RT-06 section).
4. 单次观测的帕累托前沿4. Pareto front for one observation
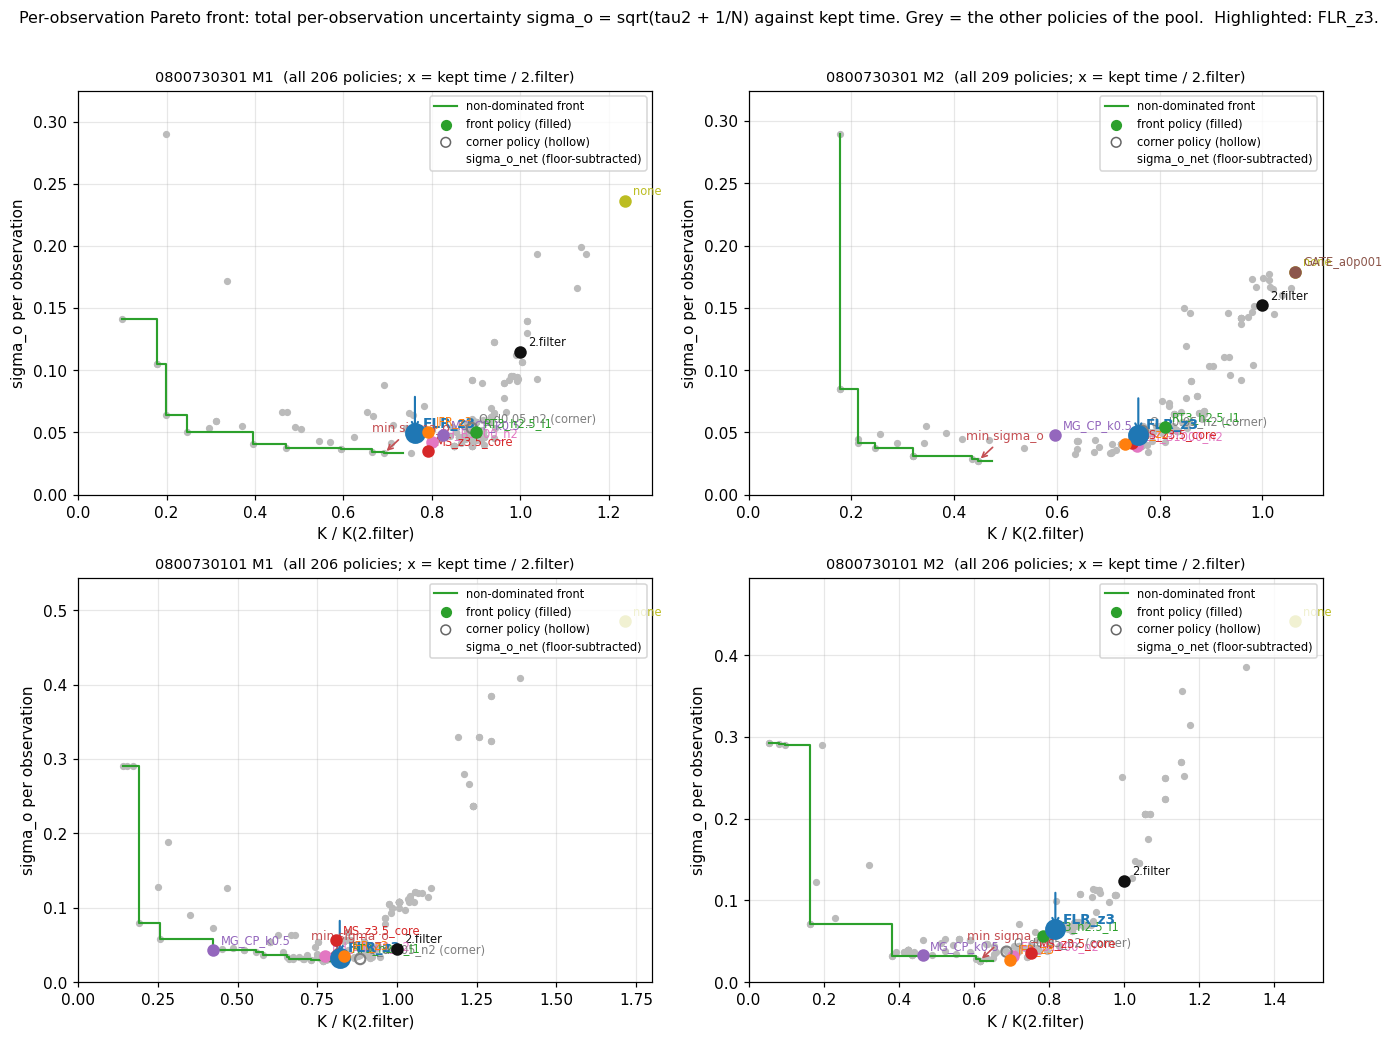
两次观测 × 两台相机:横轴是保留活时间 K / K(2.filter),纵轴是每观测总不确定度 σ_o = √(τ² + 1/N)(v3.1 收据 per_obs.json)。灰色小点是池里其余政策;绿色阶梯是非支配前沿;九个展示政策用第 2 节的彩色圆点(用角落的 Q 为空心);每个彩色政策还画一个同色"×"表示扣掉信息地板后的 σ_o_net = √(τ²_net + 1/N);箭头指向 σ_o 最小的点。
Two observations × two cameras: x is the kept live time K / K(2.filter), y is the per-observation total uncertainty σ_o = √(τ² + 1/N) (the v3.1 receipt per_obs.json). Small grey dots are the other policies of the pool; the green staircase is the non-dominated front; the nine shown policies are the coloured circles of section 2 (Q, the corner user, hollow); each coloured policy also carries a same-colour "×" for the floor-subtracted σ_o_net = √(τ²_net + 1/N); the arrow marks the minimum-σ_o point.
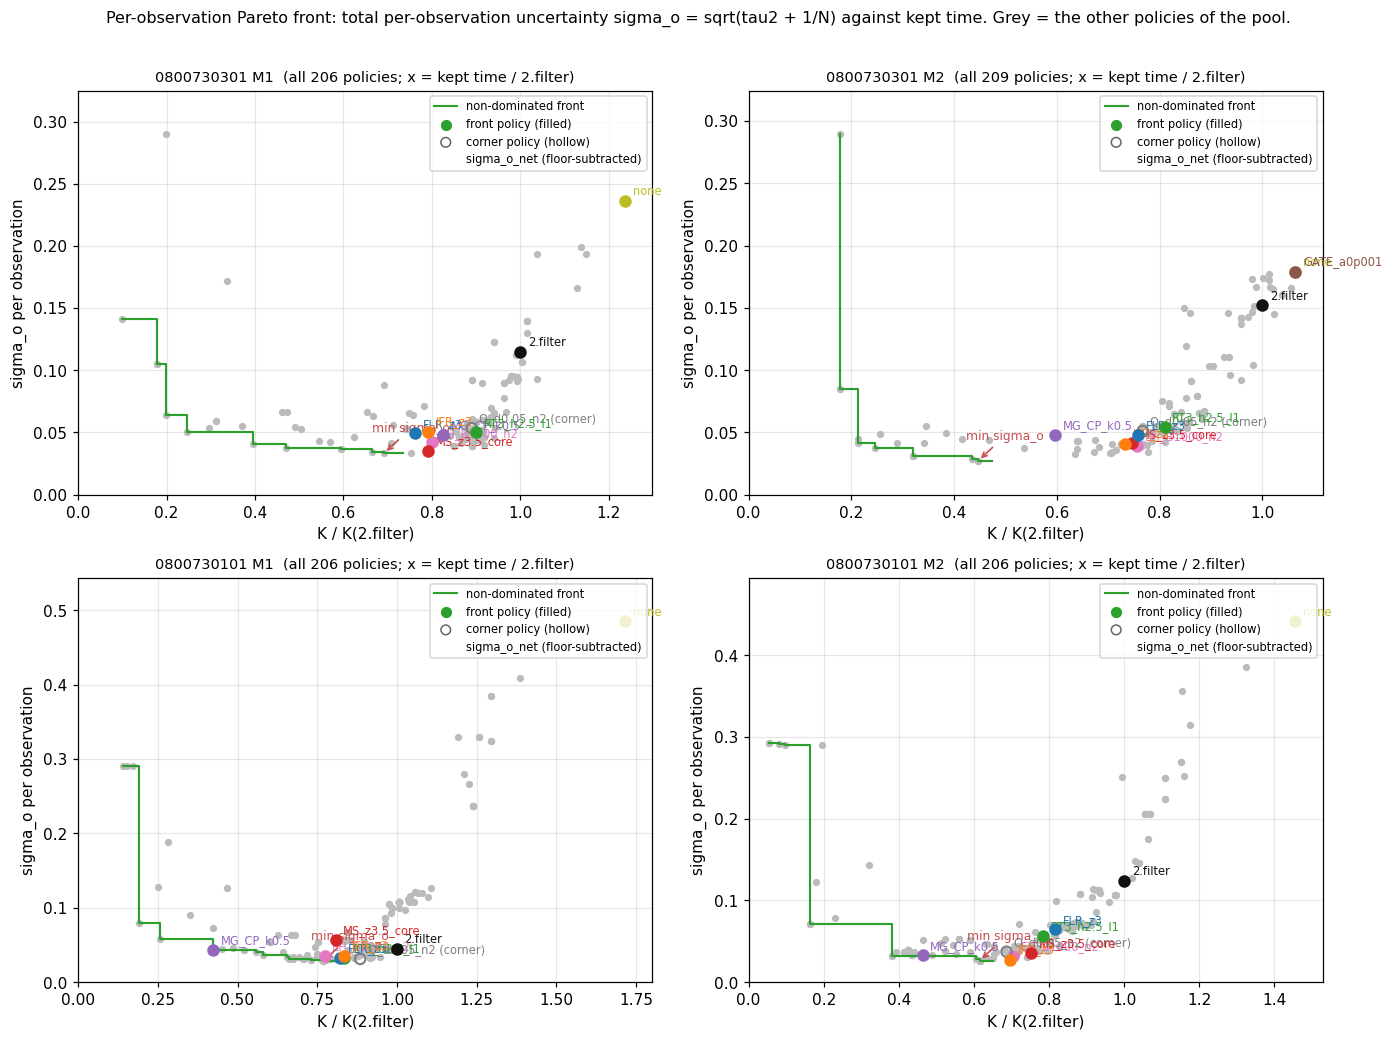
results/c001_risk_v31/per_obs.json (τ²_0.5、τ²_floor、τ²_net、K、N)(τ²_0.5, τ²_floor, τ²_net, K, N); cognition-os/experiments/E019_criterion_v3_random_effects.md (σ_o 定义、RT-08 F01 地板)(the σ_o definition and the RT-08 F01 floor).
5. 叠加全部观测的帕累托前沿(马赛克)5. Pareto front for all observations stacked (the mosaic)
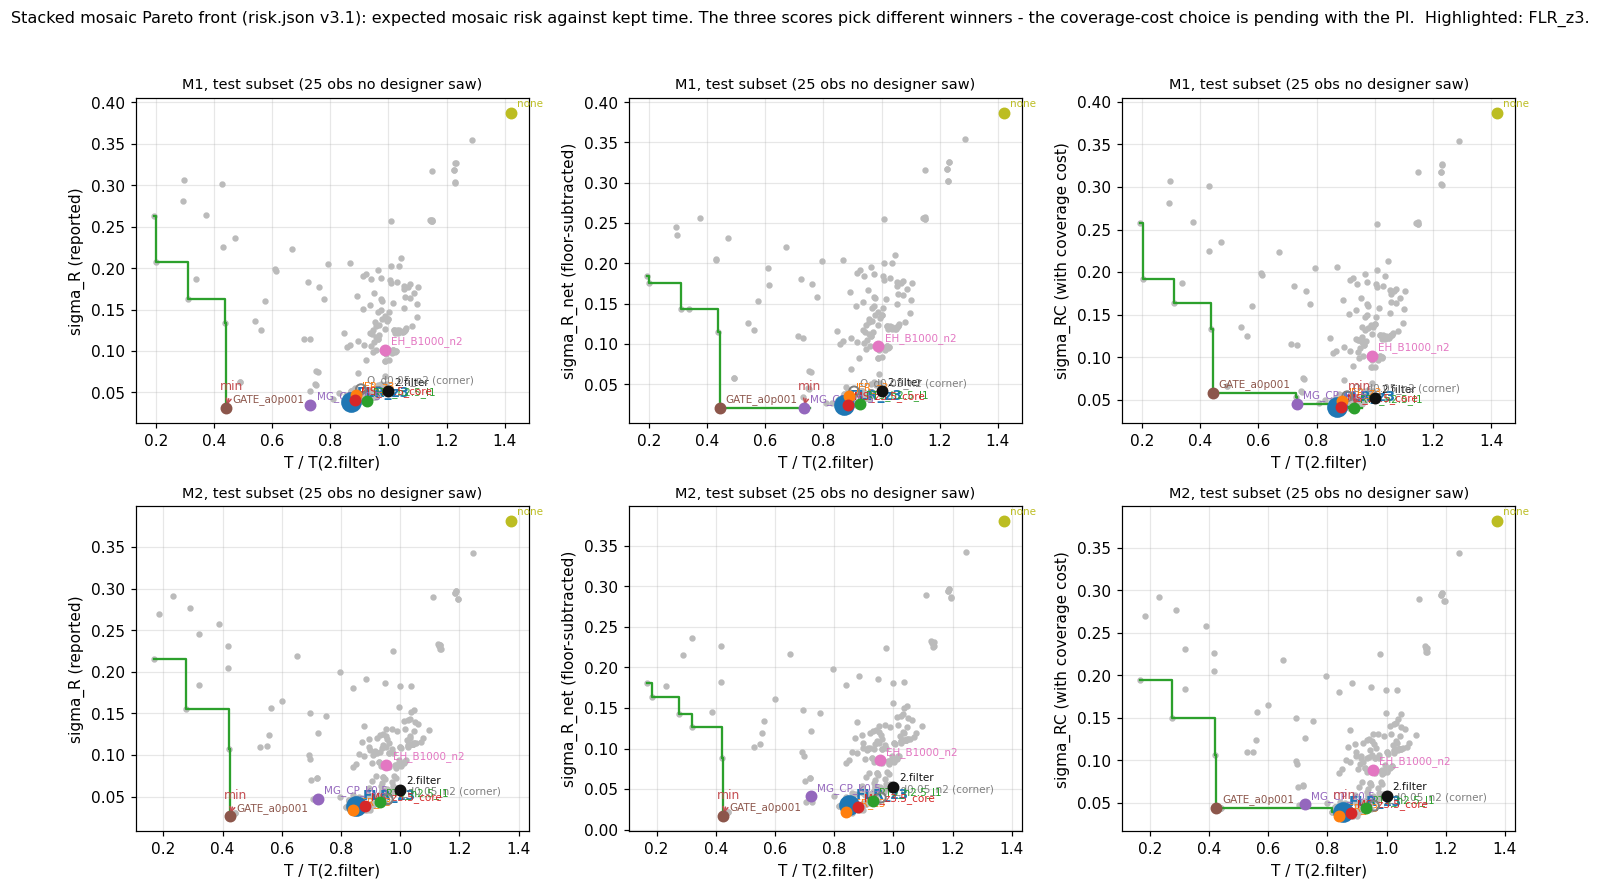
把 31 个 M31 halo 观测当作一个拼接观测(E019 的 σ_R 判据):横轴是 T/2.filter(叠加保留活时间比),纵轴是马赛克期望风险。三列分别是三个分数:σ_R(报告的)、σ_R_net(扣掉信息地板)、σ_RC(加上覆盖代价 V_miss)。但 σ_RC 已在 2026-10-16 被 RT-18 降级:它给每个被丢指向收同一个中位 V_miss,而实际被丢指向的插值残差大一个量级(FLR_z3 丢的 1701/1801/3101 均值 0.044,中位只有 0.0045),且 V_miss 混入了 2.filter 自己的失效;换一个估计量,结论就翻转。所以σ_R 是唯一用于排名的分数,σ_RC 一列仅作为"曾经怎么算"的记录保留,被丢观测数另列报告(E022/R13)。主图用 test 子集(25 个观测,任何设计者都没看过);all 31 的数字在下拉表里给出。灰色小点是池里其余政策;绿色阶梯是前沿;箭头指向每列的最小值。
Treating the 31 M31-halo observations as one concatenated observation (E019's σ_R criterion): x is T/2.filter (the stacked kept-live-time ratio), y is the mosaic expected risk. The three columns are the three scores: σ_R (as reported), σ_R_net (floor-subtracted) and σ_RC (with the coverage cost V_miss). But σ_RC was demoted on 2026-10-16 by RT-18: it charges every dropped pointing the same median V_miss, while the interpolation residuals of the pointings actually dropped are an order of magnitude larger (FLR_z3's dropped 1701/1801/3101 average 0.044 against a median of 0.0045), and V_miss mixes in 2.filter's own failures; a different estimator flips the conclusion. So σ_R is the only score used for ranking; the σ_RC column is kept only as a record of how it was once computed, and the number of dropped observations is reported separately (E022/R13). The main figure uses the test subset (25 observations no designer looked at); the all-31 numbers are in the dropdown table below. Small grey dots are the other policies; the green staircase is the front; the arrow marks each column's minimum.
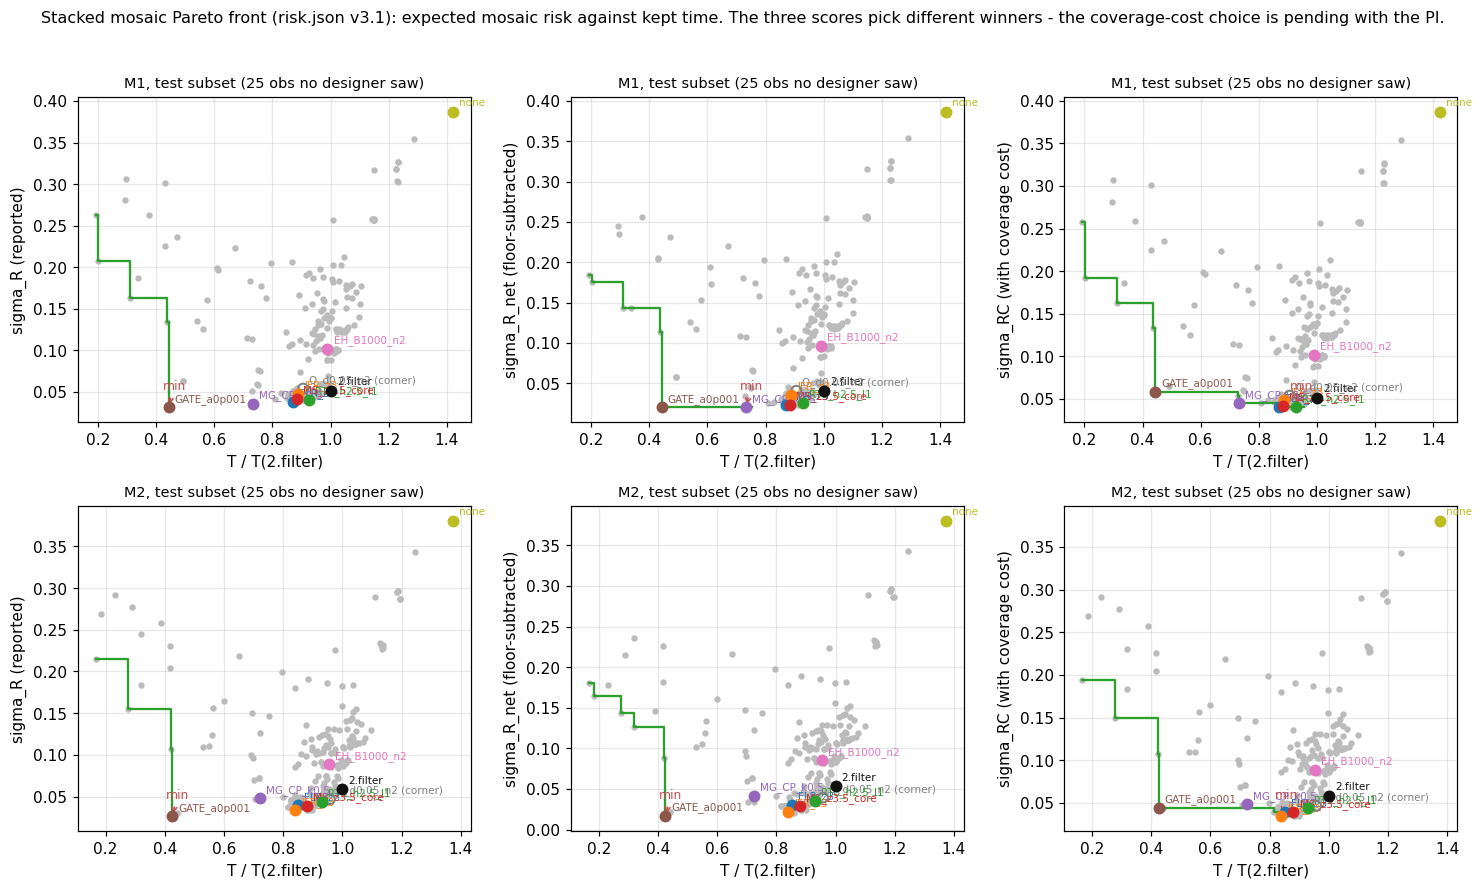
results/c001_risk_v31/risk.json (test 子集行)(the test-subset rows); cognition-os/experiments/E019_criterion_v3_random_effects.md (v3.1 一节、RT-08 F04、RT-18)(the v3.1 section, RT-08 F04, RT-18); E022_flr_hardness_gate.md (丢观测数与 FLR_z3 的硬度门)(dropped observations and FLR_z3's hardness gate).
"某政策在前沿的什么位置?""Where does policy X sit?"
选一个政策(与相机):上表给出它在 210 个政策里的排名、到前沿的距离(同 T 处前沿分数减去它的分数,负值 = 在前沿上/更优)、对 2.filter 的配对差与自举离散 p16–p84,以及 T/2.filter。数字来自 risk.json 的 test 子集(25 个观测)。同时下面两张前沿图会换成该政策被高亮的版本(更大的点、粗体标签、箭头):单观测前沿(第 4 节)与叠加前沿(第 5 节)。相机选择只改表格与叠加图——单观测图固定画 MOS1 与 MOS2 两列。
Pick a policy (and camera): the table gives its rank among the 210 policies, its distance to the front (the front's score at the same T minus its own; negative = on/below the front), the paired difference against 2.filter with its bootstrap spread p16–p84, and T/2.filter. The numbers come from the test subset (25 observations) of risk.json. The two front figures below also switch to a version with that policy highlighted (bigger marker, bold label, arrow): the per-observation front (section 4) and the stacked front (section 5). The camera choice changes only the table and the stacked figure — the per-observation figure always draws both MOS1 and MOS2.
排名按该分数在 210 个政策中的位置;距离为 0 表示该政策就在前沿上;负值表示它比同 T 处的前沿更优(前沿阶梯未覆盖该点之外)。σ_RC 一列按 RT-18 降级处理,不作排名。
The rank is the policy's position among the 210 policies under that score; a distance of 0 means it lies on the front; a negative value means it is better than the front at the same T (the staircase does not extend beyond that point). The σ_RC column is demoted per RT-18 and is not a ranking.
per_obs.json;见第 4 节。
The per-observation front (0800730301 and 0800730101 × MOS1/MOS2) with the chosen policy highlighted. Source: per_obs.json; see section 4.
risk.json;见第 5 节。
The stacked front (test subset, the chosen camera) with the chosen policy highlighted. Source: risk.json; see section 5.
6. 观测之间的一致性6. Consistency between observations
第一张图是配对哑铃图:每个观测一行,黑点 = 2.filter 的 σ_o,蓝点 = FLR_z3 的 σ_o(同一观测、同一相机、同一收据)。它回答"哪些观测赢了"——每一条蓝点在黑点左边的行就是 σ_o 更低的那一行。
The first figure is a paired dumbbell plot: one row per observation, black = 2.filter's σ_o, blue = FLR_z3's σ_o (same observation, same camera, same receipt). It answers "which observations gain" — every row where the blue dot sits left of the black one is a row where σ_o is lower.
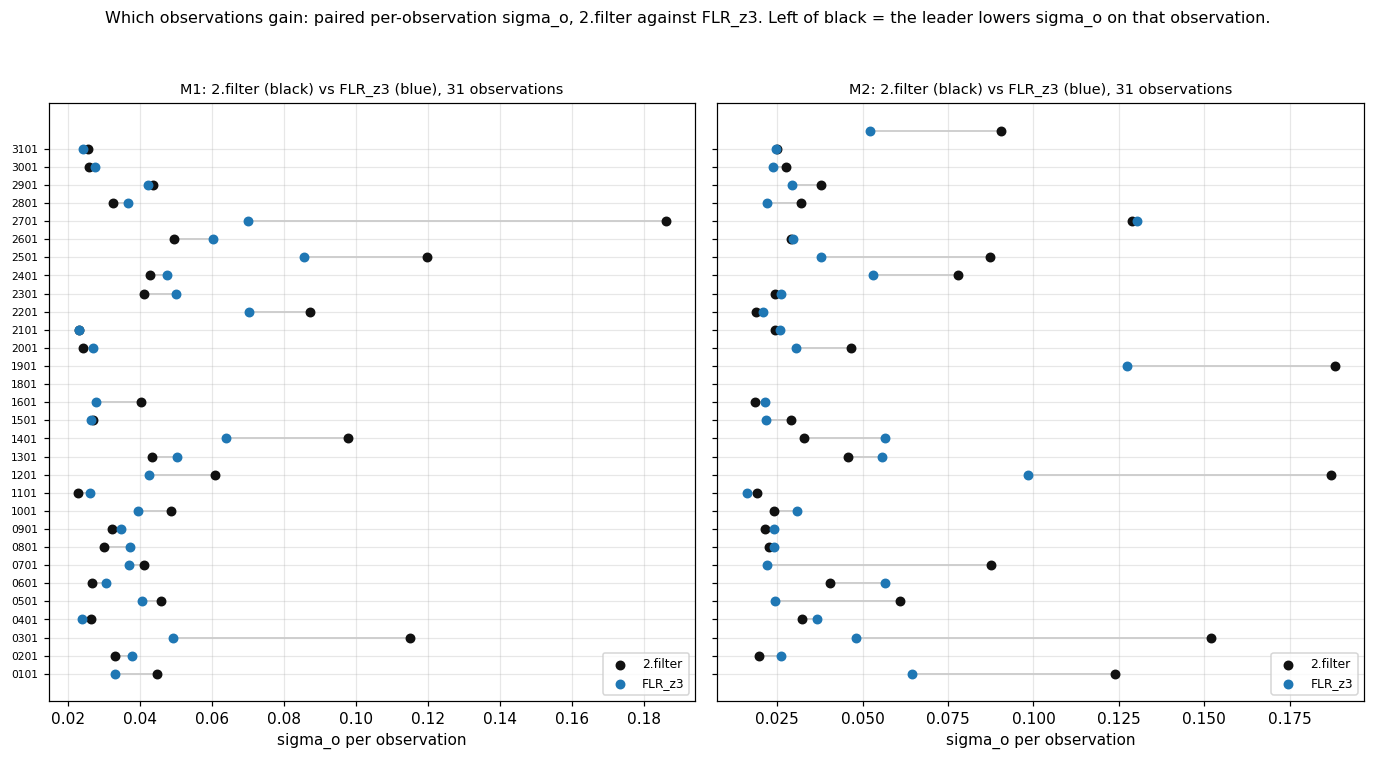
results/c001_risk_v31/per_obs.json (每观测 σ_o = √(τ²_0.5 + 1/N))(per-observation σ_o = √(τ²_0.5 + 1/N)).
池化的每观测水平偏移(RT-12 F-02)。这是比中位 τ_b 更有功效的统计量:把每个观测在同一 z 仓的(泊松误差 < 25% 的)亮度偏差取平均,得到每观测偏移;其跨观测 rms(扣除平均泊松噪声)就是"观测间散布"。2.filter 下它是 10.5%(MOS1)与 7.9%(MOS2)。配对自举差(1000 次重采样,95% 区间):
The pooled per-observation offset (RT-12 F-02). This is a more powerful statistic than the median τ_b: for each observation, average its fractional deviations from the same-z mean over its well-measured bins (Poisson error < 25%); the rms of these per-observation offsets across observations, corrected for the mean Poisson noise, is the between-observation scatter. Under 2.filter it is 10.5% (MOS1) and 7.9% (MOS2). Paired bootstrap differences (1000 resamples, 95% intervals):
| 政策Policy | MOS1 Δ [95%] | MOS2 Δ [95%] |
|---|---|---|
Q_d0.05_n2 (用角落)(corner) |
−3.7 pp [−5.9, −0.1] | −2.3 pp [−3.3, −0.9] |
gen2:hermes.FLR_z3 |
+0.5 pp [−0.5, +1.3] (含 0,持平)(contains 0: no significant difference) | −2.0 pp [−3.3, −0.7] |
gen2:hermes.JFR_z3.5 |
+2.1 pp [−0.3, +3.4] | −1.9 pp [−3.2, +0.0] |
merged:sonnet.MG_CP_k0.5 |
+1.5 pp [−0.4, +2.5] | +0.3 pp [−0.5, +1.2] |
merged:sol.MS_z3.5_core |
+2.2 pp [−1.2, +3.8] (含 0,持平)(contains 0: no significant difference) | −1.3 pp [−3.1, +0.1] (含 0,持平)(contains 0: no significant difference) |
EH_B1000_n2 |
+25.5 pp [−0.2, +37.8] | +11.2 pp [−1.4, +17.6] |
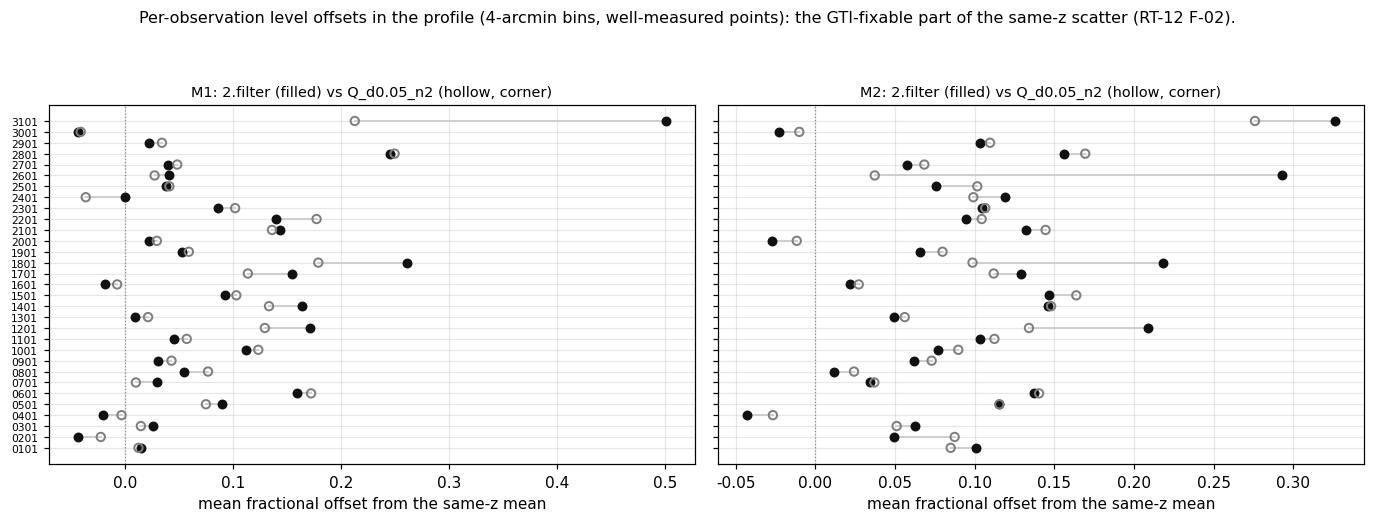
results/redteam/rt12-profile/hermes/check7c_pooled_fixed.out (上表)(the table); check2b_offsets.out, check17_spearman.out (偏移与相关)(offsets and correlations); e020_m31_profile/sol/run2/profiles.json (本图)(this figure); cognition-os/experiments/E020_m31_vertical_profile.md (RT-12 一节)(the RT-12 section).
Lockman Hole:一个观测承担的观测间项The Lockman Hole: one observation carrying the between term
在 Lockman Hole(13 个观测)上,2.filter 的观测间项本来就是 14.6%(MOS1)/ 23.3%(MOS2)(角落修正后;CDFS 同法只有 0.0%)。RT-06 找到原因:0022740101 一个观测(DATE-OBS 2001-10-25)承担了几乎全部——espfilt 的直方图峰锁在它的耀斑上(μ_H = 3.0 / 2.6 c/s,集合中位数的 6.8× / 6.0×),2.filter 在这个水平上保留 13.5 ks / 7.4 ks,保留的软率是中位的 1.8× / 2.8×。单独删掉它,between 降到 9.3% / 8.9%;其余每个观测的刀切检验都留在 22.6–25.5%(MOS2)。角落在 LH 上几乎不起作用(只移走 0.3 / 0.0 点,CDFS 上是 11.4 / 13.5 点),因为粒子超额在 FOV 内、角落看不到。这一失效类(espfilt 把静息峰锁到耀斑上)正是运行中的 R2(跨观测静息参考)的目标。
On the Lockman Hole (13 observations), the between term under 2.filter is already 14.6% (MOS1) / 23.3% (MOS2) (corner-corrected; the same pipeline gives 0.0% on CDFS). RT-06 found the cause: the single observation 0022740101 (DATE-OBS 2001-10-25) carries almost all of it — espfilt's histogram peak locks onto its flare (μ_H = 3.0 / 2.6 c/s, 6.8× / 6.0× the set median), 2.filter keeps 13.5 ks / 7.4 ks at that level, and the kept soft rate is 1.8× / 2.8× the median. Dropping it alone takes the between term to 9.3% / 8.9%; every other observation's jackknife leaves 22.6–25.5% (MOS2). The corner does almost nothing on the LH (it removes 0.3 / 0.0 points against 11.4 / 13.5 on CDFS) because the particle excess sits inside the FOV, where the corner cannot see it. This failure class — espfilt locking its quiescent peak onto a flare — is what the running R2 (a cross-observation quiescent reference) targets.
cognition-os/experiments/E008_lockman_frozen_tests.md (RT-06 一节)(the RT-06 section); results/redteam/RT-06/hermes/step4_epoch_pointing.json, step11.log, step20.log; results/c001_lockman/frozen_test_lockman_M{1,2}.json; RESEARCH_PLAN.md R2.7. 竖直剖面(M31 短轴)7. The vertical profile (M31 minor axis)
2.filter 与三个领先政策(FLR_z3、JFR_z3.5、MG_CP_k0.5)的 0.5–2 keV 竖直剖面(4′ 仓,对数亮度;左 MOS1、右 MOS2;sol run2,CCD 足迹修正后的产品)。四条曲线几乎重合——这本身就是结果:剖面的形状对政策不敏感,一致性问题出在"同一 z 仓内不同观测的散布"上,而不是形状上。
The 0.5–2 keV vertical profiles of 2.filter and three leaders (FLR_z3, JFR_z3.5, MG_CP_k0.5; 4′ bins, log brightness; MOS1 left, MOS2 right; the sol run2, CCD-footprint-corrected products). The four curves nearly coincide — that is itself the result: the profile's shape is insensitive to the policy; the consistency problem lives in the scatter of different observations within the same z bin, not in the shape.
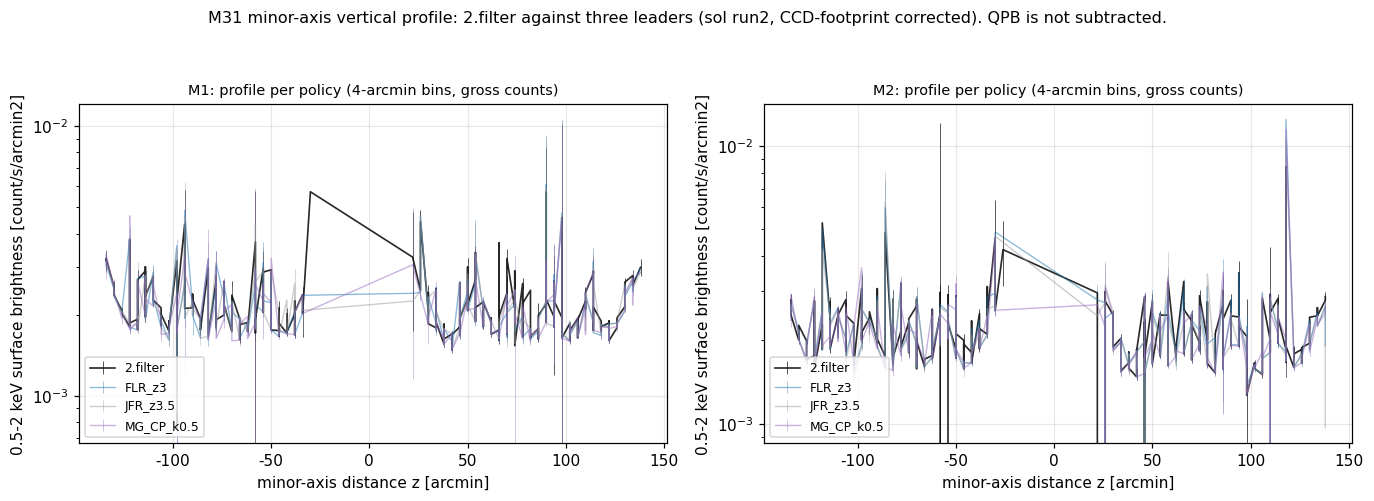
results/e020_m31_profile/sol/run2/profiles.json, consistency.json, table.md (修正后的 run2 产品)(the corrected run2 products); cognition-os/experiments/E020_m31_vertical_profile.md.
- 中位 τ_b 的变化"未检出",不是"没有"。政策把中位 τ_b 改变 −0.5 到 −0.8 pp;但该检验对 E019 预测的变化(−0.8…−1.1 pp MOS1、−1.9 pp MOS2)只有 1–2σ 的功效(配对自举 σ 为 0.7–1.9 pp)——观测值落在 0 与预测的 1σ 之内(RT-12 F-01)。E020 原来的结论"没有政策改善剖面"据此撤回,改为"未检出"。 The median-τ_b change is "not detected", not "absent". The policies move the median τ_b by −0.5 to −0.8 pp; but the test has only 1–2σ power for the change E019 predicts (−0.8…−1.1 pp MOS1, −1.9 pp MOS2; the paired bootstrap σ is 0.7–1.9 pp) — the observed value lies within 1σ of both 0 and the prediction (RT-12 F-01). E020's original conclusion "no policy improves the profile" is withdrawn on this point and replaced by "not detected".
- 同 z 散布的 43–46%(τ_b²)是每观测的水平偏移(RT-12 F-02):把每个观测的 z 无关偏移减掉,中位 τ_b 从 8.8% 降到 6.5%(MOS1)、从 11.5% 降到 8.7%(MOS2)。 43–46% of the same-z scatter (τ_b²) is a per-observation level offset (RT-12 F-02): removing each observation's z-independent offset takes the median τ_b from 8.8% to 6.5% (MOS1) and from 11.5% to 8.7% (MOS2).
- 在那个池化统计上,确有政策显著降低偏移:FLR_z3 在 MOS2 上 −2.0 pp(95% [−3.3, −0.7]);Q_d0.05_n2 两台相机都降(见第 6 节的表)。留一法保持每个 Δ 为负。 On that pooled statistic, some policies do lower the offset significantly: FLR_z3 on MOS2 −2.0 pp (95% [−3.3, −0.7]); Q_d0.05_n2 on both cameras (the table in section 6). Leave-one-out keeps every Δ negative.
- 剩下的散布不是纯 GTI 效应:偏移是软能段主导、与 2.filter 的保留比例反相关(Pearson −0.52 / −0.65,MOS1 / MOS2;Spearman 版本为 −0.37 / −0.63)——残余软质子 + 一部分 QPB;要分开它们需要 QPB 相减(MosaicSelfCal),那是 R7 的 QPB 相减变体。 The remaining scatter is not a pure GTI effect: the offsets are soft-dominated and anti-correlate with 2.filter's kept fraction (Pearson −0.52 / −0.65, MOS1 / MOS2; the Spearman form is −0.37 / −0.63) — residual soft protons plus some QPB; separating them needs QPB subtraction (MosaicSelfCal), which is R7's QPB-subtracted variant.
- 这个剖面读法取决于曝光模型(RT-15,2026-10-16)。RT-12 F-03 发现的逐 CCD 观测/预测图案(MOS1 CCD1 0.79、CCD2 1.33、CCD7 1.21)在 8–12 keV 同样存在,是仪器性的(未被 vignetting 的成分除以被 vignetting 的曝光图)。把曝光图换成逐 CCD 平坦值,2.filter 的中位 τ_b 降 16.5%(MOS1,0.090 → 0.075)与 30%(MOS2,0.108 → 0.076),政策顺序改变:平坦曝光下 2.filter 在两台相机都排最后。所以"未检出"是有条件的结论;C001 的 σ_R 判据只用光变曲线、不用曝光图,不受影响。 This profile reading depends on the exposure model (RT-15, 2026-10-16). The per-CCD observed/predicted pattern found by RT-12 F-03 (MOS1 CCD1 0.79, CCD2 1.33, CCD7 1.21) is also present in 8–12 keV and is instrumental (an unvignetted component divided by a vignetted exposure map). Replacing the exposure map with a flat per-CCD value lowers 2.filter's median τ_b by 16.5% (MOS1, 0.090 → 0.075) and 30% (MOS2, 0.108 → 0.076), and the policy order changes: under flat exposure 2.filter is last on both cameras. So "not detected" is a conditional conclusion; C001's σ_R criterion uses light curves only and no exposure map, so it is unaffected.
每观测偏移的图在第 6 节(fig_front_offsets.png)。近盘仓(|z| < 60′)的 τ_b 比远盘仓多约 3 pp(RT-12 F-06:MOS1 中位 11.6% 对 8.7%,MOS2 13.6% 对 10.7%)——R7 的预注册将限制在远盘仓上。
The per-observation-offset figure is in section 6 (fig_front_offsets.png). The near-disk bins (|z| < 60′) carry about 3 pp more τ_b than the far bins (RT-12 F-06: MOS1 median 11.6% vs 8.7%, MOS2 13.6% vs 10.7%) — R7's pre-registration will restrict to the far-disk bins.
results/redteam/rt12-profile/hermes/check1b_power.out, check2c_remove_offset.out, check4_disk.out, check17_spearman.out; cognition-os/experiments/E020_m31_vertical_profile.md (RT-12 与 RT-15 两节)(the RT-12 and RT-15 sections); RESEARCH_PLAN.md R7.8. 还没有展示的(诚实清单)8. What is not yet shown (the honest list)
- 覆盖代价的价格还没有定论,σ_RC 已被降级。RT-18(2026-10-16)发现 σ_RC 给每个被丢指向收同一个中位 V_miss(MOS1 0.0045),而实际被丢指向的插值残差大一个量级(FLR_z3 丢的 1701/1801/3101 均值 0.044),且 V_miss 混入了 2.filter 自己的失效(9/31 个残差的邻居是 2.filter 失效观测);估计量的自举离散 5.8–11.2%,蒙特卡洛偏差 −30% / +40%。一个正确的价格需要被丢指向的干净参考水平,还没有。所以本页只用 σ_R 排名,另列报告每个政策丢掉的观测数(E022/R13)。 The coverage price is not settled, and σ_RC has been demoted. RT-18 (2026-10-16) found that σ_RC charges every dropped pointing the same median V_miss (MOS1 0.0045), while the interpolation residuals of the pointings actually dropped are an order of magnitude larger (FLR_z3's dropped 1701/1801/3101 average 0.044), and V_miss mixes in 2.filter's own failures (9 of 31 residuals have a 2.filter-failed neighbour); the estimator's bootstrap spread is 5.8–11.2% with a −30% / +40% Monte-Carlo bias. A correct price needs a clean reference level for the dropped pointing, which does not exist yet. So this page ranks on σ_R only and reports the dropped-observation count separately (E022/R13).
- 主候选 FLR_z3 正在被重新询问(E022,2026-10-16)。它的 M31/LH 优势来自绝对硬度门(静息 h/u 与 M31 halo 常数 r0 = 1.8 比较):关掉硬度部分后(FLRr_z3,只留率偏移),M31 MOS1 变成 −0.67 pp [−1.64, +0.35] 持平,LH 从 −5.53 降到 −2.91。同一个门在 Virgo-server 集上丢掉 51/142(MOS1,2.filter 时间的 34%)与 54/142(MOS2,38%)个观测——M31 Core、NGC 1365、M32、NGC 1399 的热气团:亮源或硬目标场的天空比 1.8 更硬,一个弥漫发射分析会因此丢掉全部数据。下一步 R13:预注册 MS_z3.5_core 与 FLRr_z3,各配 (a) 场参照拒绝门 XJ_g1.5(E021)、(b) R11 线门、(c) 两者,在四个集上打分,由 PI 在 FLR_z3 与加了门的 MS 之间决定。 The main candidate FLR_z3 is being re-asked (E022, 2026-10-16). Its M31/LH edge comes from the absolute hardness gate (the quiescent h/u against the M31-halo constant r0 = 1.8): with the hardness parts switched off (FLRr_z3, rate excursion only), M31 MOS1 becomes −0.67 pp [−1.64, +0.35] (no significant difference) and the LH falls from −5.53 to −2.91. The same gate drops 51/142 observations (MOS1, 34% of 2.filter's time) and 54/142 (MOS2, 38%) on the Virgo-server set — M31 Core, NGC 1365, M32, NGC 1399's hot gas: the sky of bright or hard targets is harder than 1.8, and a diffuse-emission analysis would lose all its data. Next, R13: pre-register MS_z3.5_core and FLRr_z3, each with (a) the field-referenced rejection gate XJ_g1.5 (E021), (b) the R11 line gate, (c) both, scored on all four sets, with the PI deciding between FLR_z3 and the gated MS.
- 跨观测静息参考(R2 / E021)已经跑完,没有产生新的领先政策。两个执行臂(codexnim 与 Hermes)共 8 个家族 42 个掩蔽,全部无角落。结论:在 M31 上场参照不打败单观测领先政策(codexnim HSH_q20_z3 MOS1 −0.21 [−1.18, +0.78] 持平、MOS2 −2.75;Hermes HRt_z4 排名 15 / 12,不是领先者——报告里"MOS2 全场最好"的说法已被 QA 更正)。它的价值是失效探测器:XJ_g1.5 在两侧相机都拒绝 M31 3101、1701 与 LH 0101(开发集误拒 5/45),而 FFC_q20_z4 完整拒绝 LH 0101 但只把 M31 3101 切到 0.35–0.42。Hermes 臂的 XQ 家族仍在 QA 中(待复核 / under review)。R11 的线锚门(P003 已冻结)只拒绝一个测试观测 0674210601——一个 2.filter 漏掉的真实高电平观测,而两个领先政策已经修好它,所以门被保留为 D017 的拒绝规则(安全网),不作为 σ_R 改进。 The cross-observation quiescent reference (R2 / E021) has finished and produced no new leader. Two executor arms (codexnim and Hermes), 8 families and 42 masks in total, all corner-free. Conclusion: on M31 a field reference does not beat the single-observation leaders (codexnim HSH_q20_z3 MOS1 −0.21 [−1.18, +0.78] no significant difference, MOS2 −2.75; Hermes HRt_z4 ranks 15 / 12, not a leader — the report's "best in the whole pool on MOS2" was corrected by QA). Its value is as a failure detector: XJ_g1.5 rejects M31 3101, 1701 and LH 0101 on both cameras (5/45 false drops on development), while FFC_q20_z4 rejects LH 0101 completely but only cuts M31 3101 to 0.35–0.42. The Hermes XQ families are still being QA'd (under review). R11's line-anchored gate (P003 frozen) rejects exactly one test observation, 0674210601 — a real high-level observation 2.filter missed, which both leaders already repair, so the gate is kept as the D017 rejection rule (a safety net), not as a σ_R improvement.
- "复现 2.filter" 的定义已改为文件级(PI 2026-10-16;R10 在跑)。R3 的预算规则被 RT-17 修正为"水平预算 AND 活时间在 ±10% 内"(E_k2.5 403/446,E_k1 13/446),但它只是 E_k2.5 的水平一致性诊断;真正判据是我们的链喂进 2.filter 的区间后写出同样的 gti/allevc/lightcurve 文件。R10 的 Layer A 已在 6 个 CDFS 相机案例上通过(30/30 个文件 0 数据差、0 结构关键字差);espfilt 直方图拟合的 PRIMARY 关键字(CENTER、WIDTH、NORM…)在复现文件里缺失,是否被下游读取要等 Task 4 冒烟测试。Layer B 与 codexnim 臂仍在跑。 The definition of "reproducing 2.filter" is now file-level (the PI, 2026-10-16; R10 running). R3's budget rule was corrected by RT-17 to "level budget AND live time within ±10%" (E_k2.5 403/446, E_k1 13/446), but it is only a level-agreement diagnostic of E_k2.5; the real criterion is that our chain, fed 2.filter's intervals, writes the same gti/allevc/lightcurve files. R10's Layer A has passed on the 6 CDFS camera cases (30/30 files with 0 data and 0 structural-keyword differences); the espfilt histogram-fit PRIMARY keywords (CENTER, WIDTH, NORM…) are absent from the reproduced files, and whether any downstream task reads them is what the Task-4 smoke test must show. Layer B and the codexnim arm are still running.
- 政策是在 6 个开发案例上选的。本页的领先政策(FLR_z3、JFR_z3、RT3_h2.5_l1、MG_CP_k0.5、MS_z3.5_core、GATE)出自 E012/E015 在六个基本案例上的设计;25 个测试观测的数字是"没被设计者看过"的,但案例本身是开发数据。R9 已把三个稳健政策对 2.filter 的优势复制到 CDFS、LH 与 Virgo-server 集(8 个集×相机全部显著);GATE 在 CDFS/LH 上丢光时间、EH_B1000_n2 不修复 espfilt 的失效(M31、LH)但在 espfilt 正常的地方有帮助(E019 R9 与 RT-16 F-02 的措辞更正)。RT-16 F-01:优势主要是修好 2.filter 失效的观测——M31 MOS1 去掉两个最差观测后 FLR_z3 只剩 −0.79 pp、MS_z3.5_core 变成 +0.33 pp;三个领先政策的活时间重叠 0.79–0.93,是同一个设计家族而非三个独立确认(F-04)。任何政策在被推出去之前仍需一次新鲜场检验。 The policies were chosen on 6 development cases. The leaders on this page (FLR_z3, JFR_z3, RT3_h2.5_l1, MG_CP_k0.5, MS_z3.5_core, GATE) were designed on the six basic cases in E012/E015; the 25 test observations were never seen by a designer, but the cases themselves are development data. R9 has replicated the three robust policies' advantage over 2.filter on CDFS, the LH and the Virgo-server set (significant in all 8 set × camera cases); GATE drops nearly all time on CDFS/LH, and EH_B1000_n2 does not repair espfilt's failures (M31, LH) but helps where espfilt works (the E019 R9 wording corrected by RT-16 F-02). RT-16 F-01: the advantage is mostly the repair of 2.filter's failed observations — on M31 MOS1, removing the two worst observations leaves FLR_z3 at only −0.79 pp and turns MS_z3.5_core into +0.33 pp; the three leaders' live time overlaps 0.79–0.93, so they are one design family, not three independent confirmations (F-04). Any policy still needs one fresh-field test before being put forward.
- 谱验证(C2)还没做。C001 的光变曲线判据最终要用光谱一致性检验(MosaicSelfCal CDFS 金/银 cell 上的 τ 排名);PI 决定 C2 在 P002 之后(D008)。 Spectral validation (C2) has not been done. C001's light-curve criterion must finally be checked against spectral consistency (the τ ranking on the MosaicSelfCal CDFS golden/silver cells); the PI decided C2 waits for P002 (D008).
- QPB 没有减。本页所有剖面与偏移都是毛计数:天空 + QPB + 残余软质子混在一起。QPB(约 10% 量级)的差异会以"每观测偏移"的形式出现在第 6/7 节里;分开它需要 MosaicSelfCal 的背景建模。 QPB is not subtracted. Every profile and offset on this page is a gross count: sky + QPB + residual soft protons together. QPB differences (of order 10%) appear as "per-observation offsets" in sections 6 and 7; separating them needs MosaicSelfCal's background modelling.
- R2(跨观测静息参考)已跑完,但没有产生新的领先政策(E021,2026-10-16;详见上文)。它针对的正是本页展示的两类 2.filter 失效(0800733101 与 0022740101——espfilt 把静息峰锁到耀斑上):场参照能完整拒绝 LH 0101,却只能把 M31 3101 切到 0.35–0.42。它的下一步不是当更好的裁剪,而是当拒绝规则:R13 预注册"领先政策 + 场参照拒绝门 / 线门"的组合,PI 在 FLR_z3 与加了门的 MS_z3.5_core 之间决定。 R2 (the cross-observation quiescent reference) has finished and produced no new leader (E021, 2026-10-16; see above). It targets exactly the two 2.filter failure classes shown on this page (0800733101 and 0022740101 — espfilt locking its quiescent peak onto a flare): a field reference rejects LH 0101 completely but only cuts M31 3101 to 0.35–0.42. Its next step is not as a better clip but as a rejection rule: R13 pre-registers "leader + field-referenced rejection gate / line gate", with the PI deciding between FLR_z3 and the gated MS_z3.5_core.
RESEARCH_PLAN.md (待决表与 R2/R7/R9/R10/R13 行)(the pending-decisions table and the R2/R7/R9/R10/R13 rows); cognition-os/experiments/E019_criterion_v3_random_effects.md (R9、RT-16、RT-17、RT-18 各节)(the R9, RT-16, RT-17 and RT-18 sections); E022_flr_hardness_gate.md; E021_xq_cross_observation_reference.md; E007_c001_frontier_scan.md (R3 与 RT-17 节)(the R3 and RT-17 sections); E020_m31_vertical_profile.md (RT-12 F-04、RT-15)(RT-12 F-04, RT-15); 04_DECISION_LOG.md D008, D013–D017.