现状(2026-10-13,D006 后)Where things stand (2026-10-13, after D006)
一句话:P001 已关闭,结论是否定的 —— R 筛选是有效的(valid),但在等保留率下,它在 M31 MOS1、M31 MOS2、CDFS MOS1、CDFS MOS2 四个主集上都不比标准 2.filter 更好(useful 不成立)。R 族的增益来自"选保留率",不属于"选哪段时间"。角落按数据集回答:CDFS 可用、M31 MOS1 太吵。
One line: P001 is closed with a negative conclusion — the R screen is valid, but at equal retention it is not better than the standard 2.filter on any of the four primary sets (M31 MOS1, M31 MOS2, CDFS MOS1, CDFS MOS2); the "useful" claim fails. The R-family's gains come from choosing a retention, not from choosing better time. The corner is answered per set: usable on CDFS, too noisy on M31 MOS1.
1. 已确立的(全部有收据)1. Established (all receipted)
| 事实Fact | 数字Number | 来源Source |
|---|---|---|
| 迁移工程完成Migration engineering complete | 校验器 PASS(在线与离线):69 文件、3,145,929 字节、57 个 Python 解析、5 份收据。Verifier PASS (online and offline): 69 files, 3,145,929 bytes, 57 Python files parsed, 5 receipts. | E001_migration_verification.md |
| 回归门通过(冻结代码 = 未修改 g1 脚本)Regression gate passed (frozen code = unmodified g1 script) | 26,111 个数字,最大相对差 0;与存档 g1 收据仅 2 处元数据差异。26,111 numbers, max relative difference 0; only 2 metadata differences vs the stored g1 receipt. | results/p001_regression/regression_check_a2_vs_orig.json |
| g1 零控制(FWER)通过g1 zero-control (FWER) passes | MOS1:0/78(9 个规则零控制);MOS2:0/58(7 个)。MOS1: 0/78 (9 rule zero controls); MOS2: 0/58 (7). | p001_endpoints_m31.json E1 |
| 线窗恒定性Line-window constancy | MOS1:χ²/dof = 287.4/245 = 1.17,无 |slope| > 3σ;MOS2:254.4/247 = 1.03。MOS1: χ²/dof = 287.4/245 = 1.17, no |slope| > 3σ; MOS2: 254.4/247 = 1.03. | line_continuum_invariant.json(两台相机的 line_stability_summary)line_continuum_invariant.json (line_stability_summary for both cameras) |
| M31 MOS2 历史证据(已消费)M31 MOS2 historical evidence (consumed) | r14 21/8 (Z=5.0)、r20 16/6 (Z=4.3)、r22 9/1 (Z=3.7);r16 10/8 不迁移;A1:移除超额 ~79% 无线 (Al −5.96σ);B1:延展非紧凑,角落 +2.8% (z=1.7)。r14 21/8 (Z=5.0), r20 16/6 (Z=4.3), r22 9/1 (Z=3.7); r16 10/8 does not transfer; A1: removed excess ~79% line-free (Al −5.96σ); B1: extended not compact, corner +2.8% (z=1.7). | cognition-os/insights/I002_historical_evidence_reconciliation.md |
2. P001 终点表(M31 两台相机)2. P001 endpoints (both M31 cameras)
| 终点Endpoint | M31 MOS1 (盲测)(blind) | M31 MOS2 (参考,已消费)(reference, consumed) |
|---|---|---|
| E1 零控制 FWERzero-control FWER | PASS 0/78(9 个零控制)0/78 (9 zero controls) | PASS 0/58(7 个)0/58 (7) |
| 零假设居中(仅报告,A3)Null-centring (reported only, A3) | 2 行在 ±0.02 之外 (f_T ≥ 0.5)2 rows outside ±0.02 (f_T ≥ 0.5) | 4 行在 ±0.02 之外4 rows outside ±0.02 |
| E2 线门失败计数line-gate fail count | PASS 0 vs 0 (n=25)0 vs 0 (n=25) | PASS 2 vs 2 (n=29)2 vs 2 (n=29) |
| E3 有用性(主终点)Usefulness (primary) | FAIL 13/25 正,符号 p = 0.50,Stouffer Z = 0.0213/25 positive, sign p = 0.50, Stouffer Z = 0.02 | FAIL 21/29 正,p = 0.012,Z = 1.6421/29 positive, p = 0.012, Z = 1.64 |
| E4 相机一致性(仅描述)Camera consistency (descriptive) | Spearman ρ = 0.08 (n=25, p = 0.69)Spearman ρ = 0.08 (n=25, p = 0.69) | |
| E5 ln(L_K/L_B),门内ln(L_K/L_B), as gated | +0.019 ± 0.019 (n=28)(n=28) | −0.008 ± 0.013 |
| E5 ln(L_K/L_B),反事实耦合ln(L_K/L_B), counterfactual coupling | −0.004 ± 0.019 | −0.028 ± 0.013 (−2.2σ)(−2.2σ) |
| E5 角落叠加 ln(Q_K/Q_B)corner stack ln(Q_K/Q_B) | −0.008 ± 0.0133 → TOO_NOISY | −0.003 ± 0.0098 → USABLE (勉强)(by a hair) |
results/p001_m31_mos1/p001_endpoints_m31.json; cognition-os/experiments/E002_p001_m31_mos1.md §结果§Results.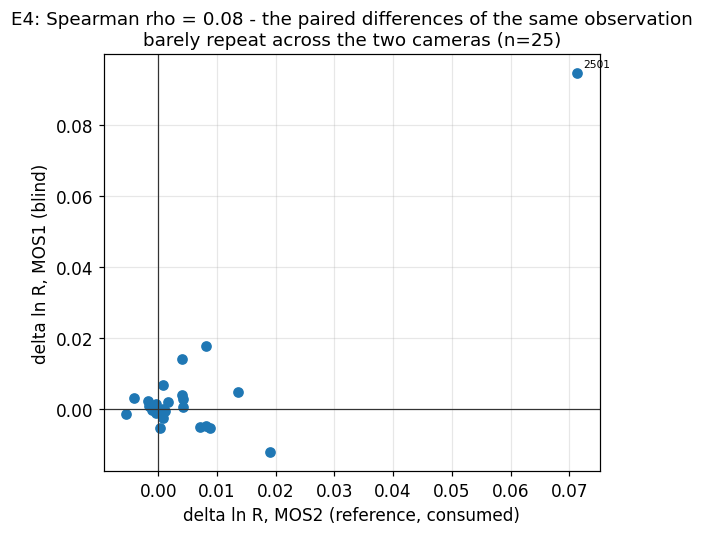
results/p001_m31_mos1/p001_endpoints_m31.json (E3 行,两台相机)(E3 rows, both cameras)
3. CDFS 终点表(空白场盲测,E003,两台相机)3. CDFS endpoints (the blank-field blind run, E003, both cameras)
| 终点Endpoint | CDFS MOS1 (盲测)(blind) | CDFS MOS2 (盲测)(blind) |
|---|---|---|
| E1 零控制 FWER(主集,29 ObsID)zero-control FWER (primary set, 29 ObsIDs) | NOT_EVALUABLE (主集里没有规则零控制 —— 每个 CDFS 观测都有耀斑或拒绝 ≥ 2%;A1 条款 2)(no rule zero control in the primary set — every CDFS observation has flares or rejects ≥ 2%; A1 item 2) | |
| E1 敏感性集(32 ObsID)sensitivity set (32 ObsIDs) | PASS 0/9(唯一零控制 0604960501)0/9 (the single zero control, 0604960501) | PASS 0/9(同一个)0/9 (the same one) |
| 零假设居中(仅报告,A3)Null-centring (reported only, A3) | 1 行在 ±0.02 之外(0108061901,f_T 0.5,1.024)1 row outside ±0.02 (0108061901, f_T 0.5, 1.024) | 1 行(0108061901,f_T 0.5,1.025)1 row (0108061901, f_T 0.5, 1.025) |
| E2 线门失败计数line-gate fail count | PASS 0 vs 0 (n=29)0 vs 0 (n=29) | PASS 0 vs 0 (n=29)0 vs 0 (n=29) |
| E3 有用性(主终点)Usefulness (primary) | FAIL 24/29 正,符号检验 p = 2.7e-424/29 positive, sign test p = 2.7e-4 | FAIL 27/29 正,符号检验 p = 8.1e-727/29 positive, sign test p = 8.1e-7 |
| E3 Stouffer Z(同一终点,分开的估计量)Stouffer Z (same endpoint, separate estimator) | Z = 1.55 (阈值 Z > 3)(threshold Z > 3) | Z = 1.73 (阈值 Z > 3;无伤害行)(threshold Z > 3; no harm rows) |
| E3 敏感性集sensitivity set | FAIL 25/32,Z = 1.5425/32, Z = 1.54 | FAIL 28/32,Z = 1.5828/32, Z = 1.58 |
| E5 ln(L_K/L_B),门内ln(L_K/L_B), as gated | +0.0057 ± 0.0062 (n=29)(n=29) | +0.0129 ± 0.0055 (n=29)(n=29) |
| E5 ln(L_K/L_B),反事实耦合(M31 注入 s)ln(L_K/L_B), counterfactual coupling (M31 injection s) | −0.0223 ± 0.0065 | −0.0153 ± 0.0058 |
| E5 角落叠加 ln(Q_K/Q_B)corner stack ln(Q_K/Q_B) | −0.0189 ± 0.0044 → USABLE | −0.0386 ± 0.0038 → USABLE |
| E6 中位 Δ(中位 z_Δ),描述性median Δ (median z_Δ), descriptive | +0.0035 (0.23) | +0.0029 (0.25) |
| E6 M31 对照(描述性)M31 comparison (descriptive) | M31 MOS1 +0.0005 (0.17);M31 MOS2 +0.0011 (0.32)M31 MOS1 +0.0005 (0.17); M31 MOS2 +0.0011 (0.32) | |
怎么读 E3:两个配对统计量分开说 —— 符号检验在两台相机上都显著(p = 2.7e-4 与 p = 8.1e-7),但 Stouffer Z 只有 1.55 与 1.73,远低于预注册的 Z > 3。增益的中位数约 0.3%(R),每观测 z_Δ ≈ 0.2 —— 方向真实、幅度可忽略。按项目的 D7 规则,对"选哪个滤波器"而言这是持平,不写"更好"。
How to read E3: the two paired statistics are reported separately — the sign test is significant on both cameras (p = 2.7e-4 and p = 8.1e-7), but the Stouffer Z is only 1.55 and 1.73, far below the pre-registered Z > 3. The median gain is about 0.3% in R, per-observation z_Δ ≈ 0.2 — real in sign, negligible in size. Under the project's D7 rule this is no significant difference for choosing a filter, not "better".
其他数字:κ = 1.038(M1)/ 1.017(M2);线窗 χ²/dof = 1780/1653 = 1.08(M1)与 1708/1651 = 1.03(M2),无 |slope| > 3σ;被删时间的角落 2.5–8 keV 率比保留时间高 1.9%(MOS1,−4.3σ)与 3.9%(MOS2,−10σ)—— 所以 2.filter 也删掉了粒子背景升高的时段。六 个 ObsID 只有 U002 MOS 曝光,全部是科学曝光(XSA)。
Other numbers: κ = 1.038 (M1) / 1.017 (M2); line-window χ²/dof = 1780/1653 = 1.08 (M1) and 1708/1651 = 1.03 (M2), no |slope| > 3σ; the rejected time has a 1.9% (MOS1, −4.3σ) and 3.9% (MOS2, −10σ) higher corner 2.5–8 keV rate than kept time — so 2.filter also cuts periods of elevated particle background. Six ObsIDs have only U002 MOS exposures, all science exposures (XSA).
results/p001_cdfs/p001_endpoints_all.json; cognition-os/experiments/E003_p001_cdfs_blank_field.md §结果、§Reading§Results, §Reading; 04_DECISION_LOG.md D006.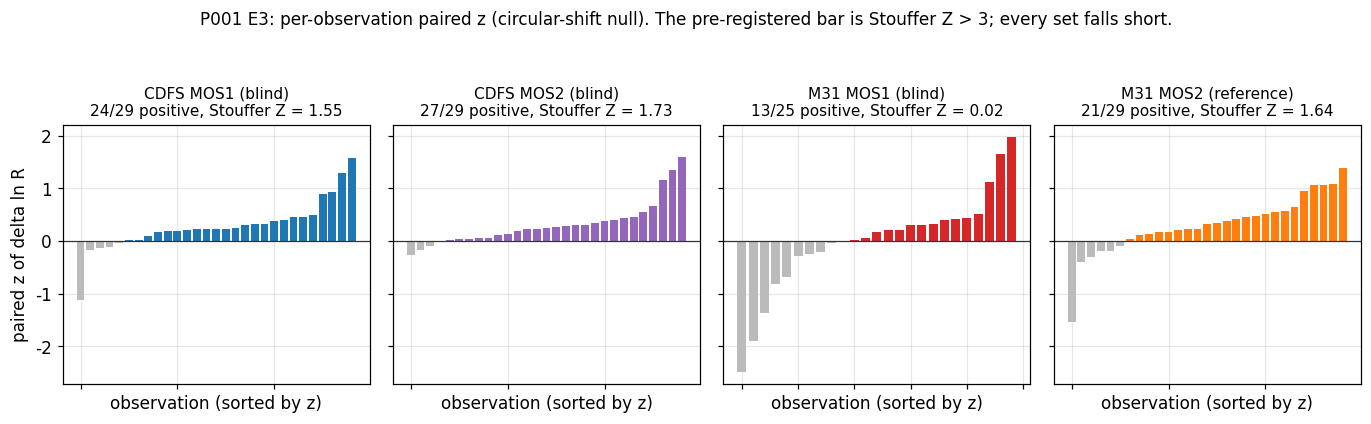
results/p001_cdfs/p001_endpoints_all.json (4 个主集的 E3 行)(E3 rows of the 4 primary sets)
4. 未解决的4. Open
- 下游成功判据(D002 第 3 步):尚无定义。E3 在四个主集上失败后,这是让任何 GTI 政策改变值得的唯一途径 —— 兑换率"1% 活时间损失 = 多少连续谱增益"要经父项目的响应折叠拟合给出。The downstream success criterion (D002 step 3): not yet defined. After E3 failed on all four primary sets this is the only route to justifying any change of GTI policy — the exchange rate "1% live time = how much continuum gain" must come from the parent's response-folded fit.
- 耦合 / Al 问题(T005、T016):CDFS 让它更尖锐。被删时间的角落数子水平高 2–4%,而门内 Al 线比是 +0.006 / +0.013(反事实修正后 −0.022 / −0.015);MOS1 与角落隐含值相符,MOS2 仍差 3.4σ。要么 Al 线不跟随角落连续谱,要么线测量有未建模的 K/B 系统误差。任何检验都必须先立预注册。The coupling / Al question (T005, T016): sharpened by CDFS. Rejected time has a 2–4% higher corner particle level, yet the as-gated Al-line ratio is +0.006 / +0.013 (−0.022 / −0.015 after the counterfactual correction); MOS1 agrees with the corner-implied value, MOS2 remains 3.4σ short. Either the Al line does not track the corner continuum, or the line measurement has an unmodelled K/B systematic. Any test needs its own pre-registration first.
- 0800731101 的线门:历史上未测 (UNTESTED,R = 4.98,线被自身连续谱淹没)。未测 ≠ 通过。The 0800731101 line gate: historically UNTESTED (R = 4.98, the line is swamped by its own continuum). Untested is not passing.
03_TRUST_TABLE.md (T005, T006, T008, T016, T017); 02_CURRENT_QUESTION.md "Status (D006)"; 04_DECISION_LOG.md D006.5. 信任等级(取自信任表)5. Trust levels (from the trust table)
| ID | 内容Item | 等级Level |
|---|---|---|
| T019 | 等保留率下 g1 率排名优于归档 2.filterAt equal retained time, g1 rate-rank beats the archived 2.filter | 在 M31 与 CDFS 上被驳倒(每个主集的 E3 都失败)REFUTED on M31 and CDFS (E3 fails on every primary set) |
| T020 | g1 R 筛选在 MOS1 上有效(零控制无假阳性)The g1 R screen is valid (no zero-control false positives) on MOS1 | 支持Supported |
| T021 | g1 R 筛选的有效性(E1)可以在 CDFS 上检验The g1 R screen's validity (E1) can be tested on CDFS | 主集上不可评估(无规则零控制);敏感性集上通过(0/9)Not evaluable on the primary set (no rule zero control); PASS on the sensitivity set (0/9) |
| T017 | 角落能精确预测 K/B 粒子级变化The corner can precisely predict the K/B particle-level change | 已按数据集回答:CDFS 可用(σ = 0.0044 / 0.0038),M31 MOS1 太吵(σ = 0.013)Answered per set: usable on CDFS (σ = 0.0044 / 0.0038), too noisy on M31 MOS1 (σ = 0.013) |
| T008 | 历史证据覆盖 MOS1+MOS2 与向 CDFS 的迁移Historical evidence covers MOS1+MOS2 and transfer to CDFS | 已测(E002、E003):两台相机、两个场都测了;筛选在任何一个上都不优于 2.filterTested (E002, E003): both cameras and both fields; the screen does not beat 2.filter on any of them |
| T005 | 历史耦合修正未应用;残余 Al 亏损未解决The historical coupling correction is unapplied; the residual Al deficit is unresolved | 存疑(CDFS 的角落发现使其更尖锐)Questioned (sharpened by the CDFS corner finding) |
| T009 | 缺线的移除超额证明删掉的是软质子A line-deficient removed excess proves soft protons were removed | 未确立(可变天体源仍是竞争解释)Not established (variable celestial sources remain a competitor) |
| T007 | 迁移工程完成 = 科学资质成立Migration engineering completion implies scientific qualification | 被驳倒Refuted |
cognition-os/03_TRUST_TABLE.md.6. 怎么读这些数字(诚实规则)6. How to read these numbers (honesty rules)
- 一句一个估计量:"门内 ln(L_K/L_B)" 与 "反事实耦合修正后的 ln(L_K/L_B)" 是两个不同估计量,永远不放在同一句里。One estimator per sentence: "as-gated ln(L_K/L_B)" and "counterfactual coupling-corrected ln(L_K/L_B)" are two different estimators and never share a sentence.
- 符号检验与 Stouffer Z 分开报:CDFS 上符号检验显著(p = 2.7e-4 与 8.1e-7)而 Stouffer Z 只有 1.55 与 1.73 —— 两个都是 E3 的配对统计量,但不是同一个数;E3 的成败只由预注册的 Z > 3 判定。Sign test and Stouffer Z are reported separately: on CDFS the sign test is significant (p = 2.7e-4 and 8.1e-7) while the Stouffer Z is only 1.55 and 1.73 — both are E3 paired statistics, but they are not the same number; E3 passes or fails only by the pre-registered Z > 3.
- 比较必须带配对检验:四个主集的 E3 都不达阈值(Z = 0.02、1.64、1.55、1.73,全部 < 3),所以对"选哪个滤波器"写作持平,不写"更好/更差"。约 0.3% 的中位增益是描述性的。Comparisons carry their paired test: no primary set's E3 meets the threshold (Z = 0.02, 1.64, 1.55, 1.73, all < 3), so for choosing a filter we write no significant difference, not "better/worse". The ~0.3% median gain is descriptive.
- R 不跨观测:R 的天花板由该观测自己的耀斑含量决定(1.0 到 11.8)。R is per-observation: its ceiling is set by that observation's own flare content (1.0 to 11.8).
- 探索性观察不是证据:角落与 Al 线的张力(3.2σ / 7.7σ)是事后 (post hoc) 的;在新的预注册跑完之前,它不进入任何结论。Exploratory observations are not evidence: the corner-vs-Al tension (3.2σ / 7.7σ) is post hoc; until a new pre-registration runs, it enters no conclusion.