误差预算与 Al 线(C001 与 P002)The error budget and the Al line (C001 and P002)
P001 关闭(否定)之后,项目的新主线是两件事:C001 —— PI 把"下游成功判据"定义为误差预算:多观测的一致性比信噪比重要;P002 —— 预注册检验"Al-K 荧光线是否跟随角落粒子水平"。本页从零讲这两件事:定义、快速估计、C1/C1b 两个实验、被撤回的 1.6%、P002 的冻结方法与 F1 结果,以及每一步还缺什么。所有探索性结果都标 探索性 / exploratory。
After P001 closed (negative), the project's new main line is two things: C001 — the PI defined the downstream success criterion as an error budget: over several observations, consistency matters more than S/N; and P002 — a pre-registered test of "does the Al-K fluorescence line track the corner particle level?". This page teaches both from zero: the definitions, the quick estimates, the C1 and C1b experiments, the withdrawn 1.6%, P002's frozen method and F1 result, and what is still missing at each step. Every exploratory result is labelled exploratory.
- C001 的想法(PI 原话)The C001 idea (the PI's words)
- 两个定义:σ_stat 与 σ_sysTwo definitions: σ_stat and σ_sys
- 快速看一眼 v1Quick look v1
- v2:拼接光变曲线v2: concatenated light curves
- C1:角落项C1: the corner term
- C1b:不相交能段裁剪C1b: the disjoint-band clip
- 被撤回的"1.6%"The withdrawn "1.6%"
- cell 尺寸与快速残差(D012)Cell size and the fast residual (D012)
- 冻结与 Lockman Hole 检验The freeze and the Lockman Hole test
- P002:问题与冻结方法P002: the question and the frozen method
- P002 F1 结果与解读P002 F1 results and reading
- 还缺什么What is still missing
1. C001 的想法(PI 原话,2026-10-13,D007)1. The C001 idea (the PI's words, 2026-10-13, D007)
P001 的负结果(等保留率下率排名不优于 2.filter)留下一个问题:那还有什么判据能让一个不同的 GTI 政策值得用?PI 的回答是把"成功"定义到下游 —— 不看 R,而看最终测量量的总误差:
P001's negative result (rate-rank at equal retention does not beat 2.filter) left one question: by what criterion could a different GTI policy ever be worth using? The PI's answer was to define "success" downstream — not by R, but by the total error of the finally measured quantity:
"用误差来定成功标准:连续谱降低,系统误差降低;曝光时间损失,统计误差变大。最后考虑 total 误差。这是单个观测的标准。多个观测的话,一致性比信噪比要求更高,或者说是多观测用相同方法后一起的系统误差和统计误差。这是快速方法,最后可以用谱来检验这个指标(M31CGM 观测的一致性,MosaicSelfCal 里的数据)。"
"Set the success criterion by the error: when the continuum falls, the systematic error falls; when exposure time is lost, the statistical error grows. In the end it is the total error that matters. That is the criterion for a single observation. For several observations, consistency matters more than signal-to-noise — or rather, it is the combined systematic and statistical error after all observations are treated by the same method. This is the quick method; in the end spectra can be used to check this metric (the consistency of the M31CGM observations, and the data in MosaicSelfCal)."
(中文为 PI 原话;英文是本手册的翻译。)判据全文见 prereg/C001_error_budget_criterion.md;C001 是判据不是检验:它定义"怎么打分",之后的光谱验证(C2)才是最终检验。
(The Chinese is the PI's own wording; the English is this handbook's translation.) The full criterion is in prereg/C001_error_budget_criterion.md; C001 is a criterion, not a test: it defines how to score, and the later spectral validation (C2) is the final check.
prereg/C001_error_budget_criterion.md §1 (PI 原话)(the PI's words); cognition-os/04_DECISION_LOG.md D007.2. 两个定义:σ_stat 与 σ_sys(一年级版)2. Two definitions: σ_stat and σ_sys (first-year version)
设想你要测一个弥散天空量(比如某能段的本底连续谱水平 C):统计误差 σ_stat 是"数出来的光子不够多"带来的误差 —— 光子数翻倍,它就除以 √2;删掉越多时间,光子越少,σ_stat 越大。系统误差 σ_sys 是"本底没建模对"带来的误差 —— 它正比于你必须建模的本底水平 C 本身;删掉被污染的时间,C 下降,σ_sys 跟着降。单个观测的总误差是两者按平方相加:
Suppose you want to measure a diffuse-sky quantity (say the background continuum level C in some band): the statistical error σ_stat comes from "not enough photons counted" — double the photons and it shrinks by √2; the more time you cut, the fewer the photons and the larger σ_stat. The systematic error σ_sys comes from "the background is not modelled correctly" — it is proportional to the background level C that must be modelled; cut the contaminated time and C falls, and σ_sys falls with it. The total error of one observation adds them in quadrature:
σ_tot = √(σ_stat² + σ_sys²), σ_sys = ε·C_K, σ_stat ≈ √(C_K/T_K) (T_K 是保留活时间;ε 是"曝光换连续谱"的兑换率,由数据定,不由人选)。(T_K is the retained live time; ε is the exchange rate between exposure and continuum, measured by the data, not chosen).
同一个天空看好几次观测、用同一政策处理时,规则反过来:一致性优先。每次观测给出一个估计值;这些估计值超出各自统计误差的散布,就是真实存在的系统误差(记 s_sys 或 τ)。它不随观测次数下降;而统计误差随总曝光下降。所以只要 s_sys 远大于 s_stat,删时间几乎不花代价,而任何能压低 s_sys 的裁剪都"稳赚":
When the same sky is observed several times and all observations are treated by one policy, the rule flips: consistency first. Each observation gives an estimate; the scatter of these estimates beyond their individual statistical errors is the systematic that is actually present (written s_sys or τ). It does not fall with the number of observations, while the statistical error falls with total exposure. So as long as s_sys is far above s_stat, cutting time costs almost nothing, and any cut that lowers s_sys pays for itself many times over:
σ_tot,set = s_sys ⊕ 1/√N_counts (⊕ 表示按平方相加)。(⊕ means addition in quadrature).
政策排名规则(C001 §2):先看一致性 —— 一个政策不许抬高 τ;在不动 τ 的政策里,σ_comb 更小者胜。单观测规则里的 ε 就取这一步量出的 τ。
The policy-ranking rule (C001 §2): consistency comes first — a policy may not raise τ; among the policies that do not, the smaller σ_comb wins. The ε of the single-observation rule is set to the τ that this step measures.
PI 的经验背景(D008):历史上 O VII 与 O VIII 线的误差大得让相邻观测完全不一致 —— 这正是"观测间系统误差压倒统计误差"的实例,也是 C001 想压制的对象。
The PI's background (D008): historically the O VII and O VIII line errors were so large that adjacent observations did not agree at all — exactly the "between-observation systematics overwhelm statistics" case that C001 is meant to suppress.
prereg/C001_error_budget_criterion.md §2, §2b (定义与排名规则)(definitions and ranking rule); 04_DECISION_LOG.md D007, D008.3. 快速看一眼 v1(描述性)3. Quick look v1 (descriptive)
scripts/c001_error_budget_quicklook.py 用 P001 收据(1.000–2.395 keV 窗口连续谱 C_K)做了第一遍扫(描述性)。CDFS 是 34 次观测看同一片天;M31 各指向看的天不同,所以 M31 的多观测数不是一致性检验。
scripts/c001_error_budget_quicklook.py used the P001 receipts (the 1.000–2.395 keV window continuum C_K) for a first pass (descriptive). CDFS is 34 observations of the same sky; M31's pointings see different sky, so its multi-observation numbers are not a consistency test.
| 问题Question | 答案(CDFS,来源 c001_quicklook.json)Answer (CDFS, from c001_quicklook.json) |
|---|---|
| 单观测:相对误差最优候选能赚多少?Single observation: how much can the error-optimal candidate gain? | 几乎不多:σ_tot(2.filter)/σ_tot(最优) 的中位数在 ε = 0–0.10 上只有 1.00–1.05(最大 1.04–1.19 CDFS、1.05–1.26 M31 MOS2);最优保留率中位数从 f_T = 0.8(ε = 0)移到 0.3(ε = 0.10)。Little: the median of σ_tot(2.filter)/σ_tot(optimal) is only 1.00–1.05 over ε = 0–0.10 (max 1.04–1.19 CDFS, 1.05–1.26 M31 MOS2); the optimal retention moves from a median f_T = 0.8 (ε = 0) to 0.3 (ε = 0.10). |
| 多观测:一致性(τ)Multi-observation: consistency (τ) | 合并统计误差 0.14%(MOS2),但超额散布 τ:2.filter 15.0%(M2)/ 13.0%(M1);每观测误差最优(ε = 0.01–0.10)14.5–15.2% / 12.5–13.1%;固定率排名 f_T = 0.3–0.4 → 15% / 13%,f_T = 0.6 → 28% / 35%,f_T = 0.8 → 71% / 78%;完全不切 → 86% / 92%。结论:按观测自适应是必需的;在此之外,GTI 选择几乎不动一致性。The combined statistical error is 0.14% (MOS2), but the excess scatter τ: 2.filter 15.0% (M2) / 13.0% (M1); per-observation error-optimal (ε = 0.01–0.10) 14.5–15.2% / 12.5–13.1%; fixed rate-rank f_T = 0.3–0.4 → 15% / 13%, f_T = 0.6 → 28% / 35%, f_T = 0.8 → 71% / 78%; no cut at all → 86% / 92%. Conclusion: adapting to each observation is essential; beyond that, the GTI choice barely moves the consistency. |
| 那 15% 是什么?What is that 15%? | 主要是粒子本底,不是 GTI:C_K 跟随角落率 Q_K(Spearman ρ = 0.91 / 0.88),Q 从 2001 纪元(0108…)到 2009–10 纪元(0555…、0604…)几乎翻倍;一个线性角落项把散布降到 5.8% / 6.5%。剩下的 ~6% 是 GTI 还能碰的地板(含未解析的 CXB 与稳态软质子地板)。Mostly particle background, not the GTI: C_K tracks the corner rate Q_K (Spearman ρ = 0.91 / 0.88), and Q nearly doubles from the 2001 epoch (0108…) to the 2009–10 epochs (0555…, 0604…); a linear corner term cuts the scatter to 5.8% / 6.5%. The remaining ~6% is the floor a GTI policy could still touch (it includes the unresolved CXB and the steady soft-proton floor). |
推论:比较政策要在扣除 QPB 之后的一致性(C_K − k·Q_K)上做 —— 这就是 C1(§5)。
Consequence: policies must be compared on the consistency after QPB subtraction (C_K − k·Q_K) — that is C1 (§5).
results/c001_quicklook/c001_quicklook.json; prereg/C001_error_budget_criterion.md §3; 04_DECISION_LOG.md D007 (描述性)(descriptive).4. v2:拼接光变曲线(0.5–2 keV,D008)4. v2: concatenated light curves (0.5–2 keV, D008)
PI 的两条细化(D008):系统误差在全部光变曲线拼接后计算(像把观测首尾相接播一遍),它不随观测数下降;目标能段定为 0.5–2.0 keV。固定保留率切割不是真政策 —— 有的观测干净时间不足一半。scripts/c001_concat_systematic.py 的结果(100 s cell、活时间 ≥ 50 s、FOV 事件、FLAG = 0、PATTERN ≤ 12、含点源;s_sys 拆成"观测内"与"观测间"两部分):
Two refinements from the PI (D008): the systematic is computed on all light curves concatenated (as if the observations were played one after another), and it does not fall with the number of observations; the target band is 0.5–2.0 keV. Fixed-fraction cuts are not a real policy — some observations have less than half of their time clean. Results from scripts/c001_concat_systematic.py (100 s cells, live ≥ 50 s, FOV events, FLAG = 0, PATTERN ≤ 12, point sources included; s_sys split into a "within" and a "between" part):
| 集Set | 政策Policy | 活时间Live | s_sys | 观测内within | 观测间between | s_stat |
|---|---|---|---|---|---|---|
| M31 MOS2, 30 | none | 529 ks | 170% | 157% | 67% | 0.12% |
| 2.filter | 407 ks | 18.0% | 11.7% | 13.6% | 0.18% | |
| 2.1.filter (历史)(historical) | 344 ks | 215% | 191% | 100% | 0.16% | |
| M31 MOS1, 30 | none | 526 ks | 137% | 126% | 54% | 0.14% |
| 2.filter | 389 ks | 25.3% | 12.7% | 21.9% | 0.23% | |
| 2.1.filter (历史)(historical) | 353 ks | 107% | 84% | 66% | 0.20% | |
| CDFS MOS2, 34 | none | 3291 ks | 210% | 205% | 44% | 0.04% |
| 2.filter | 2547 ks | 18.0% | 11.4% | 13.9% | 0.08% | |
| CDFS MOS1, 34 | none | 3291 ks | 206% | 201% | 44% | 0.05% |
| 2.filter | 2474 ks | 16.6% | 11.1% | 12.3% | 0.09% |
CDFS 没有 2.1.filter 产物(P001 还原用 mode B,2.1.filter = no)。历史的 M31 2.1.filter 在一些观测上灾难性失败:在重耀斑观测上完全不切(MOS2: 0800732401、2501、3001;MOS1: 0800731201、1401、1801、2901、3101),在另一些上几乎切光(剩 0.1–2.9 ks;MOS2: 0800731201、1401、1801、3101、2601、2701;MOS1: 0800730101、2401)。这与 2026-09-03 的遗留决定一致(2.1 GTI"被直接成员资格否定")。
CDFS has no 2.1.filter products (the P001 reduction ran mode B with 2.1.filter = no). The historical M31 2.1.filter fails catastrophically on some observations: it applies no cut at all on heavily flared observations (MOS2: 0800732401, 2501, 3001; MOS1: 0800731201, 1401, 1801, 2901, 3101), and cuts almost everything (0.1–2.9 ks left) on others (MOS2: 0800731201, 1401, 1801, 3101, 2601, 2701; MOS1: 0800730101, 2401). This matches the legacy decision of 2026-09-03 (the 2.1 GTI is "invalidated by direct membership").
读数:集级统计误差只有 0.04–0.2%,系统误差 17–25% —— 约大 100 倍。观测间部分(CDFS 12–14%)不随任何 GTI 选择改变,它按纪元跟随角落/QPB 水平,必须建模(QPB、软质子地板),不能靠筛。观测内部分(11–13%)才是滤波器能动的 —— 见 C1b(§6)。
Reading: the set-level statistical error is 0.04–0.2% while the systematic is 17–25% — about 100× larger. The between-observation part (12–14% on CDFS) is untouched by any GTI choice; it tracks the corner/QPB level by epoch and must be modelled (QPB, the soft-proton floor), not filtered. The within-observation part (11–13%) is what a filter can move — see C1b (§6).
results/c001_concat/c001_concat.json; prereg/C001_error_budget_criterion.md §2b, §3b; 04_DECISION_LOG.md D008.5. C1:角落项拿走大部分观测间部分(D010)5. C1: the corner term removes most of the between-observation part (D010)
§3 的推论要落实:给拼接光变曲线拟合一个每观测的角落项。模型是 r_i = S + k·Q_j,其中 Q_j 是第 j 个观测自己的角落 2.5–8 keV 率(在保留 cell 上),S 与 k 用活时间加权最小二乘对全部拼接 cell 拟合。scripts/c001_corner_corrected.py 在 CDFS 主集(29 观测,0.5–2 keV,2.filter)上给出:
This puts §3's consequence into practice: fit a per-observation corner term to the concatenated light curve. The model is r_i = S + k·Q_j, where Q_j is observation j's own corner 2.5–8 keV rate over the retained cells; S and k are fitted by live-time-weighted least squares over all concatenated cells. scripts/c001_corner_corrected.py on the CDFS primary set (29 observations, 0.5–2 keV, 2.filter) gives:
| 相机,政策Camera, policy | k | s_sys 原始(内 / 间)raw (within / between) | s_sys 角落项后(内 / 间)after the corner term (within / between) | s_stat |
|---|---|---|---|---|
| MOS2, 2.filter (29 观测,2281 ks)(29 obs, 2281 ks) | 2.90 | 17.3% (11.8 / 12.6) | 12.5% (11.8 / 4.1) | 0.08% |
| MOS1, 2.filter (29 观测,2208 ks)(29 obs, 2208 ks) | 2.77 | 16.4% (11.6 / 11.5) | 12.1% (11.6 / 3.3) | 0.10% |
| MOS2, none | 3.39 | 210% (206 / 41) | 210% (206 / 41) | 0.05% |
| MOS1, none | 4.78 | 207% (202 / 41) | 206% (202 / 40) | 0.05% |
读数:每观测的角落(QPB)项把观测间部分从 ~12% 降到 3–4%。之后的主导项是 2.filter 留下的 ~12% 观测内变化 —— 这正是更好的观测内滤波器能砍的对象(§3b 里 2.1 的 1.6% 是循环的,见 §7)。C001 的排名从此有了具体目标:把观测内项压向 ~2% 而不抬高观测间项;曝光代价在这个统计量级(s_stat ~0.1%)上无关紧要。
Reading: a per-observation corner (QPB) term takes the between-observation part from ~12% to 3–4%. After that, the dominant systematic is the ~12% within-observation variability left by 2.filter — exactly what a better in-observation filter can cut (the 1.6% of the working 2.1 subset in §3b is circular; see §7). The C001 ranking now has a concrete target: lower the within-observation term toward ~2% without raising the between-observation term; at these statistics (s_stat ~0.1%) the exposure cost is irrelevant.
results/c001_concat/c001_c1_corner_corrected.json; prereg/C001_error_budget_criterion.md §3c; 04_DECISION_LOG.md D010 (描述性)(descriptive).6. C1b:2.filter 内的不相交能段裁剪(探索性,D011)6. C1b: a disjoint-band clip inside 2.filter (exploratory, D011)
C1b(scripts/c001_c1b_inobs_filter.py,探索性、已消费数据)测试一族候选:在 2.filter 之内,把"选择能段率超过该观测宁静水平 μ0 + n·√(μ0/t)"的块切掉。块长 B = 300 或 1000 s;μ0 是 2.filter 块经迭代 2σ 裁剪后的活时间加权中位数。选择能段有两种:H = FOV 2.5–8 keV(与 0.5–2 keV 打分带不相交);S = 0.5–2 keV 事件的随机一半(二项减薄),在另一半上打分再互换。每个候选(含 2.filter)都在两条减薄半带上打分并取平均 —— 减薄给出两条独立的泊松流,在一半上选择不会污染另一半的超泊松散布。
C1b (scripts/c001_c1b_inobs_filter.py, exploratory, consumed data) tests a family of candidates: inside 2.filter, cut blocks whose selection-band rate exceeds the observation's quiescent level μ0 + n·√(μ0/t). Blocks are B = 300 or 1000 s; μ0 is the live-weighted median of the 2.filter blocks after iterative 2σ clipping. Two selection bands: H = FOV 2.5–8 keV (disjoint from the 0.5–2 keV score band); S = one random half of the 0.5–2 keV events (binomial thinning), scored on the other half and then swapped. Every candidate (2.filter included) is scored on both thinned half-band streams and the two excess variances averaged — thinning gives two independent Poisson streams, so selecting on one half does not bias the beyond-Poisson scatter measured on the other.
| 集Set | 2.filter:s_sys(内 / 间),活时间2.filter: s_sys (within / between), live | H, B = 300 s, n = 1 |
|---|---|---|
| CDFS MOS2 (角落修正)(corner-corrected) | 12.5% (11.8 / 4.1), 2281 ks | 6.1% (5.4 / 2.8), 1694 ks (−26%) |
| CDFS MOS1 (角落修正)(corner-corrected) | 12.0% (11.6 / 3.3), 2208 ks | 5.2% (4.7 / 2.1), 1628 ks (−26%) |
| M31 MOS2 (仅观测内)(within only) | 11.7%, 407 ks | 5.3%, 322 ks (−21%) |
| M31 MOS1 (角落修正)(corner-corrected) | 12.7%, 388 ks | 6.0%, 311 ks (−20%) |
三个读数:(1) 裁剪把观测内项在所有集上减半(11.6–12.7% → 4.7–6.0%,n = 1),代价 20–26% 活时间;观测间项不升高(CDFS 2.1–2.8%)。(2) H 与 S 一致(S 在 CDFS 上差 0.2–1.2 点)—— 2.filter 留下的 0.5–2 keV 变化同样出现在 2.5–8 keV,所以硬段裁剪就够,且保持选择与打分不相交。(3) 循环控制:同一批掩膜在它选择的那一半上打分,n = 1 时观测内项为 0.0%(n = 2 时 2.5–3.7%)—— 在打分带上做选择会"制造"一致性,这正是 2.1 发生的事(§7)。B = 300 s、n = 1 时没有观测保留不足 52% 的 2.filter 时间;B = 1000 s、n = 1 有 1–2 个观测低于 50%。
Three readings: (1) the clip halves the within-observation term on every set (11.6–12.7% → 4.7–6.0% at n = 1) at a 20–26% live-time cost; the between term does not rise (CDFS 2.1–2.8%). (2) H and S agree (S is 0.2–1.2 points worse on CDFS) — the variability 2.filter leaves in 0.5–2 keV is seen equally in 2.5–8 keV, so a hard-band clip suffices and keeps selection and scoring disjoint. (3) The circular control: the same masks scored on the half they were selected on give a within term of 0.0% at n = 1 (2.5–3.7% at n = 2) — selecting on the score band manufactures consistency, which is what happened to 2.1 (§7). With B = 300 s, n = 1 no observation keeps less than 52% of its 2.filter time; B = 1000 s, n = 1 has 1–2 observations below 50%.
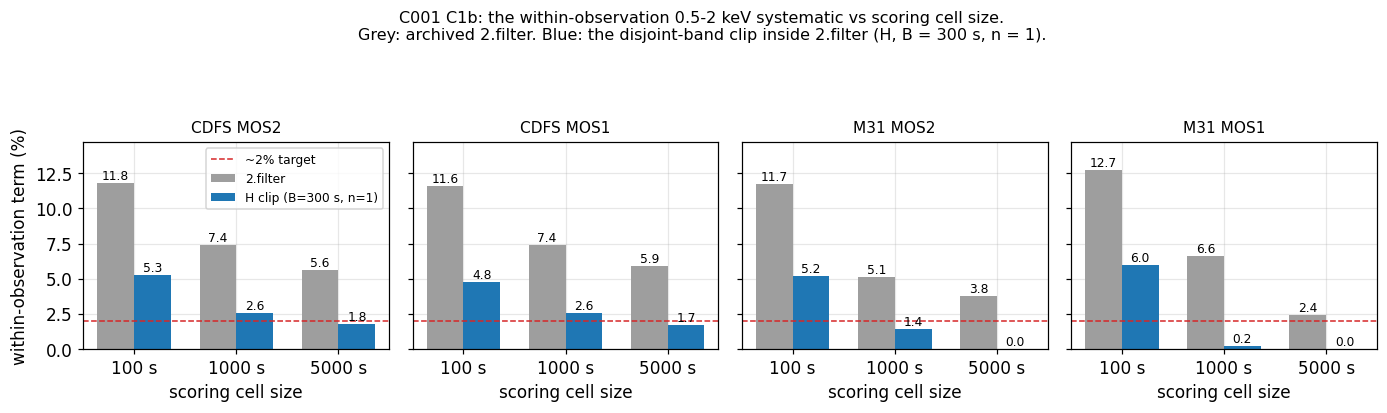
results/c001_c1b/diagnostics.txt (E005 §4 的表)(the table in E005 §4); cognition-os/experiments/E005_c001_c1b_inobs_filter.md.
results/c001_c1b/c001_c1b.json; results/c001_c1b/diagnostics.txt; prereg/C001_error_budget_criterion.md §3d; cognition-os/experiments/E005_c001_c1b_inobs_filter.md; 04_DECISION_LOG.md D011 (探索性)(exploratory).7. 被撤回的"1.6%"(D011)7. The withdrawn "1.6%" (D011)
§4 的表里有一处曾被写成目标:在"能工作的" M31 MOS2 27 观测子集上,历史 2.1.filter 的观测内项是 1.6%(2.filter 是 10.5%),活时间少 23%。这看起来像"更严的观测内滤波器几乎能清空观测内变化"。这个说法已被撤回(D011),理由是循环:
One number in §4's table was once treated as a target: on the "working" 27-observation M31 MOS2 subset, the historical 2.1.filter has a within-observation term of 1.6% (against 10.5% for 2.filter) at 23% less live time. That looked like "a stricter in-observation filter removes almost all within-observation variability". The claim has been withdrawn (D011), because it is circular:
- 历史 2.1.filter 在 0.2–10 keV 全探测器光变曲线上选择 —— 这个能段包含 0.5–2 keV 打分带。在选择所用的同一批事件上打分,超泊松散布自然被压低:C1b 的循环控制显示,这种"选择+打分同带"在 n = 1 时把观测内项打到 0.0%。The historical 2.1.filter selects on the 0.2–10 keV all-detector light curve — a band that contains the 0.5–2 keV score band. Scoring on the same events the selection used naturally suppresses the beyond-Poisson scatter: C1b's circular control shows this "select and score on the same band" drives the within term to 0.0% at n = 1.
- 诚实的对照:在选择能段之外打分(硬段 H)或在减薄后的另一半上打分(S),结果一致(§6 读数 2)—— 真实的观测内项是 ~5%(100 s),不是 1.6%。The honest control: score outside the selection band (hard band H) or on the other thinned half (S); both agree (§6 reading 2) — the real within term is ~5% (at 100 s), not 1.6%.
教训(进 PITFALLS):打分带必须与选择带不相交(或把事件减薄成两半、在没用过的那半上打分)。选择与打分同带会无声地自我实现。
The lesson (now in PITFALLS): the score band must be disjoint from the selection band (or thin the events into two halves and score on the half not used). Selecting and scoring on the same band silently makes the gate self-fulfilling.
prereg/C001_error_budget_criterion.md §3b (删除线)与 §3d(撤回理由)(the strikethrough) and §3d (the reason); cognition-os/experiments/E005_c001_c1b_inobs_filter.md §3; cognition-os/PITFALLS.md; 04_DECISION_LOG.md D011.8. cell 尺寸与快速残差(D012,探索性)8. Cell size and the fast residual (D012, exploratory)
C1b 之后还剩一个问题:C001 在多大的打分 cell 上算观测内项?100 s 上裁剪后仍有 ~5%,≥ 1000 s 只剩 0–2.6%。PI 把这个选择委托给 Claude("时间切片长度你自己定…随时可以切换",2026-10-14),Claude 用实验回答(scripts/c001_cellsize.py 等,探索性):
One question remained after C1b: at what scoring cell size should C001 evaluate the within term? After the clip ~5% survives at 100 s, 0–2.6% at ≥ 1000 s. The PI delegated the choice to Claude ("you decide the time-slice length… it can be switched at any time", 2026-10-14), and Claude answered it by experiment (scripts/c001_cellsize.py and friends, exploratory):
- 决定:C001 主打分用 1000 s cell(活时间 ≥ 500 s);100 s 与 3000 s 作为诊断一并报告。理由:CDFS 上政策排名在 100 / 300 / 3000 s 与 1000 s 一致(Spearman ρ = 0.93–1.0);1000 s 长到让几十秒尺度的成分几乎不贡献,又短到观测内项仍可测(CDFS 每观测保留 16–85 ks,M31 中位数约 11 个 cell);脚本把 cell 尺寸当常数,重打分只要几秒 —— 随时可切换。Decision: the C001 primary score uses 1000 s cells (≥ 500 s live); 100 s and 3000 s are reported as diagnostics. Reasons: on CDFS the policy ranking at 100 / 300 / 3000 s matches the ranking at 1000 s (Spearman ρ = 0.93–1.0); 1000 s is long enough that the tens-of-seconds component contributes little, yet short enough that the within term stays measurable (a CDFS observation keeps 16–85 ks; an M31 observation a median of about 11 cells); the scripts take the cell size as a constant and rescoring takes seconds — switchable at any time.
- 100 s 残差是真实的率变化,不是计数噪声。Fano 因子 F(b)(0.5–2 keV 计数,裁剪后保留时间内):2.5 s 处 1.02–1.04(≈ 帧尺度无聚簇),100 s 处升到 1.11–1.19 —— 相关时间在几十秒以上。闪烁像素被排除(没有像素满足清洗规则,F 不变)。角落计数同样超泊松(1.06–1.09)—— 粒子(和/或软质子)起源合理但未证明。只留 2.filter 时 F 在 100 s 达 1.9–2.0。The 100 s residual is real rate variability, not counting noise. The Fano factor F(b) of 0.5–2 keV counts in the clip's kept time: 1.02–1.04 at 2.5 s (no clustering at the frame scale), rising to 1.11–1.19 at 100 s — a correlation time of tens of seconds or more. Flickering pixels are excluded (no pixel met the cleaning rule, F unchanged). The corner counts are super-Poisson too (1.06–1.09) — a particle (and/or soft-proton) origin is plausible but not shown. With 2.filter alone F reaches 1.9–2.0 at 100 s.
- 在 1000 s 上,角落修正后的 CDFS s_sys:2.filter 8.4% / 8.0%(MOS2 / MOS1),裁剪 3.7% / 3.2%。At 1000 s the corner-corrected CDFS s_sys is 8.4% / 8.0% for 2.filter (MOS2 / MOS1) and 3.7% / 3.2% for the clip.
这个快速"白"成分会从任何谱中平均掉(谱只看每观测的均值),它的起源仍未测 —— 两个候选:仪器事件聚簇,或裁剪阈值以下的快速软质子闪烁(检验方法:对只有粒子能到达的未曝光角落 0.5–2 keV 事件算同一统计量)。
This fast "white" component averages out of any spectrum (a spectrum sees each observation's mean), and its origin is untested — two candidates: instrumental event clustering, or fast soft-proton flicker below the clip threshold (a test: the same statistic on unexposed-corner 0.5–2 keV events, which only particles reach).
results/c001_cellsize/c001_cellsize.json, diagnostics.txt; cognition-os/experiments/E006_c001_cell_size.md; prereg/C001_error_budget_criterion.md §3e; 04_DECISION_LOG.md D012 (探索性)(exploratory).9. 冻结与 Lockman Hole 检验(C001 §3e,D012)9. The freeze and the Lockman Hole test (C001 §3e, D012)
C1b 是在已消费的 CDFS/M31 上选出来的,所以在它成为政策之前必须冻结、再到新鲜场上检验。已冻结的内容(D012):
C1b was chosen on consumed CDFS/M31 data, so before it becomes a policy it must be frozen and then tested on a fresh field. What is frozen (D012):
- 政策 B(冻结):H 裁剪,B = 300 s、n = 1,在 2.filter 之内。块长 300 s;选择能段 FOV 2.5–8 keV;μ0 = 2.filter 块在迭代 2σ 裁剪后的活时间加权中位数;保留条件 r ≤ μ0 + 1·√(μ0/t)。它比 B = 1000 s 的分数只差 0.1–0.2 点,却多保留 6–8% 时间,且没有观测低于其 2.filter 时间的 50%。政策 A = 归档 2.filter。Policy B (frozen): the H clip, B = 300 s, n = 1, inside 2.filter. Blocks of 300 s; selection band FOV 2.5–8 keV; μ0 = the live-weighted median of the 2.filter blocks after iterative 2σ clipping; keep a block if r ≤ μ0 + 1·√(μ0/t). Its score is within 0.1–0.2 points of B = 1000 s while keeping 6–8% more time, with no observation below 50% of its 2.filter time. Policy A = the archived 2.filter.
- 检验场:Lockman Hole(也是 P002 复制 2,见 §10–11)—— 用 CDFS 配方新鲜还原、MOS1 与 MOS2 分开,由 PI 稍后派发(D011"后面再派",不预设日期)。同一次还原同时打分政策 B 与 P002 F2。Test field: the Lockman Hole (also P002's replication 2; see §10–11) — freshly reduced with the CDFS recipe, MOS1 and MOS2 separately, dispatched later by the PI (D011; no date invented). The same reduction scores both policy B and P002 F2.
- 打分与不确定度:拼接 0.5–2 keV、1000 s cell、每观测角落项(C1 模型):s_sys、观测内、观测间与活时间;不确定度用观测上的配对 bootstrap(2000 次抽样,种子 20261014)。代码
scripts/c001_frozen_test.py(--camera --roots --exclude --label --out)。任何 ObsID 排除都在打分前由元数据固定。Scoring and uncertainty: concatenated 0.5–2 keV, 1000 s cells, per-observation corner term (the C1 model): s_sys, within, between and live time; uncertainty by paired bootstrap over observations (2000 draws, seed 20261014). Code:scripts/c001_frozen_test.py(--camera --roots --exclude --label --out). Any ObsID exclusion is fixed from metadata before scoring.
成功判据(预注册):Δs_sys = s_sys(B) − s_sys(A) < 0 且其 95% bootstrap 上界 < 0,并且观测间项不升高(Δbetween 上界 < +1 点)。Δs_sys 区间含 0 → 持平;Δs_sys > 0 或观测间项升高 → 失败。100 s 与 3000 s 分数、保留不足 2.filter 时间 50% 的观测 —— 只报告,不参与判定。
Success criterion (pre-registered): Δs_sys = s_sys(B) − s_sys(A) < 0 with its 95% bootstrap upper bound < 0, and the between term does not rise (upper bound of Δbetween < +1 point). If the Δs_sys interval contains 0 → no significant difference; failure if Δs_sys > 0 or the between term rises. The 100 s and 3000 s scores and observations keeping < 50% of their 2.filter time are reported but do not gate.
工程干跑(不是证据):在已消费的 CDFS 上(裁剪正是在这批数据上选的)干跑复现了 E006(MOS2 8.4% → 3.7%、MOS1 8.0% → 3.2%),Δs_sys 的 95% 区间 [−5.8, −3.7] 与 [−6.5, −3.2] 点,判定 SUCCESS。产物 results/c001_cellsize/frozen_test_cdfs_dryrun_M{1,2}.json。它只证明管线跑得通,不构成对新场的证据。
Engineering dry run (not evidence): on consumed CDFS (the very data the clip was chosen on) the dry run reproduces E006 (MOS2 8.4% → 3.7%, MOS1 8.0% → 3.2%), Δs_sys 95% intervals [−5.8, −3.7] and [−6.5, −3.2] points, verdict SUCCESS. Outputs: results/c001_cellsize/frozen_test_cdfs_dryrun_M{1,2}.json. It proves only that the pipeline runs; it is not evidence for a fresh field.
冻结记录:commit abc5e602dbbb3ffdcb937f34a993363d3267334f;sha256:scripts/c001_frozen_test.py = 3026dbad…,scripts/c001_c1b_inobs_filter.py = 13f8a6ff…;它导入的加载器是冻结的 P001 代码。C2(谱)仍是排名的最终检验(PI:C2 等 P002)。
Freeze record: commit abc5e602dbbb3ffdcb937f34a993363d3267334f; sha256: scripts/c001_frozen_test.py = 3026dbad…, scripts/c001_c1b_inobs_filter.py = 13f8a6ff…; the loader it imports is the frozen P001 code. C2 (spectra) remains the final check of the ranking (PI: C2 waits for P002).
prereg/C001_error_budget_criterion.md §3e; results/c001_cellsize/frozen_test_cdfs_dryrun_M1.json, frozen_test_cdfs_dryrun_M2.json; 04_DECISION_LOG.md D011, D012; 00_AI_BRIEFING.md §Next steps 3.10. P002:问题与冻结方法(D007–D009)10. P002: the question and the frozen method (D007-D009)
问题。仪器 Al-K 荧光线(1.4879 keV)是粒子打相机激发出来的;未曝光角落的 2.5–8 keV 率 Q 是粒子水平的监测器。若 Al 线随粒子水平比例变化,则 L ∝ Q(斜率 b = 1,"跟随");若不变,则 b = 0("稳定")。这决定 P001 线门(假设 L_K = L_B)是否成立:只有粒子水平在保留/删除时间之间不变时它才对。
The question. The instrumental Al-K fluorescence line (1.4879 keV) is excited by particles hitting the camera; the unexposed-corner 2.5–8 keV rate Q monitors the particle level. If the Al line scales with the particle level, L ∝ Q (slope b = 1, "tracks"); if not, b = 0 ("steady"). This decides whether the P001 line gate (which assumes L_K = L_B) is justified: it holds only if the particle level does not change between kept and rejected time.
动机(探索性,不是证据)。CDFS 叠加(E003):观测内 ln(Q_K/Q_B) = −0.019 ± 0.004(MOS1)与 −0.039 ± 0.004(MOS2)—— 被删时间的粒子水平高 2–4%;而门内 ln(L_K/L_B) = +0.006 ± 0.006 与 +0.013 ± 0.006 —— 方向相反。表面上看这偏向 b ≈ 0(或线测量有 K/B 系统误差)。但没人算过观测之间的 Al–Q 关系,而 Q 从 2001 到 2009–10 几乎翻倍 —— 杠杆臂很大。这正是 P002 要测的。
Motivation (exploratory, not evidence). CDFS stacks (E003): within observations ln(Q_K/Q_B) = −0.019 ± 0.004 (MOS1) and −0.039 ± 0.004 (MOS2) — rejected time has a 2–4% higher particle level; yet the as-gated ln(L_K/L_B) = +0.006 ± 0.006 and +0.013 ± 0.006 — the opposite way. Taken at face value these favour b ≈ 0 (or a K/B systematic in the line measurement). But nobody had computed the between-observation Al–Q relation, and Q nearly doubles from 2001 to 2009–10 — a large lever arm. That is what P002 measures.
冻结的方法(§4 与 §8,代码冻结 1eb687b 之后才算任何结果):
The frozen method (§4 and §8; no outcome computed before the code freeze at 1eb687b):
- 不重新拟合。每个数都来自 P001 收据:y = ln L_Al,K(Al 线率,σ 来自 Cash ΔC = 1 剖面),x = ln Q_K(角落率,泊松误差 σ = 1/√N_K)。No refit. Every number comes from the P001 receipts: y = ln L_Al,K (the Al line rate, σ from the Cash ΔC = 1 profile), x = ln Q_K (the corner rate, Poisson error σ = 1/√N_K).
- 双变量误差回归(Deming 型):最大似然,有效方差 σ_y² + b²σ_x² + s²,内在散布 s ≥ 0 一起拟合。每个 MOS1 CCD 构型一个自由截距(构型由 DATE-OBS 定:2005-03-09 前全 CCD;2012-12-11 前无 CCD6;之后无 CCD3 与 CCD6;MOS2 单构型)。Errors-in-both-variables (Deming-type) regression: maximum likelihood with effective variance σ_y² + b²σ_x² + s², the intrinsic scatter s ≥ 0 fitted too. One free offset per MOS1 CCD configuration (dated from DATE-OBS: all CCDs before 2005-03-09; without CCD6 until 2012-12-11; without CCD3 and CCD6 after; MOS2 has a single configuration).
- σ_b = 剖面似然区间(−2ΔlnL = 1)的半宽;σ_b > 0.25 → TOO_NOISY。判定顺序:TOO_NOISY → TRACKS(|b − 1| < 2σ_b 且 b/σ_b > 3)→ STEADY(|b| < 2σ_b 且 (1−b)/σ_b > 3)→ 否则 INTERMEDIATE。精度要求 σ_b ≤ 0.25。σ_b is the half-width of the profile-likelihood interval (−2ΔlnL = 1); σ_b > 0.25 → TOO_NOISY. Verdict order: TOO_NOISY → TRACKS (|b − 1| < 2σ_b and b/σ_b > 3) → STEADY (|b| < 2σ_b and (1−b)/σ_b > 3) → otherwise INTERMEDIATE. Precision requirement: σ_b ≤ 0.25.
- 终点:F1(主)= 观测之间的斜率 b,按相机与场;F2(仅复制场)= 观测之内的叠加 ln(L_K/L_B) − ln(Q_K/Q_B);F3(描述性)= 若 F1 与已见的 CDFS 叠加冲突,记录冲突并指向线测量的 K/B 系统误差(T005 处置)。Endpoints: F1 (primary) = the slope b between observations, per camera and field; F2 (replication field only) = the stacked ln(L_K/L_B) − ln(Q_K/Q_B) within observations; F3 (descriptive) = if F1 conflicts with the seen CDFS stacks, record the conflict and point to a K/B systematic in the line measurement (the T005 disposition).
- 集:CDFS 主集(29 ObsID/相机,排除 0108060601、0108060701、0555780501、0604960501、0604961301);复制 1 = M31 080073*01(两相机,F1);复制 2 = Lockman Hole(新鲜、盲,F1 与 F2 都可)。CDFS MOS2 是主集。代码只用合成输入测试(自测恢复 b = 1、0、0.5 与三构型 b = 1,判定全对)。Sets: CDFS primary (29 ObsIDs per camera; 0108060601, 0108060701, 0555780501, 0604960501, 0604961301 excluded); replication 1 = M31 080073*01 (both cameras, F1); replication 2 = the Lockman Hole (fresh, blind, both F1 and F2). CDFS MOS2 is the primary set. The code was tested on synthetic inputs only (the self-test recovers b = 1, 0, 0.5 and b = 1 with three configurations, every verdict correct).
prereg/P002_al_line_vs_corner.md §1–§8; 04_DECISION_LOG.md D007–D009 (PI 批准"同意";冻结 commit 1eb687b…)(PI approved; frozen commit 1eb687b…).11. P002 F1 结果与解读(E004,冻结后运行)11. P002 F1 results and reading (E004, run after the freeze)
冻结代码(1eb687b)先跑 CDFS、再跑 M31;输入只有 P001 收据,没有重新拟合任何谱。F1 按预注册判定:
The frozen code (1eb687b) ran on CDFS first, then M31; the inputs are P001 receipts only, no spectrum refitted. F1 verdicts as pre-registered:
| 集(角色)Set (role) | n | b ± σ_b | 内在散布Intrinsic scatter | Q 范围(max/min)Q range (max/min) | 判定Verdict |
|---|---|---|---|---|---|
| CDFS MOS2(主集)CDFS MOS2 (primary) | 29 | 1.015 ± 0.030 | 0.045 | 2.16 | TRACKS |
| CDFS MOS1 (次级;3 个 CCD 构型截距)(secondary; 3 CCD-configuration offsets) | 29 | 0.588 ± 0.020 | 0.023 | 2.24 | INTERMEDIATE |
| M31 MOS2 (复制 1)(replication 1) | 30 | 0.602 ± 0.070 | 0.023 | 1.46 | INTERMEDIATE |
| M31 MOS1 (复制 1)(replication 1) | 30 | 0.694 ± 0.050 | 0.037 | 2.34 | INTERMEDIATE |
没有观测被剔除。中位 σ(ln L) 与 σ(ln Q):CDFS 0.008–0.010,M31 0.022–0.030。
No observation was dropped. Median σ(ln L) and σ(ln Q): 0.008–0.010 on CDFS, 0.022–0.030 on M31.
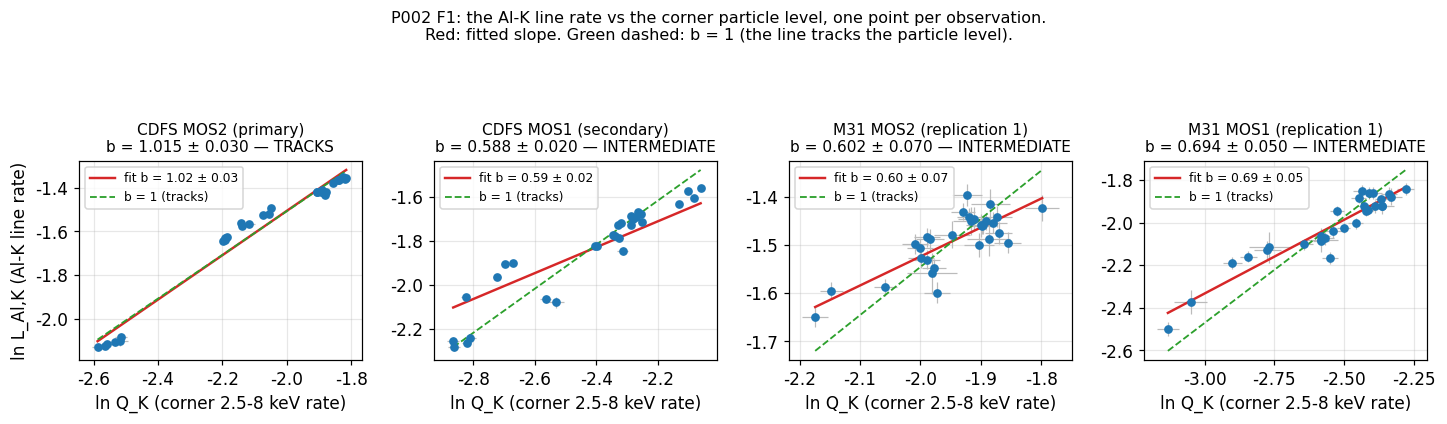
results/p002/p002_f1_cdfs.json; results/p002/p002_f1_m31.json (每集的 points 与拟合)(points and fit per set).
§6 解读:主集达到终点(b = 1.02 ± 0.03,横跨 2.2 倍的 Q 范围,2001–2019),但复制 1 不确认 —— 三个复制集都是 b = 0.6–0.7、测量精确、且离 0 与 1 都远。按预注册的 §6,"Al 线是粒子监测器"需要主集和复制都成立,所以它未在一般意义上确立;这个关系只在 CDFS MOS2 上成立。F3(描述性):CDFS MOS2 上线在观测之间跟随 Q、观测之内的 K/B 线叠加却不跟随(门内 +0.013 ± 0.006 对角落 −0.039 ± 0.004)—— 冲突指向线测量里的 K/B 系统误差,这是 T005 在 MOS2 上的主要处置;P001 线门(L_K = L_B)作为粒子锚仍未被验证。F2(观测之内)留给 Lockman Hole。
§6 reading: the primary endpoint is met (b = 1.02 ± 0.03 over a factor-2.2 range in Q, 2001–2019), but replication 1 does not confirm it — all three replication sets give b = 0.6–0.7, measured precisely and clearly away from both 0 and 1. Under the pre-registered §6, "the Al line is a particle monitor" needs the primary set and the replication, so it is not established in general; the relation holds for CDFS MOS2 only. F3 (descriptive): on CDFS MOS2 the line follows Q between observations, but the within-observation K/B line stacks do not (as gated +0.013 ± 0.006 against the corner −0.039 ± 0.004) — the conflict points to a K/B systematic in the line measurement, the leading T005 disposition for MOS2; the P001 line gate (L_K = L_B) stays unvalidated as a particle anchor. F2 (within observations) waits for the Lockman Hole.
未测的候选解释(b ≈ 0.6–0.7 的成因,全部标注"未测",需要自己的预注册):MOS1 角落几何与 CCD 损失(CDFS MOS1 主要在一个构型里,其截距吸收了部分杠杆臂);M31 的天空在 1.49 keV 有贡献(L = L_particle + L_sky 稀释斜率);M31 MOS2 杠杆臂短(Q 范围 1.46);角落率里有一个不激发 Al 的 Q 依赖成分。这些都没有被检验过。
Untested candidate explanations for b ≈ 0.6–0.7 (all labelled untested; they need their own pre-registration): MOS1 corner geometry and the CCD losses (CDFS MOS1 sits mostly in one configuration, and its offsets absorb part of the lever arm); the M31 sky can contribute at 1.49 keV (L = L_particle + L_sky dilutes the slope); the M31 MOS2 lever arm is short (Q range 1.46); a Q-dependent part of the corner rate that does not excite Al. None of these has been examined.
prereg/P002_al_line_vs_corner.md §9; cognition-os/experiments/E004_p002_al_vs_corner.md; results/p002/p002_f1_cdfs.json; results/p002/p002_f1_m31.json; 04_DECISION_LOG.md D009.12. 还缺什么(诚实清单)12. What is still missing (the honest list)
- C1b 未在新场验证。它是从已消费的 CDFS/M31 上选的;Lockman Hole 干跑(§9)只证明管线工作。真正的检验是一次新鲜的 Lockman Hole 还原(PI 派发,日期未定),同一次还原同时打分冻结滤波器与 P002 F2。C1b is not validated on a fresh field. It was chosen on consumed CDFS/M31; the Lockman Hole dry run (§9) proves only that the pipeline works. The real test is one fresh Lockman Hole reduction (PI dispatches it; no date), scoring both the frozen filter and P002 F2 on the same data.
- C2(谱验证)还没做。C001 的快速判据最终要用光谱一致性检验:把 C1 里最好的 2–3 个政策与 2.filter 用到 MosaicSelfCal CDFS 金/银 cell 上,按 LHB 与 halo 归一化的 τ 打分,再上 M31CGM;成功 = 快速排名与谱 τ 排名一致。PI 决定:C2 等 P002(D008)。C2 (spectral validation) has not been run. C001's quick criterion must finally be checked against spectral consistency: apply the 2–3 best C1 policies and 2.filter to the MosaicSelfCal CDFS golden/silver cells, score the τ of the LHB and halo normalisations, then M31CGM; success = the quick-metric ranking matches the spectral-τ ranking. PI decision: C2 waits for P002 (D008).
- P002 复制未确认。主集 TRACKS,复制 1 三个集都 INTERMEDIATE(b ≈ 0.6–0.7);b ≈ 0.6–0.7 的成因未测,需要自己的预注册。F2 等 Lockman Hole。The P002 replication does not confirm. The primary set TRACKS; all three replication-1 sets are INTERMEDIATE (b ≈ 0.6–0.7); the causes of b ≈ 0.6–0.7 are untested and need their own pre-registration. F2 waits for the Lockman Hole.
- 100 s 快速残差的起源未测。它是真实的率变化(Fano 证据,§8),不是计数噪声或闪烁像素;两个候选解释(事件聚簇、阈值下快速软质子闪烁)都没有检验。The origin of the 100 s fast residual is untested. It is real rate variability (the Fano evidence, §8), not counting noise or flickering pixels; neither candidate explanation (event clustering, fast soft-proton flicker below the threshold) has been tested.
- 观测间部分要建模,不是筛。角落项能拿走大部分(C1),但剩下的 3–4% 与稳态软质子地板属于 QPB/FWC 建模 —— 那是父项目(ESAS 合同)的工作,不在 GTI 的权限内。The between-observation part needs modelling, not filtering. The corner term removes most of it (C1), but the remaining 3–4% and the steady soft-proton floor belong to QPB/FWC modelling — the parent project's (ESAS contract) job, outside a GTI's remit.
00_AI_BRIEFING.md §Next steps; prereg/C001_error_budget_criterion.md §4; prereg/P002_al_line_vs_corner.md §6, §9; 04_DECISION_LOG.md D011, D012.