ParetoGTICal 工作台ParetoGTICal workbench
cognition-os/experiments/E003_p001_cdfs_blank_field.mdThis site was written before the CDFS blind run finished. P001 is now closed (D006): on CDFS, E1 is not evaluable (no zero control in the primary set), E2 passes, and E3 fails on both cameras (MOS1 24/29, Z = 1.55; MOS2 27/29, Z = 1.73; gain about 0.3%); the corner precision is σ = 0.0044 / 0.0038, usable. Wherever the text below says "CDFS pending", this note supersedes it; the next refresh updates the pages. Source: cognition-os/experiments/E003_p001_cdfs_blank_field.md这是什么项目? XMM-Newton 望远镜每次观测都会被软质子 (soft proton) 耀斑污染,必须用"好时间段 (good time interval, GTI)"把耀斑时间删掉。删多删少是一对矛盾:多删 → 剩下的数据更干净但更少;少删 → 数据多但更脏。ParetoGTICal 把这个取舍当作一个帕累托问题 (Pareto problem):在单次观测内部,用保留活时间 f_T 与连续谱约减因子 R = C_all/C_K 两个坐标给每个候选 GTI 打分,并用 Al-K、Si-K 荧光线的不变性做门 (gate),防止"挑噪声"伪装成"删耀斑"。它属于父项目 DiffuseXrayCalibration (校准 XMM EPIC 弥散发射分析),但有自己的问题、自己的认知操作系统 (cognition OS) 和自己的预注册 (pre-registration) 纪律。
What is this project? Every XMM-Newton observation is polluted by soft-proton flares, and "bad" time must be removed by keeping only good time intervals (GTIs). How much to cut is a genuine conflict: cut more and the retained data are cleaner but fewer; cut less and there are more data but dirtier ones. ParetoGTICal treats this trade-off as a Pareto problem: within one observation, every candidate GTI is scored by two coordinates — retained live time f_T and the continuum reduction factor R = C_all/C_K — with an Al-K / Si-K fluorescence-line stability gate that stops "selecting noise" from masquerading as "cutting flares". It is a sub-project of DiffuseXrayCalibration (calibrating the XMM EPIC diffuse-emission analysis), with its own question, its own cognition OS and its own pre-registration discipline.
四个问题,一屏作答Four questions, answered on one screen
- 现在在哪?
- Where does it stand?
- 预注册 P001 已批准、代码已冻结 (git 46d8df3),M31 MOS1 盲测已跑完:E1 通过、E2 通过、E3 失败(13/25,Z = 0.02)——率排名在相同保留率下并不比标准 2.filter 更好;角落 (corner) 在 MOS1 上太吵 (σ = 0.013 > 0.010)。CDFS 空白场盲测待定(stage-1/2 还原进行中)。
- Pre-registration P001 is approved and the code frozen (git 46d8df3); the blind M31 MOS1 run is complete: E1 PASS, E2 PASS, E3 FAIL (13/25, Z = 0.02) — rate-rank at equal retention is not better than the standard 2.filter; the unexposed corner is too noisy on MOS1 (σ = 0.013 > 0.010). The CDFS blank-field blind test is pending (stage-1/2 reduction in progress).
- 还有什么没解决?
- What is unsolved?
- ① CDFS 盲测(空白场对照);② 角落到底有没有用 (T017);③ 下游成功判据(曝光损失 ⇄ 连续谱增益的兑换率);④ 反事实耦合修正下的 Al 亏损 (−2.2σ, MOS2) 是粒子背景真变了还是未建模的系统误差。
- ① The CDFS blind test (blank-field control); ② whether the unexposed corner is useful at all (T017); ③ the downstream success criterion (the exchange rate between exposure loss and continuum gain); ④ whether the counterfactual coupling-corrected Al deficit (−2.2σ on MOS2) is a real particle-background change or an unmodelled systematic.
- 接下来做什么?
- What do I do next?
- 等 CDFS stage-1/2 还原完成后,用冻结的代码在 M1、M2 上跑盲测并评估 E1–E6;然后定角落的最终判决;然后定义下游成功判据。命令见"如何接手"页。
- When the CDFS stage-1/2 reduction finishes, run the blind test on M1 and M2 with the frozen code and evaluate E1–E6; then settle the corner verdict; then define the downstream success criterion. Commands are on the "By hand" page.
目标表(PI 工作单,D002,2026-10-13)Objectives (the PI's work order, D002, 2026-10-13)
| # | 目标Objective | 状态Status | 最好的当前数字(来源)Best current number (source) | 趋势Trend |
|---|---|---|---|---|
| 1 | 事实纠错认知 OSFact-correct the cognition OS | DONE | D002 + I002:训练/保留集(19 训练、11 保留)2026-09-14 已冻结且已消费;两个度量族 R 与 G_Al;数据是 M31 MOS2 不是 CDFS。D002 + I002: the train/holdout split (19 training, 11 holdout) was frozen and scored on 2026-09-14; two metric families R and G_Al exist; the data are M31 MOS2, not CDFS.
来源:Source: ParetoGTICal/cognition-os/04_DECISION_LOG.md (D002); insights/I002_historical_evidence_reconciliation.md |
→ |
| 2 | 扩展到 MOS1 + 空白场对照Extend to MOS1 + blank-field control | MOS1 已完成done / CDFS 待定pending | M31 MOS1 盲测:E1 通过 (0/78),E2 通过 (0 vs 0),E3 失败 (13/25,Z = 0.02),角落 σ = 0.013 → TOO_NOISY。CDFS:待定 (P001 CDFS 盲测尚未运行)。M31 MOS1 blind: E1 PASS (0/78), E2 PASS (0 vs 0), E3 FAIL (13/25, Z = 0.02), corner σ = 0.013 → TOO_NOISY. CDFS: pending (P001 CDFS blind test not yet run).
results/p001_m31_mos1/p001_endpoints_m31.json; cognition-os/experiments/E002_p001_m31_mos1.md |
→ |
| 3 | 定义下游成功判据Define the downstream success criterion | 待定PENDING | 尚无数字。它要回答:1% 的活时间值多少连续谱约减?由父项目的响应折叠弥散天空拟合给出。E3 失败后,这个问题变成"选哪个保留率",而非"选哪个时间"。No number yet. It must answer: how much continuum reduction is 1% of live time worth? Given by the parent project's response-folded diffuse-sky fit. After E3 failed, this becomes "which retention to choose", not "which time to keep".
ParetoGTICal/cognition-os/00_AI_BRIEFING.md §Next steps (D002 step 3); 04_DECISION_LOG.md D005 |
→ |
| 4 | 开放问题:未曝光角落有没有用?Open question: is the unexposed corner useful? | PARTLY TESTED | MOS1 叠加 σ = 0.0133 > 0.010 → TOO_NOISY;MOS2 参考 σ = 0.0098 → 勉强 USABLE;两台相机都看不到 K/B 角落差 (−0.008 ± 0.013, −0.003 ± 0.010)。最终判决等 CDFS。MOS1 stacked σ = 0.0133 > 0.010 → TOO_NOISY; MOS2 reference σ = 0.0098 → USABLE by a hair; neither camera shows a K/B corner difference (−0.008 ± 0.013, −0.003 ± 0.010). Final verdict waits for CDFS.
results/p001_m31_mos1/p001_endpoints_m31.json (E5); 03_TRUST_TABLE.md T017 |
→ |
开放问题表Open problems
| 问题Problem | 为什么重要Why it matters | 当前最好的假设Best current hypothesis | 下一个检验Next test | 所有者 / 状态Owner / status |
|---|---|---|---|---|
| R 筛选在等保留率下是否优于归档 2.filter?Does the R screen beat the archived 2.filter at equal retention? | 这是 P001 的主要终点;若不优于,方法的全部价值就只剩"选保留率"这一层。This is P001's primary endpoint; if not, the method's whole value reduces to "choosing a retention". | 不优于:两台相机 Δ 都在噪声内(MOS1 13/25,Z=0.02;MOS2 21/29,Z=1.64,都不达阈值)。Not better: both cameras have Δ within noise (MOS1 13/25, Z = 0.02; MOS2 21/29, Z = 1.64; neither meets the thresholds). | CDFS 盲测(M1、M2,冻结代码,E1–E6)。The CDFS blind run (M1, M2, frozen code, E1–E6). | T019 / REFUTED on M31T019 / REFUTED on M31 |
| 反事实 Al 亏损(−0.028 ± 0.013, MOS2)是真信号吗?Is the counterfactual Al deficit (−0.028 ± 0.013, MOS2) real? | 若真,则 L_K = L_B 这个设计级约束本身有偏差;若假,则是未建模系统误差。它决定线门是否可信。If real, the design-level constraint L_K = L_B is itself biased; if not, it is an unmodelled systematic. It decides whether the line gate is trustworthy. | MOS1 不复现 (−0.004 ± 0.019,as gated +0.019 ± 0.019),提示它是 MOS2 特有或一次涨落,且依赖注入测得的耦合 s。It does not transfer to MOS1 (−0.004 ± 0.019 counterfactual; +0.019 ± 0.019 as gated), suggesting it is MOS2-specific or a fluctuation, and that it depends on the injection-derived coupling s. | CDFS 上的 E5;若 CDFS 也不出现,按 T005 关闭该问题。E5 on CDFS; if absent there too, close the issue per T005. | T005, T016 / QUESTIONEDT005, T016 / QUESTIONED |
| 角落能否预测 K/B 粒子级变化?Can the corner predict the K/B particle-level change? | 角落在 FOV 外、不经望远镜聚焦,是最干净的粒子监测器;若够准,就能直接检验"Al 亏损 = 粒子变化"。The corner is outside the FOV and receives no focused soft protons — the cleanest particle monitor; if precise enough it can test "Al deficit = particle change" directly. | 目前两台相机都测不出 ~1% 的 K/B 角落差;B1 曾有 +2.8% (z=1.7) 的边缘提示。Neither camera currently resolves a ~1% K/B corner difference; B1 once hinted at +2.8% (z = 1.7). | CDFS E5 角落叠加 σ 是否 ≤ 0.010。Whether the CDFS E5 corner stack σ is ≤ 0.010. | T017 / PARTLY TESTEDT017 / PARTLY TESTED |
| 被移除的成分是软质子还是可变天体源?Is the removed component soft protons or variable celestial sources? | 这是"删掉的东西到底是什么"的身份问题;M31 盘里有很多可变 X 射线双星,是天体源解释的真实竞争者。This is the identity question — what was actually removed; the M31 disk holds many variable X-ray binaries, a genuine celestial competitor. | A1:移除的超额 ~79% 无线 (Al −5.96σ);B1:空间延展、非紧凑,更像软质子花样;但仍不能排除多个微弱可变源。A1: the removed excess is ~79% line-free (Al −5.96σ); B1: extended, not compact — closer to the soft-proton pattern; many faint variable sources are not excluded. | CDFS 空白场 E6:若移除成分是软质子,耀斑 CDFS 观测的 R 增益应像 M31;若差异大,指向 M31 源。The CDFS blank field, E6: if the removed component is soft protons, R gains on flared CDFS observations should look like M31's; large differences point at M31 sources. | T009, T018 / NOT ESTABLISHEDT009, T018 / NOT ESTABLISHED |
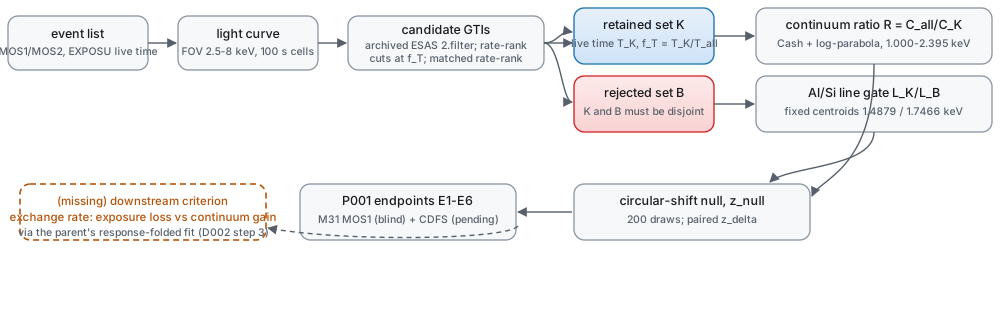
未来 1–4 周计划(按 PI 顺序与 P001 §9)Plan for the next 1–4 weeks (PI order and P001 §9)
- 等 CDFS stage-1/2 还原完成(codexnim 与 Hermes 各一半,作业 2026-10-13-pareto-cdfs-mos-filter),用冻结代码在 M1、M2 上跑
scripts/m31_mos2_line_continuum_invariant.py --field cdfs --camera M1|--camera M2,再用scripts/p001_endpoints.py评估 E1–E6。CDFS 结果待定。Wait for the CDFS stage-1/2 reduction to finish (codexnim and Hermes each on half, job 2026-10-13-pareto-cdfs-mos-filter), run the frozen code on M1 and M2 withscripts/m31_mos2_line_continuum_invariant.py --field cdfs --camera M1|--camera M2, then evaluate E1–E6 withscripts/p001_endpoints.py. CDFS results are pending. - 按 E5 的 CDFS 角落叠加 σ 给出 T017 的最终判决(可用 / 太吵)。Give the final T017 verdict (usable / too noisy) from the CDFS E5 corner stack σ.
- 定义下游成功判据(D002 第 3 步):在父项目的响应折叠拟合里,量化 1% 活时间损失对应多少连续谱增益,把 f_T–R 平面变成一个可决策的标量。E3 失败后,这成为"保留率政策"问题。Define the downstream success criterion (D002 step 3): in the parent project's response-folded fit, quantify how much continuum gain 1% of live time buys, turning the f_T–R plane into a decidable scalar. After E3 failed this becomes a "retention policy" question.
一分钟看懂核心矛盾(动画)The core conflict in one minute (animation)
光变曲线 + 阈值滑块 → GTI、f_T、保留计数实时更新Light curve + threshold slider → GTI, f_T and retained counts update live
拖动阈值:蓝色是保留的时间 K,红色是被删的 B。f_T 是保留活时间比例;R 用玩具模型模拟"删高率时间为什么会让 R>1"。
Drag the threshold: blue is kept time K, red is rejected B. f_T is the retained live-time fraction; R uses a toy model to show why cutting high-rate time gives R > 1.
本次更新What's new
2026-10-13(第一版):本手册随 ParetoGTICal 迁移入 DXC 后建立。覆盖 D001–D005 全部决策:P001 预注册批准 + 代码冻结 (46d8df3) + 回归门通过 (26,111 个数字,最大相对差 0),M31 MOS1 盲测完成 (E002)。CDFS P001 一切结果均为"待定"。
2026-10-13 (first edition):This handbook was built after ParetoGTICal migrated into DXC. It covers decisions D001–D005: P001 pre-registration approved + code frozen (46d8df3) + regression gate passed (26,111 numbers, max relative difference 0), and the blind M31 MOS1 run (E002) recorded. All CDFS P001 results are "pending".
数据截至Data as of
2026-10-13(所读最新来源:cognition-os/04_DECISION_LOG.md D005 与 06_AGENT_LOG.md 最后一行,均为 2026-10-13;E002 实验记录同日)。
2026-10-13 (newest sources read: cognition-os/04_DECISION_LOG.md D005 and the last row of 06_AGENT_LOG.md, both 2026-10-13; the E002 experiment record is dated the same day).